Engineering Physics · Spacecraft Instrumentation

Killian Embler

Robotics researcher and engineering physics student at Embry-Riddle Aeronautical University. I design and build physical systems - exoskeletons, quadrupeds, robotic arms, and flight computers - with a focus on mechatronics, systems design, and spacecraft applications.

Portrait of Killian Embler
University
ERAU · Daytona Beach
Expected Graduation
Spring 2028
Cumulative GPA
4.00 / 4.00
Seeking
Summer 2027 internships
01

About

I'm a junior at Embry-Riddle Aeronautical University, majoring in Engineering Physics with a concentration in Spacecraft Instrumentation and minors in Applied Mathematics, Electrical and Computer Engineering, Computer Science, and Chinese Studies. As I have since childhood, I spend most of my time building or tinkering with things - exoskeletons, quadrupeds, robotic arms, and flight computers. I work across two research labs on campus and co-founded an aerospace startup, Embler Control Systems, where I serve as CTO and lead development of our flight computer and rocketry platforms. I'm drawn to problems at the intersection of multiple disciplines: combined mechanical, electrical, and software systems, where getting one part wrong means the whole thing doesn't work.

My academic journey has been driven by a genuine interest in all types of engineering, from the mechanics of a robotic joint under load to the signal integrity of a PCB in flight. That interest led me to Embry-Riddle and the aerospace industry, and I always try to make sure that what I learn in class shows up in my personal projects and in the lab.

I grew up in South Florida, close enough to the Space Coast that rocket launches were a normal thing to watch, from the roof of my house, where I would climb up at night to stargaze a little closer to space itself. That proximity made physics, space, and engineering feel tangible rather than abstract, and it has stayed with me ever since. Outside of engineering, I sail, dive, hike, and climb, always looking for more of what the world has to offer.

02

Education

Embry-Riddle Aeronautical University

Bachelor of Science, Engineering Physics

Location
Daytona Beach, Florida
Dates
Fall 2024 - Present · Expected graduation Spring 2028
Concentration
Spacecraft Instrumentation
Minors
Applied Mathematics · Computer & Electrical Engineering · Computer Science · Chinese Studies
Cumulative GPA
4.00/ 4.00
03

Experience

Employed Undergraduate Researcher & Project Lead

Mechanical Engineering Department · ERAU, Daytona Beach, FL · Part-time

  • Developing robot-human interactive control interfaces, with focus on assistive exoskeleton systems.
  • Project Lead for both the hip isolated and full lower limb exoskeletons; lead presenter at IROS 2026, submit budget requests, and maintain weekly documentation.

Undergraduate Researcher

ERAU, Daytona Beach, FL

  • Developing externally funded research projects with focus on the OpenMutt quadruped and OpenArm robotic arm.
  • Design, manufacture, and collect test data on robotic platforms; present to and communicate with project supporters to secure funding; develop systems under backer design constraints and time requirements.

Physics III TA / Recitation Tutor

ERAU, Daytona Beach, FL · Part-time

  • Worked alongside the Physics III professor to manage recitation periods and assist in student enrichment.

Marine CAD & Manufacturing Consultant

West Palm Beach, FL

  • Designing and manufacturing wood, acrylic, and 3D printed mechanical components for yachts.
  • Considered component life-cycle feedback to design parts for longevity in high-wear environments with heavy salt and sun exposure.
  • Experimentally tested and selected varnishes and coatings for wood, leather, and PLA in salty, high-UV marine environments.
  • Design under tight operational requirements. For example, LED backlit layered acrylic control panel labels that must be legible in complete darkness without taking up space on a crowded helm or affecting the captain's night vision.
04

Projects

Exoskeleton · Robotics Intelligent Learning Lab

LECTER - Full Lower Limb Exoskeleton

Project Lead

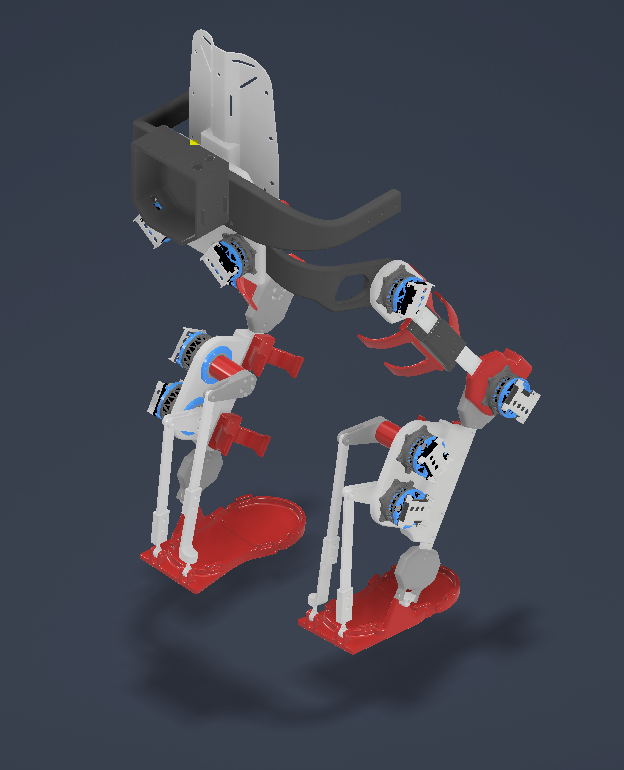
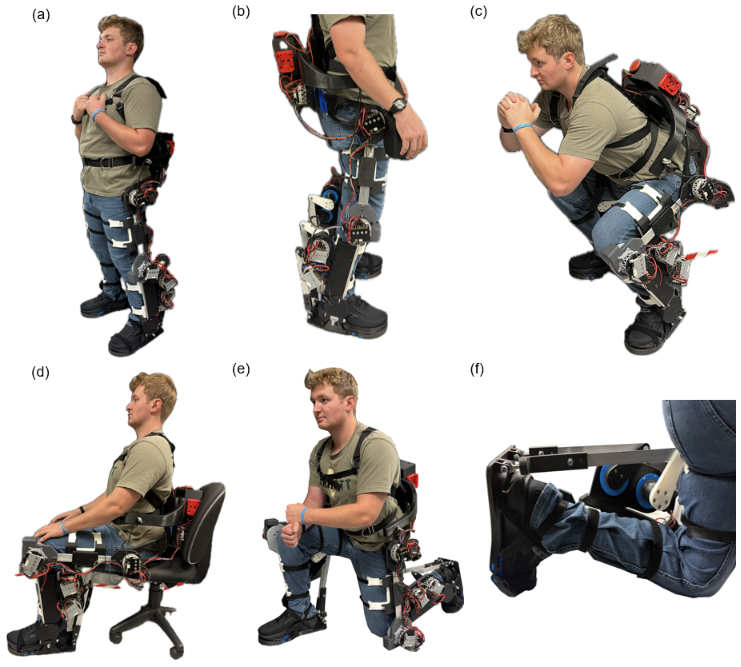
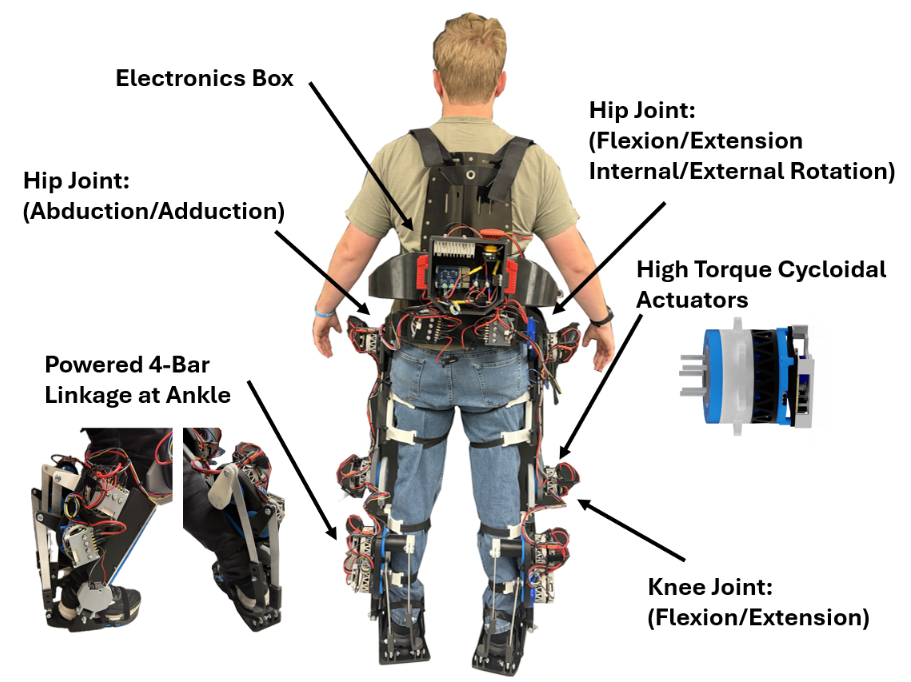
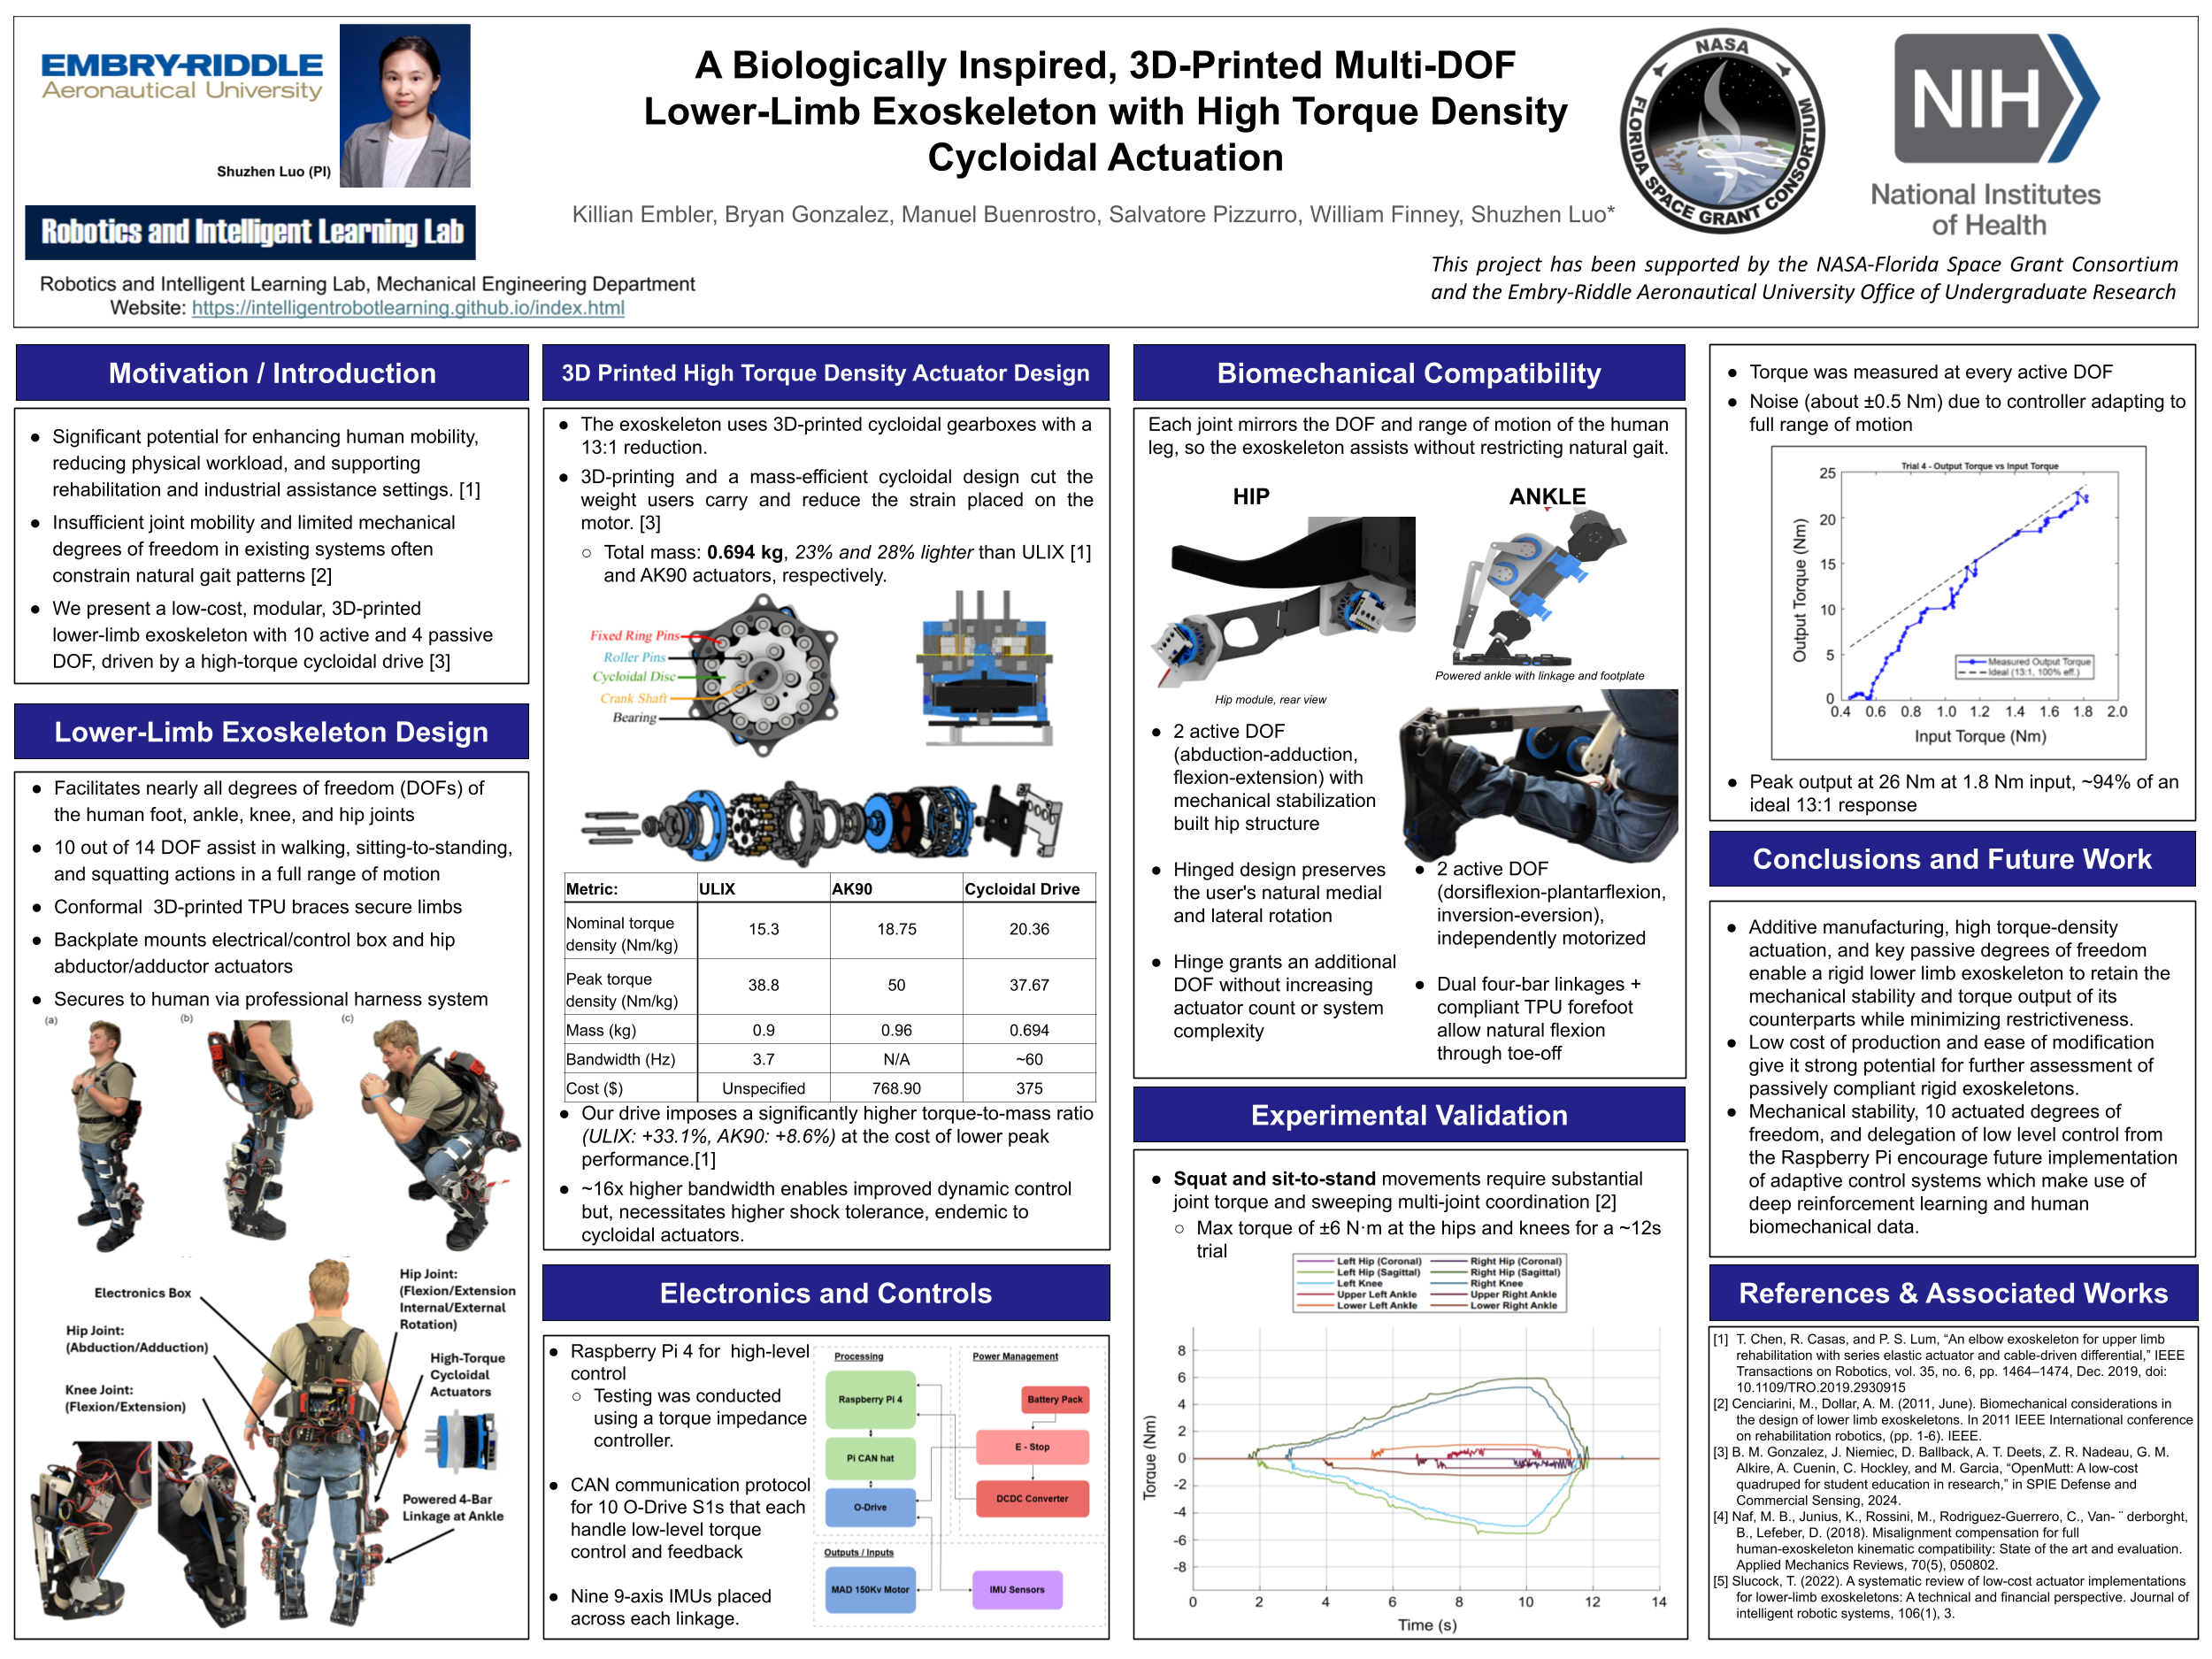
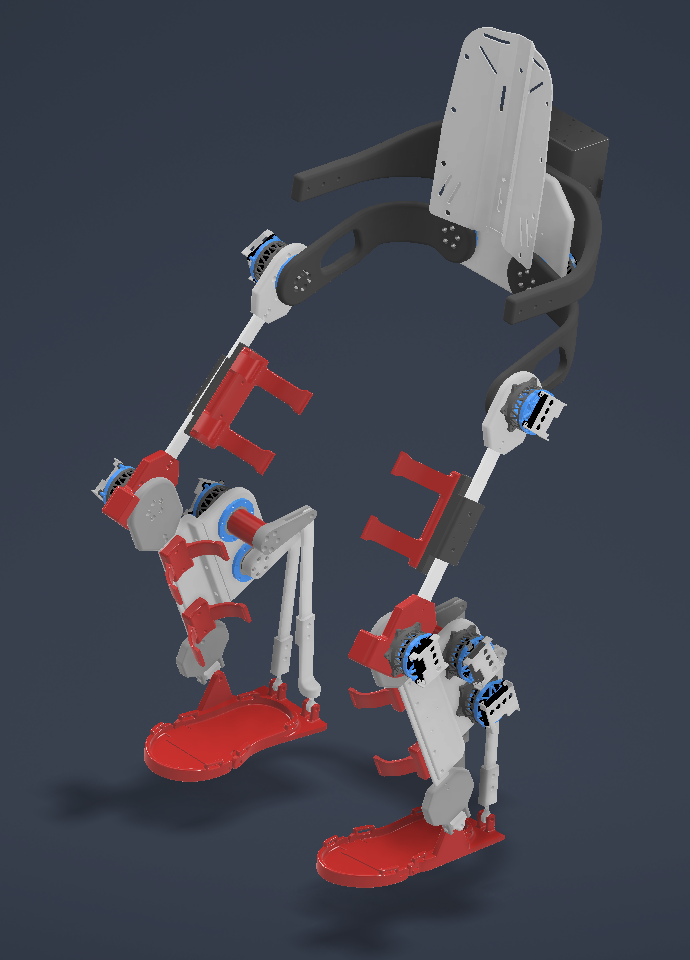
14-DOF (10 active, 4 passive) lower limb exoskeleton designed to assist able-bodied workers in physically intensive jobs without restricting them, and used primarily as a research test platform. One of the primary projects of the Robotics Intelligent Learning Lab, contributing to the lab receiving a $523,000 NIH grant.

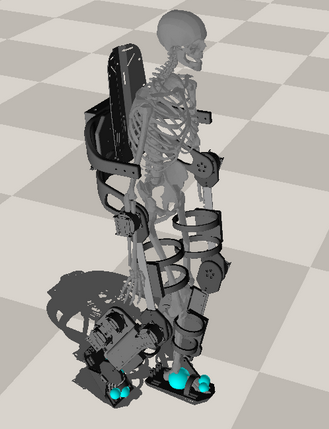
  • Created the URDF model, designed mechanical components including dual-linkage ankles for multi-axis actuation, and redesigned the wiring and power system for battery operation with a custom PCB and dual E-stop. Tuned an impedance controller in ROS2 to assist users in squatting and sit-to-stand motions.
  • First author of an extended abstract accepted to IROS 2026 (When Muscles Think workshop); lead presenter of the work at the conference.
  • 14 DOF
  • URDF
  • ROS2
  • Impedance Control
  • Custom PCB
  • Dual E-Stop
More detailHide detail

Overview

LECTER is a full lower limb exoskeleton for able-bodied people who work physically intensive jobs and need assistance to prevent injury, while wearing something unrestrictive enough not to inhibit them. It does this with 10 active degrees of freedom and 4 passive. In practice it is not a commercial project and works primarily as a research test platform.

Team

I work alongside Bryan Gonzalez, Manuel Buenrostro, Max Pizzurro, Cole Finney, and Dr. Shuzhen Luo, our overseeing faculty advisor. Bryan initially led the project. I took over as lead at the end of the Fall 2025 semester, after he finished his master's degree.

My role

  • Mechanical design, such as the universal ankles with dual four-bar linkages and Heim joints.
  • Redesigning the electrical system to include a simple PCB and dual E-stop system for compactness, safety, and battery operation.
  • Tuning the impedance controller for squat assistance.
  • Running tests with Max or Cole wearing the exoskeleton.
  • Leading the presentation of our work at the IROS 2026 workshop.

Hardest problem

The hardest technical problem has always been balancing an exoskeleton that is as unrestrictive as possible against structural integrity and controllability. There have been many times where we added mobility, only to have the new moving components break under the full stress of an assisted squat or sit-to-stand.

Results so far

In low-torque impedance controller squat tests, peak output reached 6-8 Nm at each hip and knee joint. That was enough to offset the weight of the exoskeleton during a squat, and it showed the structure holding up mechanically while applying a smooth curve of assistance through the whole motion. Each actuator can output up to 26 Nm if needed. Further figures and details are in the extended abstract.

Architecture and what's next

A high-level controller (of any kind) runs on a Raspberry Pi 4 and sends CAN signals that delegate low-level control to an ODrive S1 on each actuator. Future work focuses on more complex control methods, such as deep reinforcement learning, to match natural human gait and movement, conserve energy, and apply torque to the joints as effectively as possible. Changes in progress also aim to increase actuator torque, reduce weight, increase durability, and maximize user safety and comfort.

Flight Computer · Embler Control Systems

SAMSARA - Flight Computer

Designer & Firmware Lead

Self-developed rocketry flight computer for Embler Control Systems.

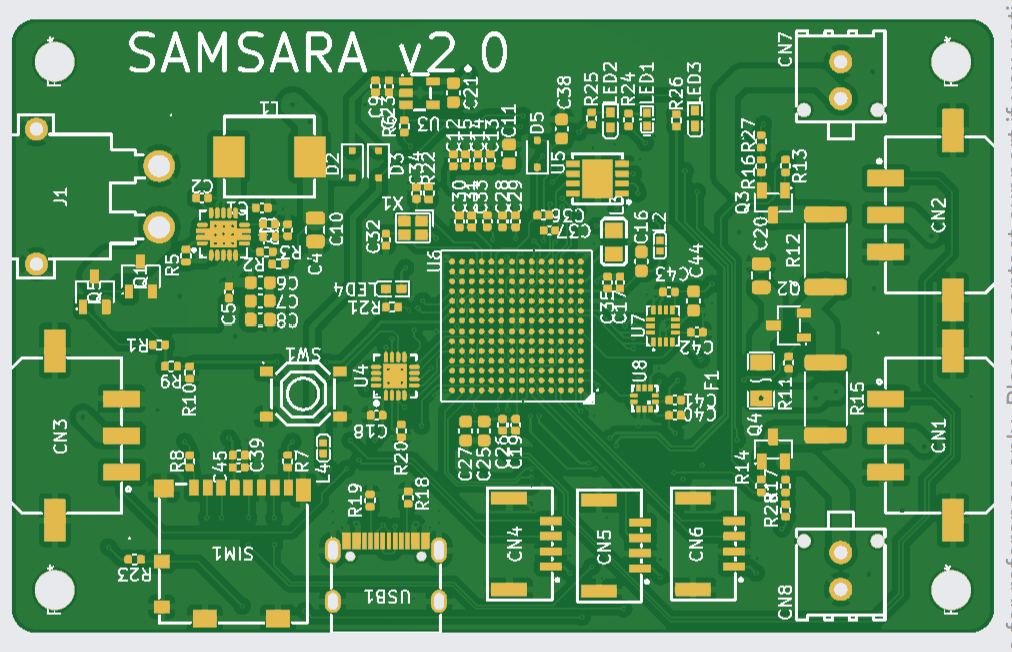
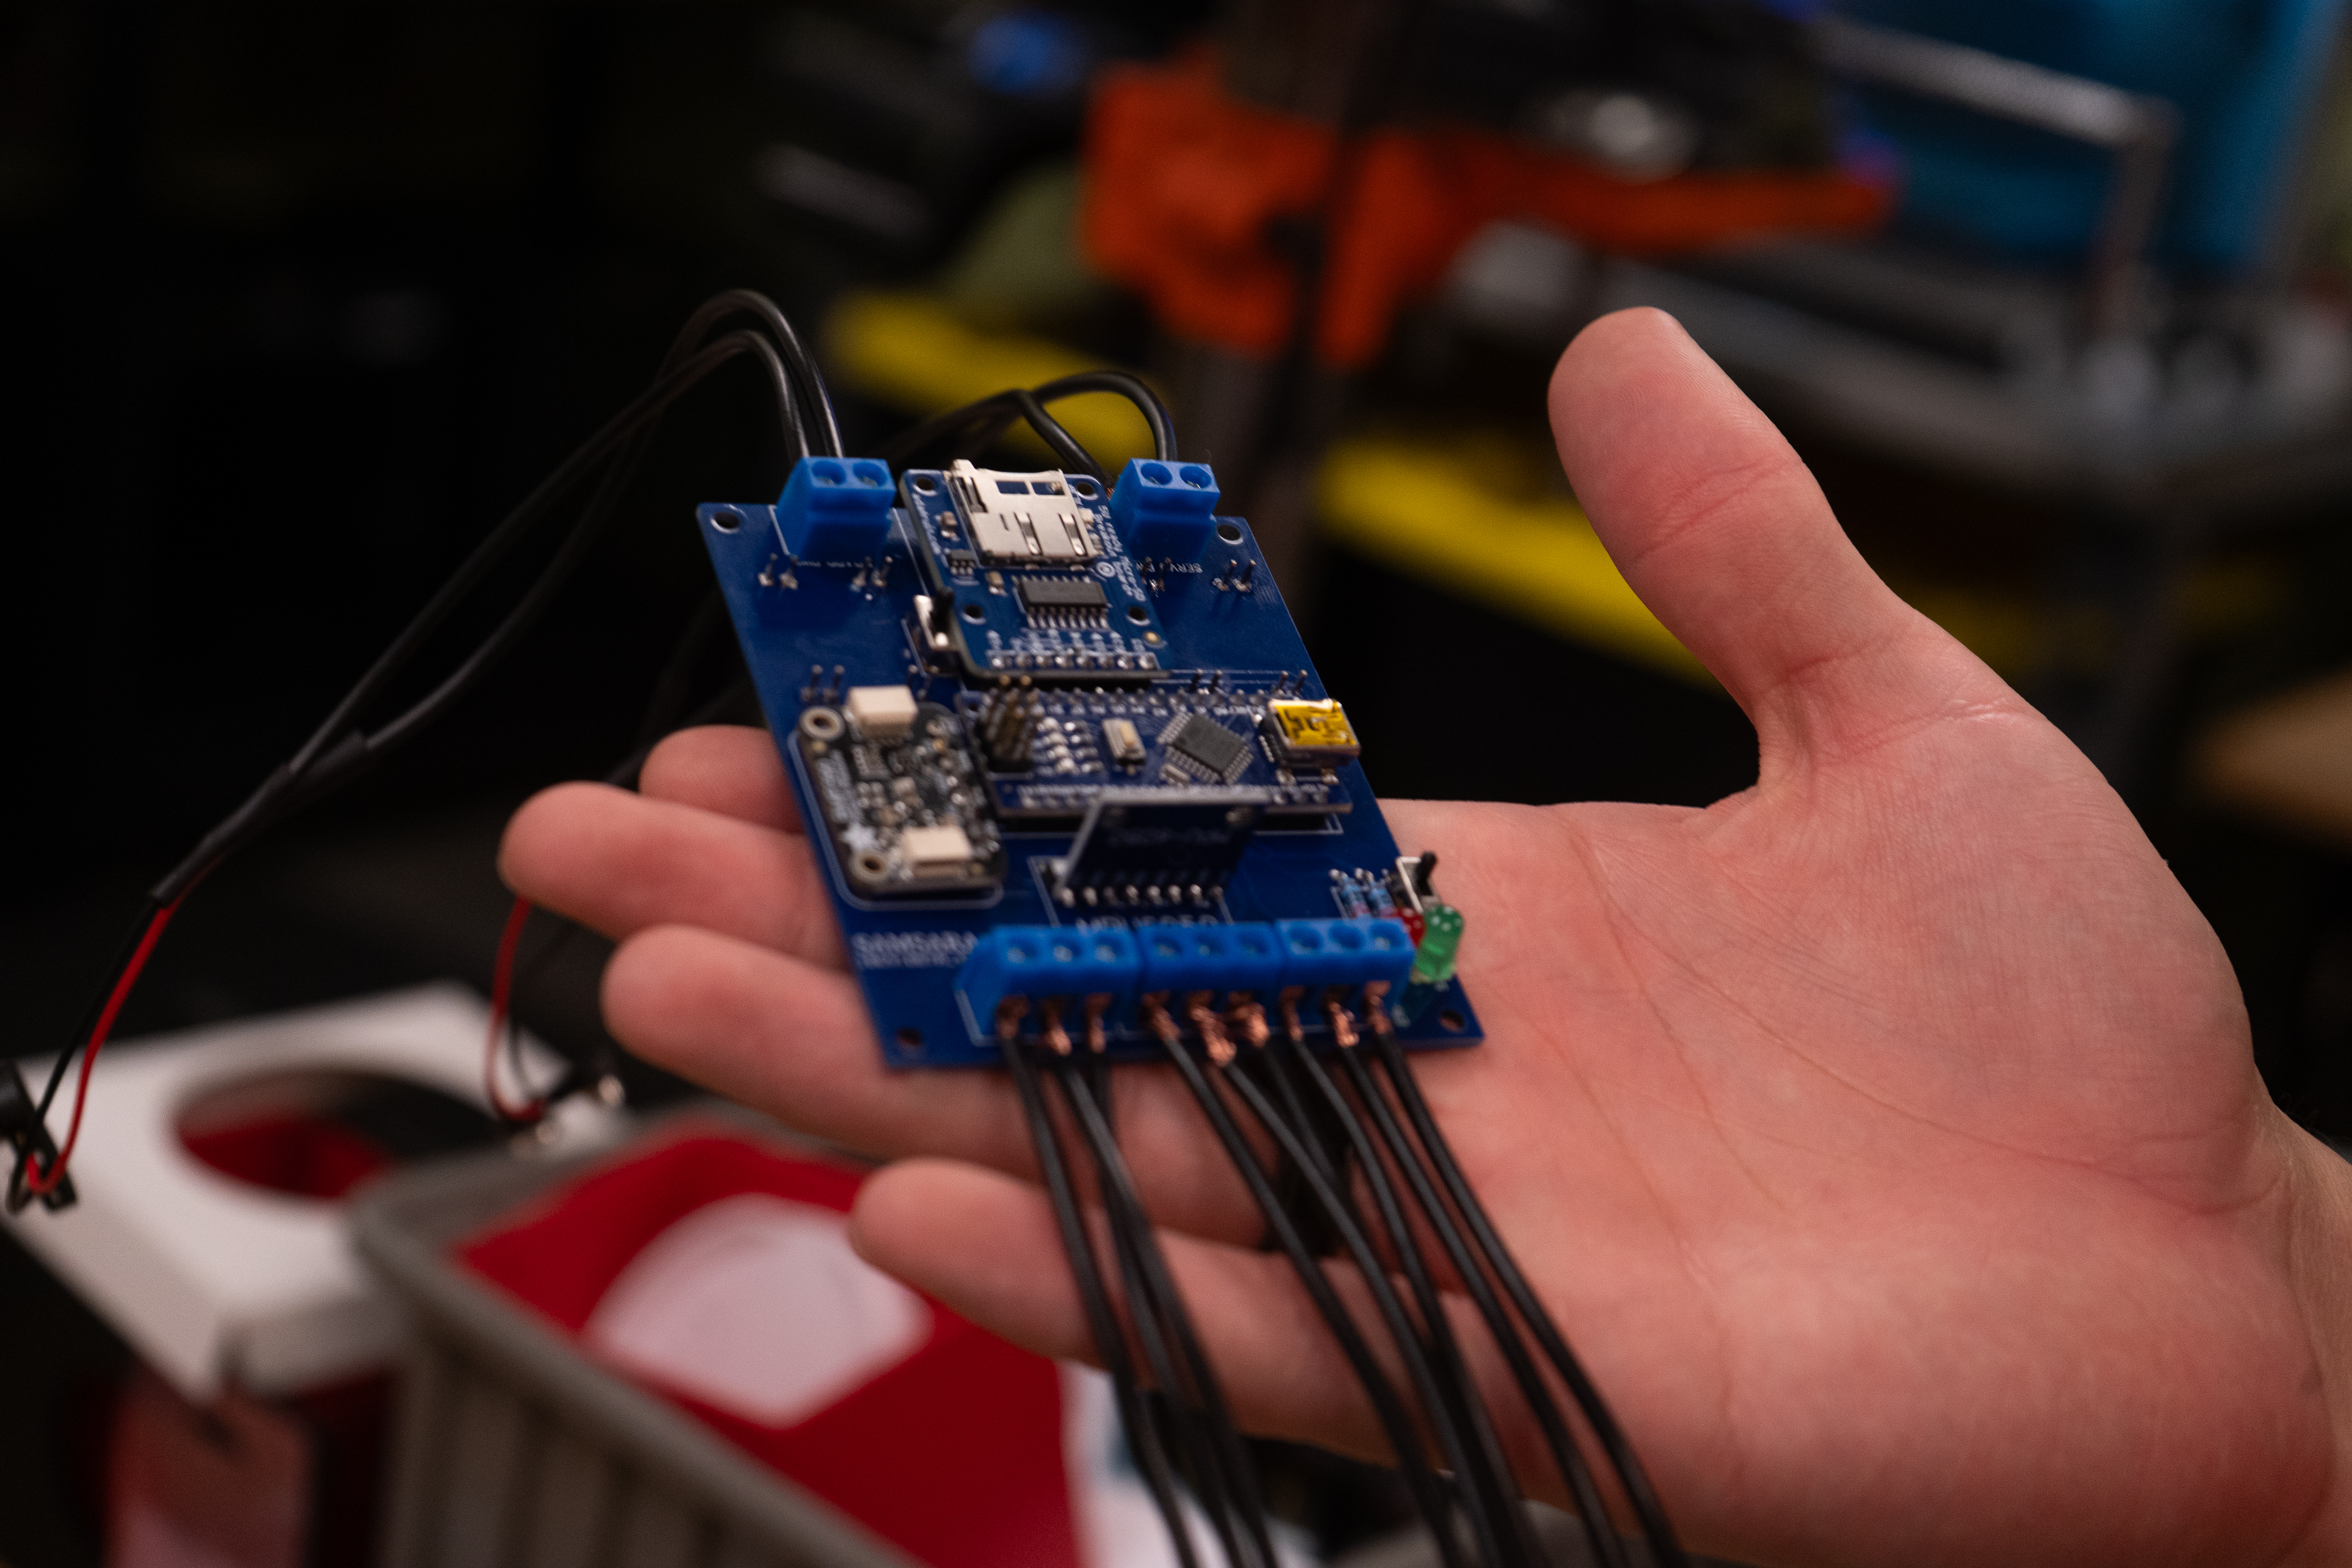
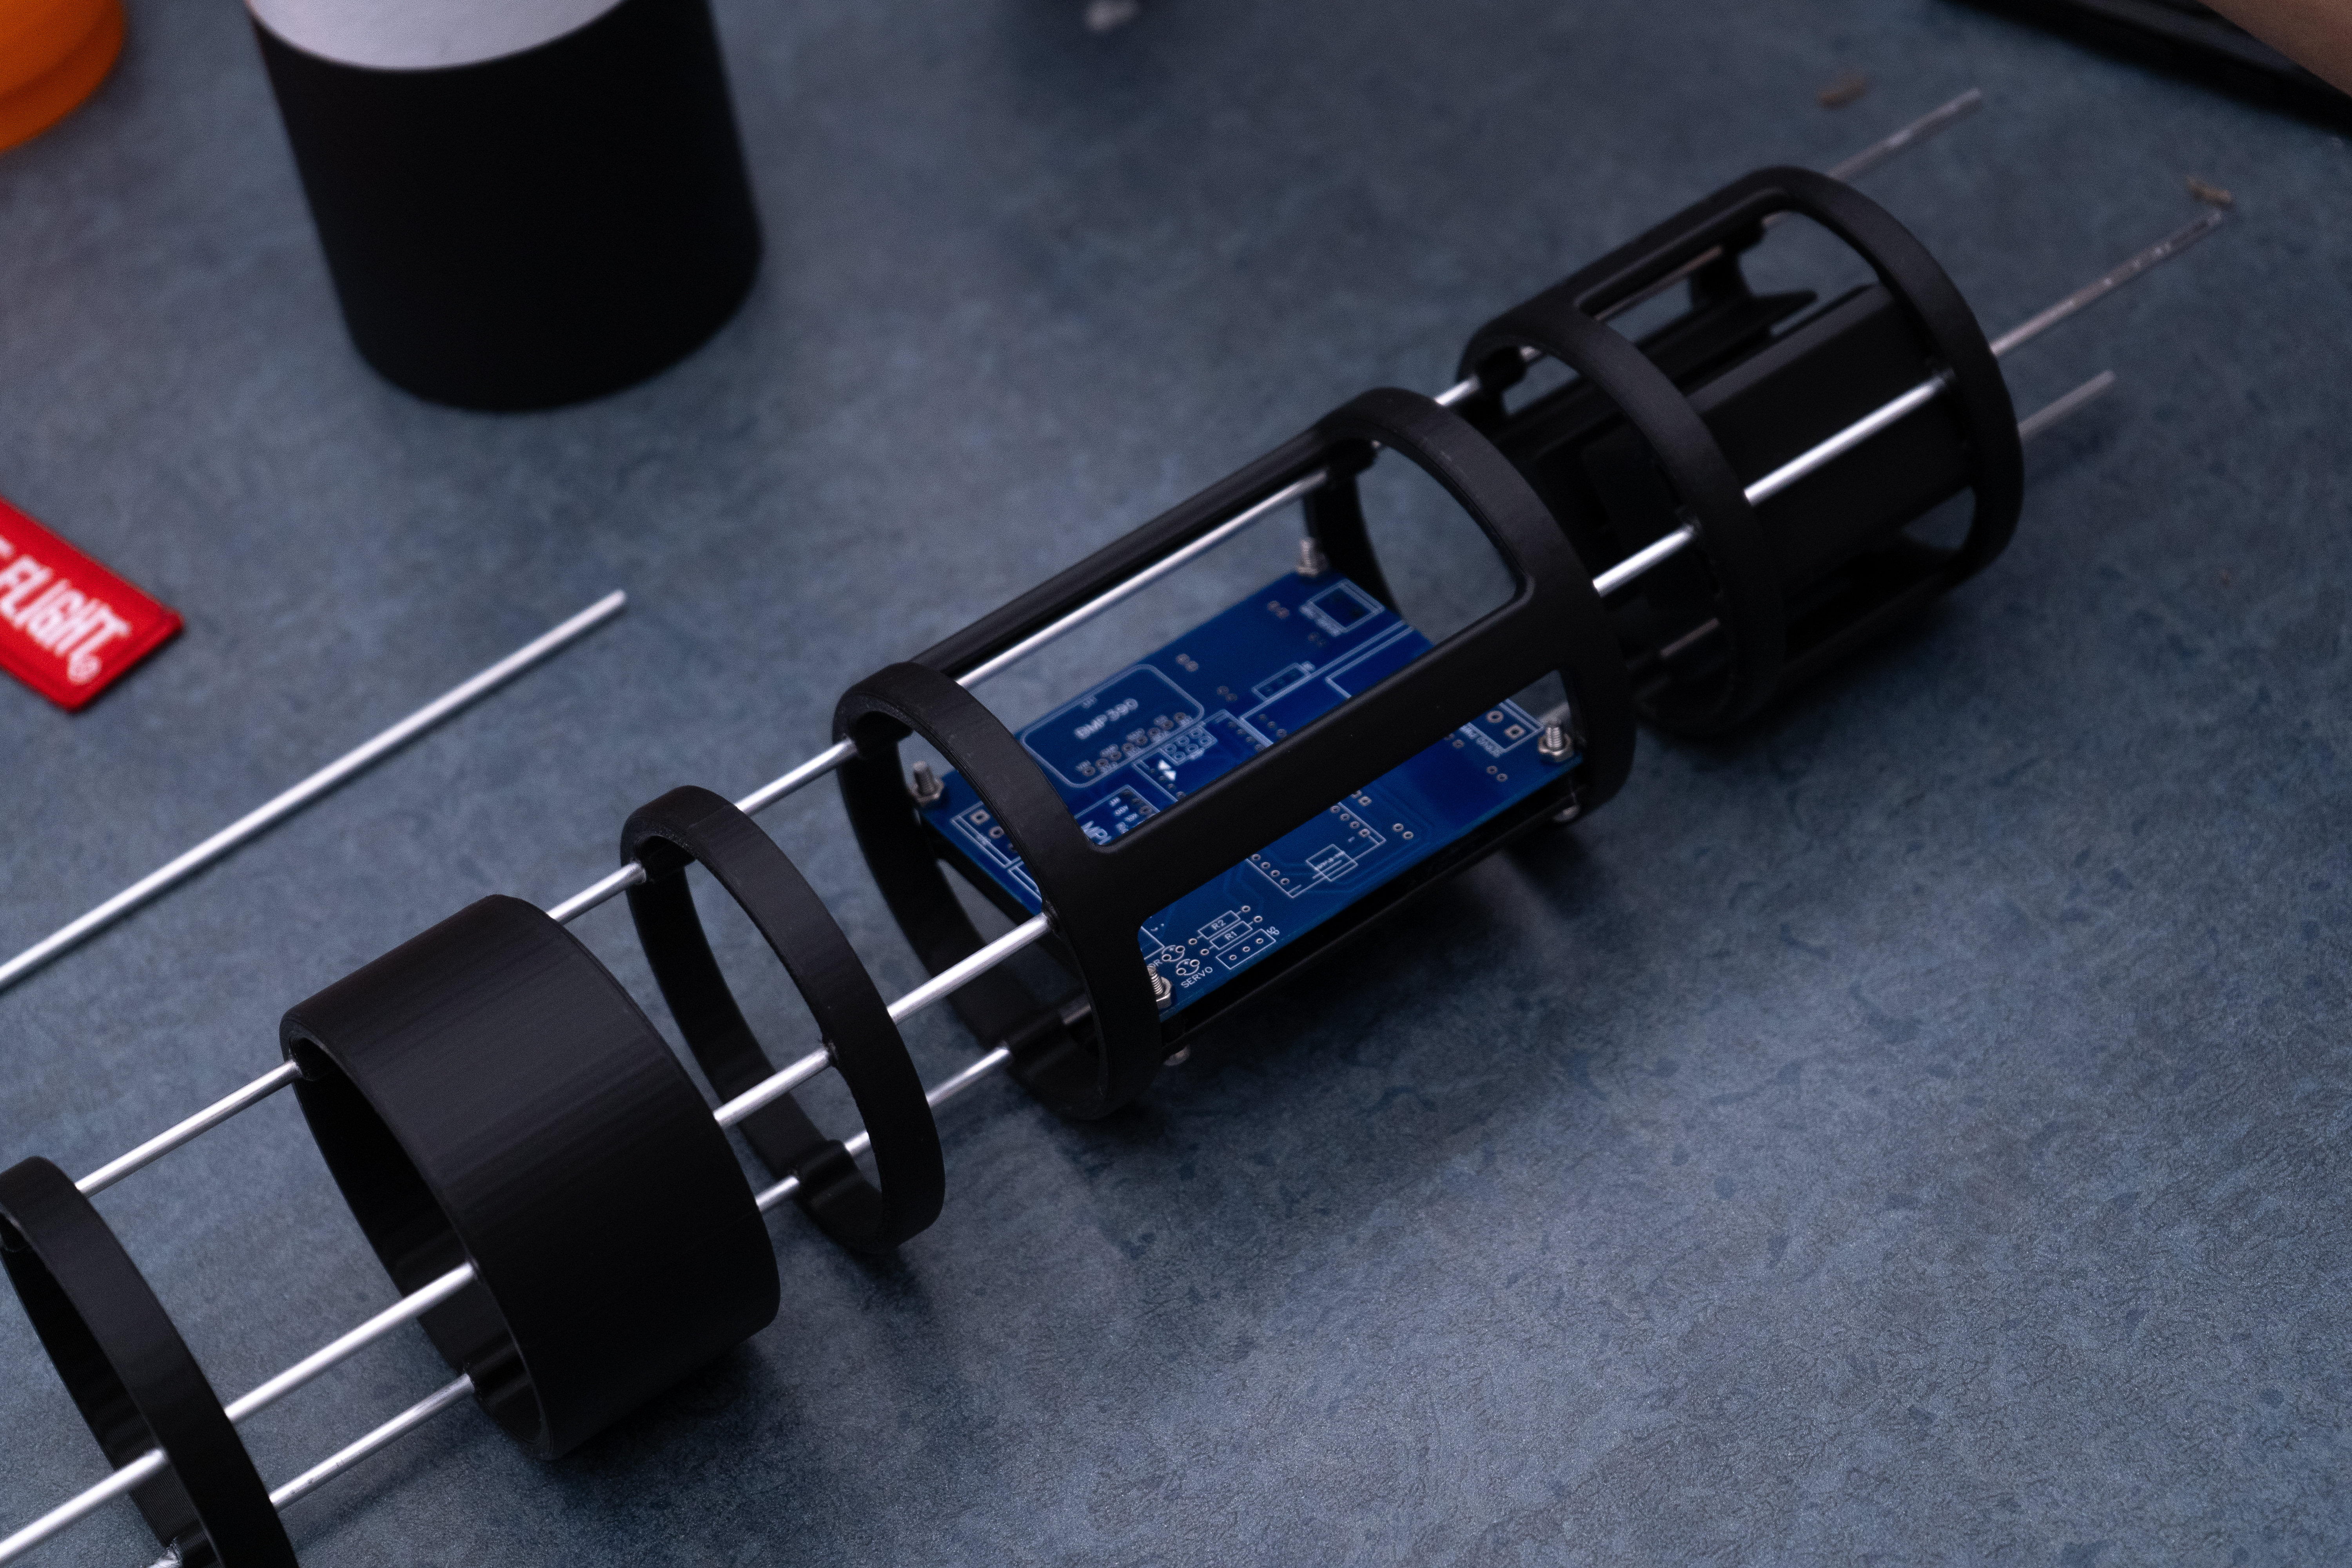
  • 4-layer PCB built around a 32-bit ARM Cortex-M7 processor with an onboard IMU and altimeter, a custom integrated DCDC buck converter, and multiple continuity-sensing pyro lines, servo ports, and SPI sensor ports.
  • Leading development of firmware for the system.
  • PCB Design
  • ARM Cortex-M7
  • Firmware
  • IMU & Altimeter
  • DCDC Buck
  • KiCad
More detailHide detail

Why it exists

SAMSARA is the flagship product of Embler Control Systems. Many of our student members were in STEM or rocketry clubs in high school, then realized after starting an engineering degree that they were still unprepared for a large part of what real engineering involves. I had the same experience at my high school on Project Meridian, which set out to build a TVC model rocket. Even though we had spent much of our lives doing model rocketry, the PCB design, software, and controls work was nearly insurmountable for the team.

SAMSARA is meant to be a bridge into avionics and intelligent launch vehicles, and to let people get meaningful data from every launch so they can evaluate and iterate on their rocket designs. It also has a place in college rocketry labs, where good avionics and data measurement tools are always in high demand.

Team

The team is 12 engineering and physics students from 3 universities in Florida, 3 of whom work mainly on the business side. As CTO, I lead the other 9, split into PCB design, software, and implementation teams. Until summer 2026 the team had not fully expanded, and the people who had joined were still training with me, so I personally handled a large portion of SAMSARA's development.

Version history

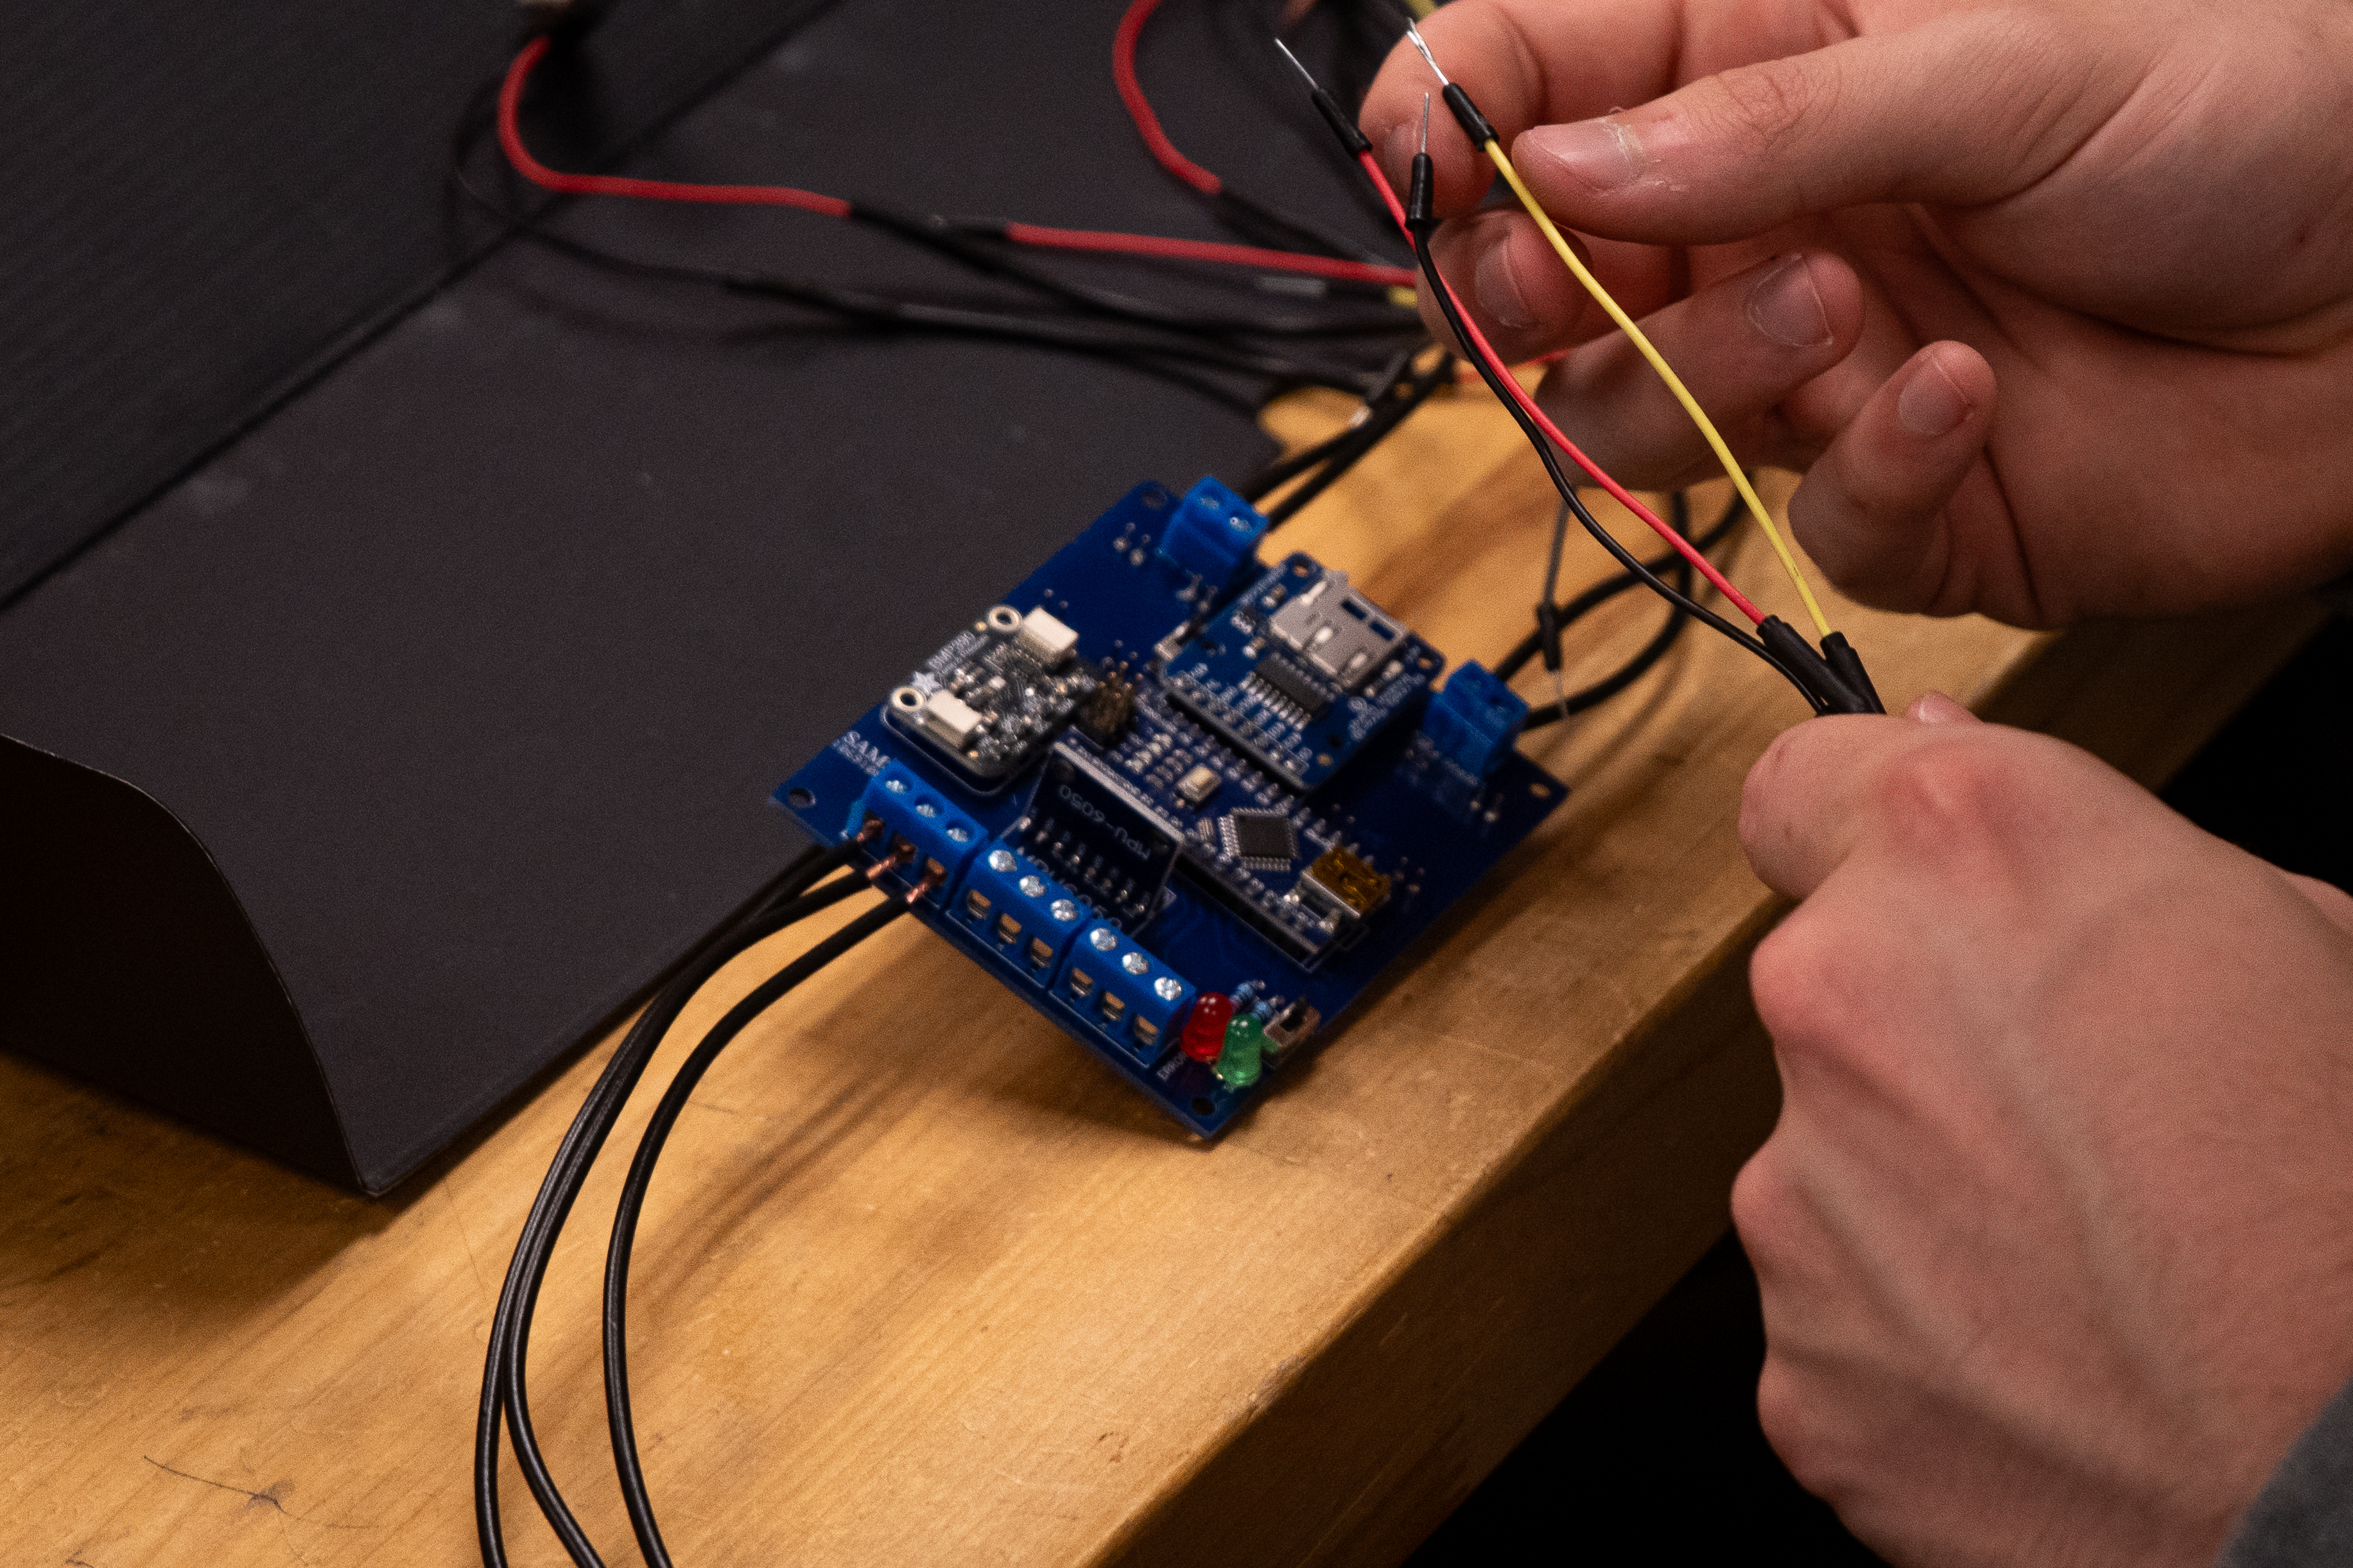
  • V0 (fall 2025): The first PCB I ever designed start to finish on my own, made before the project was named SAMSARA. A bare-bones 2-layer board with a few breakout boards for sensing and power. It was large and bulky, but it just barely let an Arduino Nano read IMU data and move servos.
  • V1: More refined, with altitude sensing and SD card data recording added. It flew more than 5 times on our ALTAI platform in spring 2026 and gave us data and feedback to improve the design.
  • V1.5 (never produced): A big jump in ambition. I went straight from a 2-layer breakout board to a fully integrated microcontroller design based on the Teensy 4.1 architecture, on a 4-layer PCB with a custom DCDC converter.
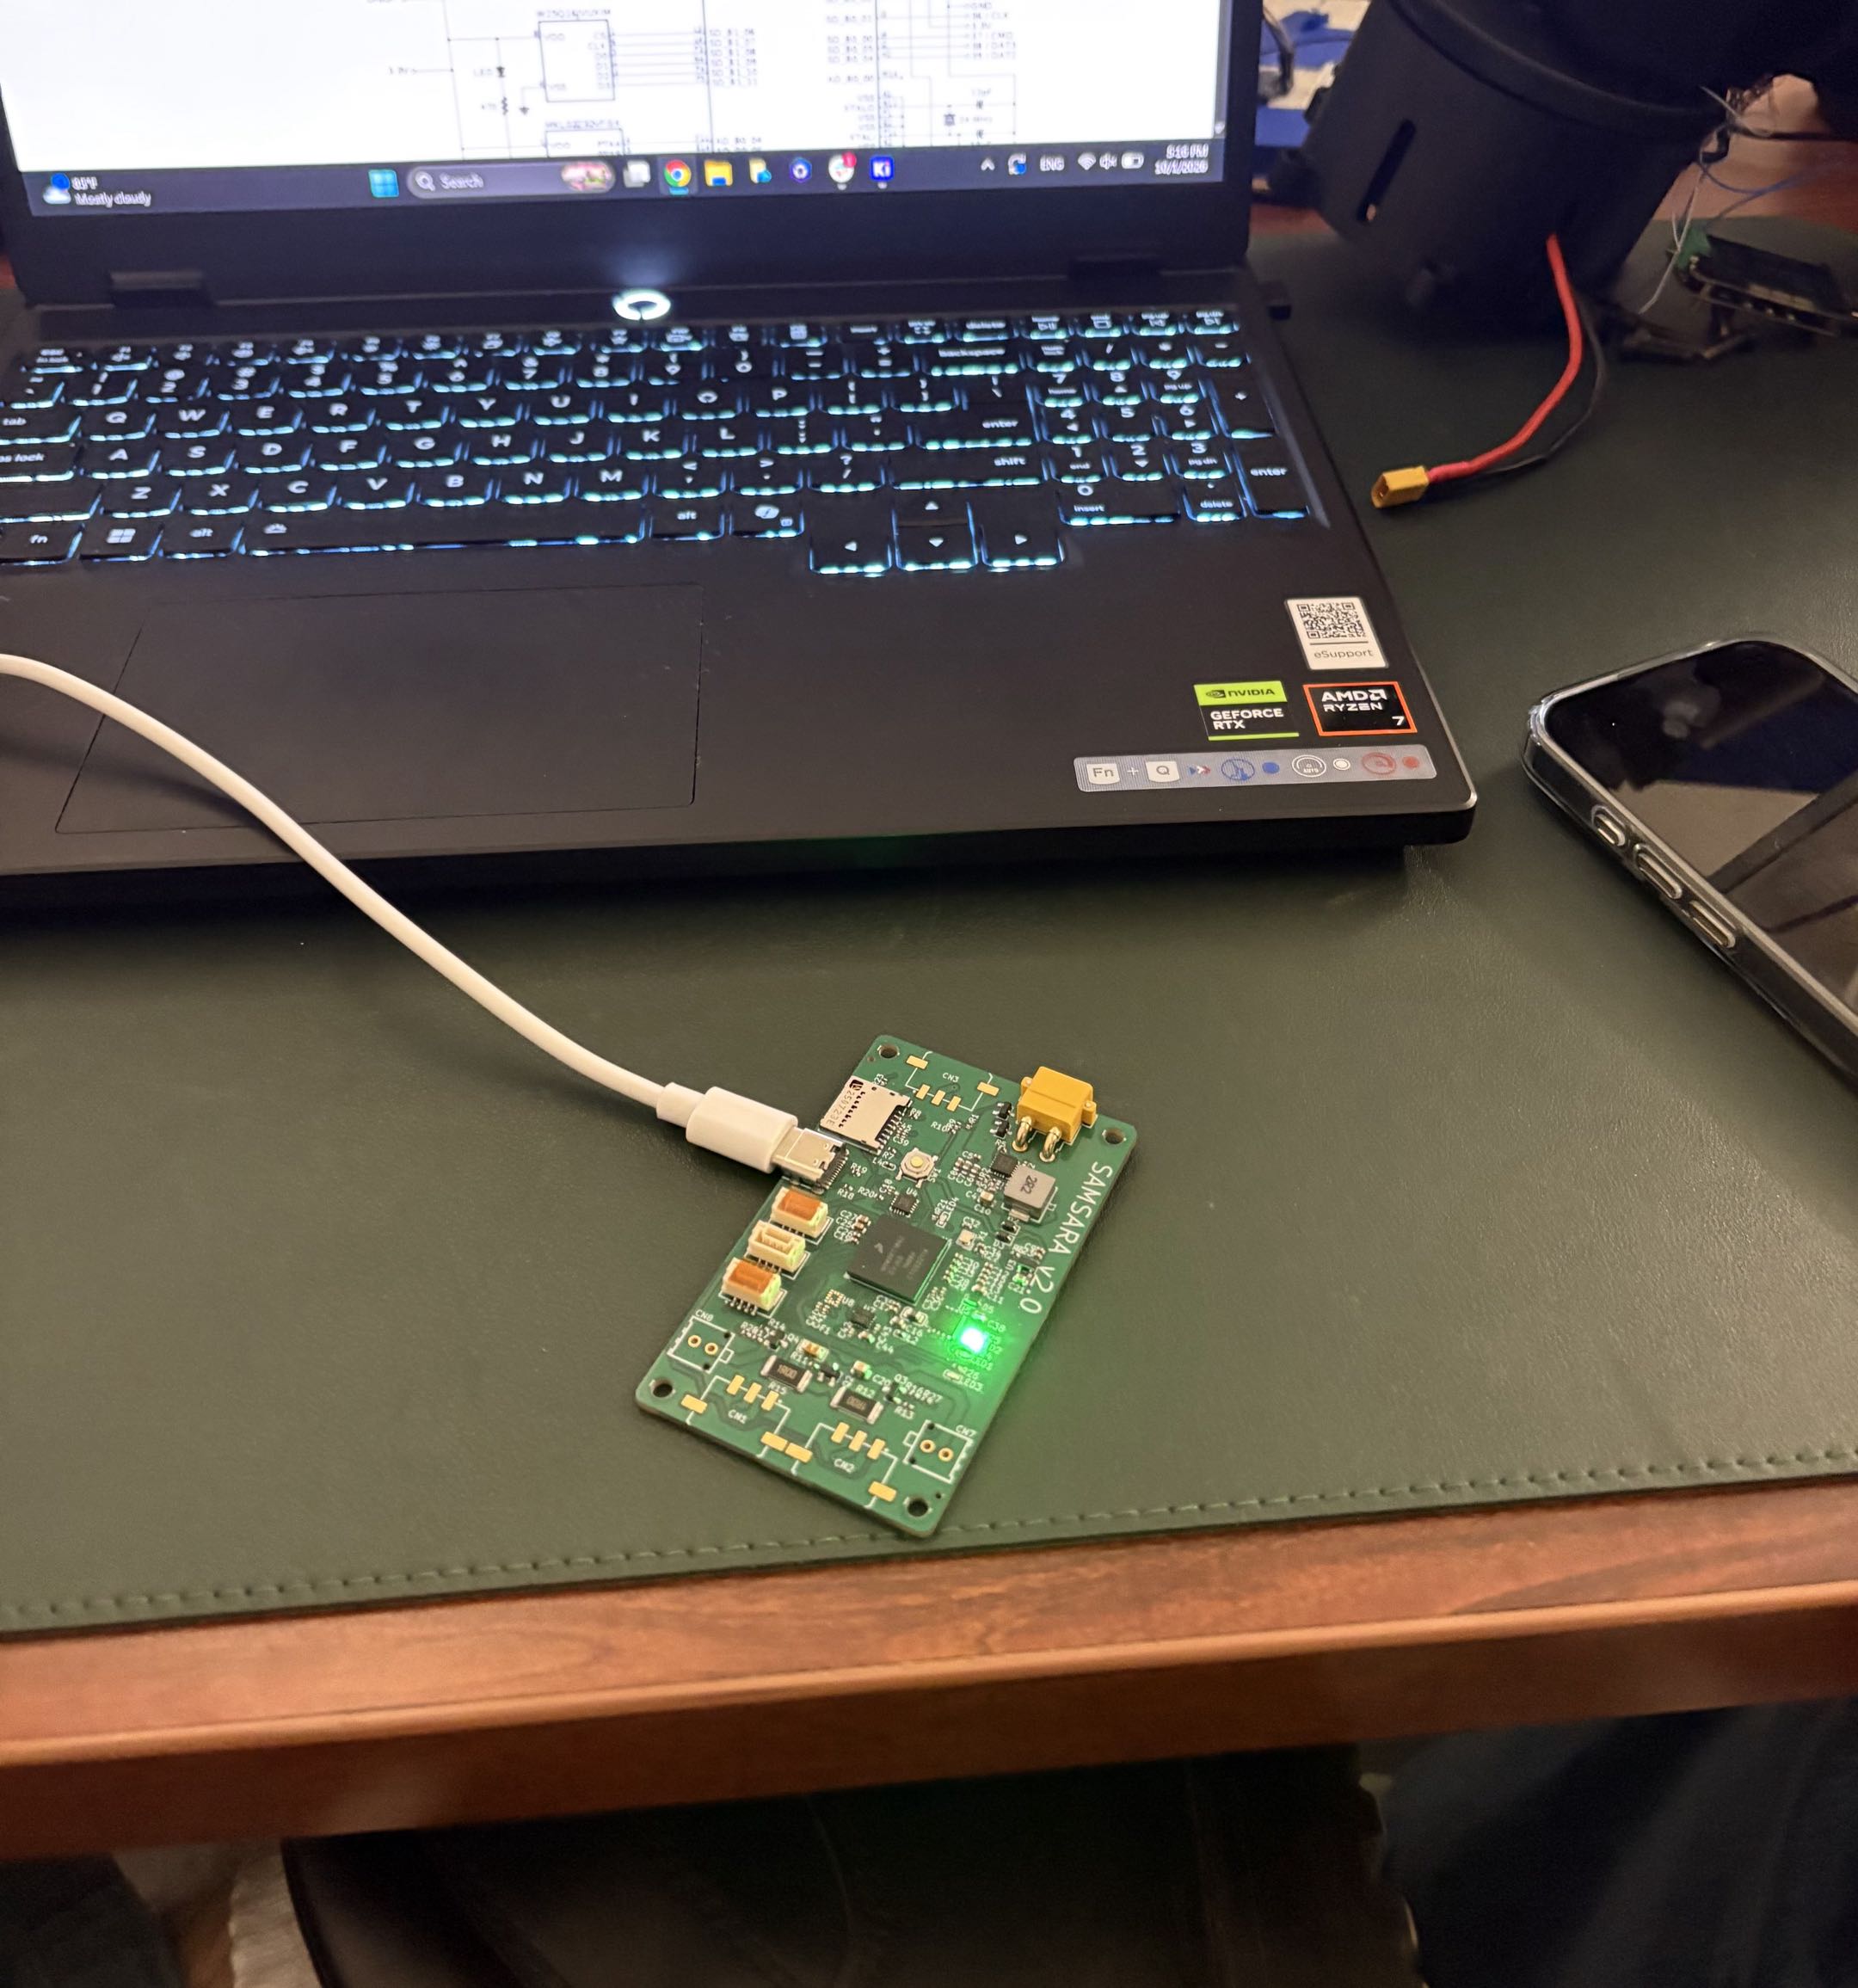
  • V2: The current version, in production and in bench testing.

V0 and V1 were designed in EasyEDA. V1.5 and V2 were designed in KiCad.

Hardest problem

The hardest technical problem for me has definitely been the PCB design. With V1.5, I bit off more than I could chew. By the time I reached a finalized design I had put in nearly a hundred hours, and it was still clearly unrefined, with poor EMI management. Most significantly, it used an inconsistent assortment of components that drove up assembly cost and complicated sourcing, and it depended on a critical flash memory part that entered a multi-month global shortage partway through the project.

For V2, I went back to the drawing board with the experience from that failure. I set strict design requirements for myself: FCC limitations, supplier sourcing, existing inventory, replaceability of parts, and estimated production cost, all balanced against keeping full functionality. I made high-level design diagrams first, sourced the key components, and only then moved into a KiCad schematic and the board layout, applying what I had learned about proper circuit design for microcontrollers.

V2 still takes some inspiration from the core Teensy architecture, and uses a Teensy bootloader chip to help with firmware. It takes much less than V1.5 did, since it is designed specifically for flight computing and not as a general-purpose development board.

Status

The newest version is in production and currently going through bench testing and software development. It has not yet flown, so no flight data is available.
Exoskeleton · Robotics Intelligent Learning Lab

3D Printed Hip Isolated Exoskeleton

Project Lead

4-DOF hip exoskeleton serving as a machine learning testbed for metabolic cost reduction research at the Robotics Intelligent Learning Lab.

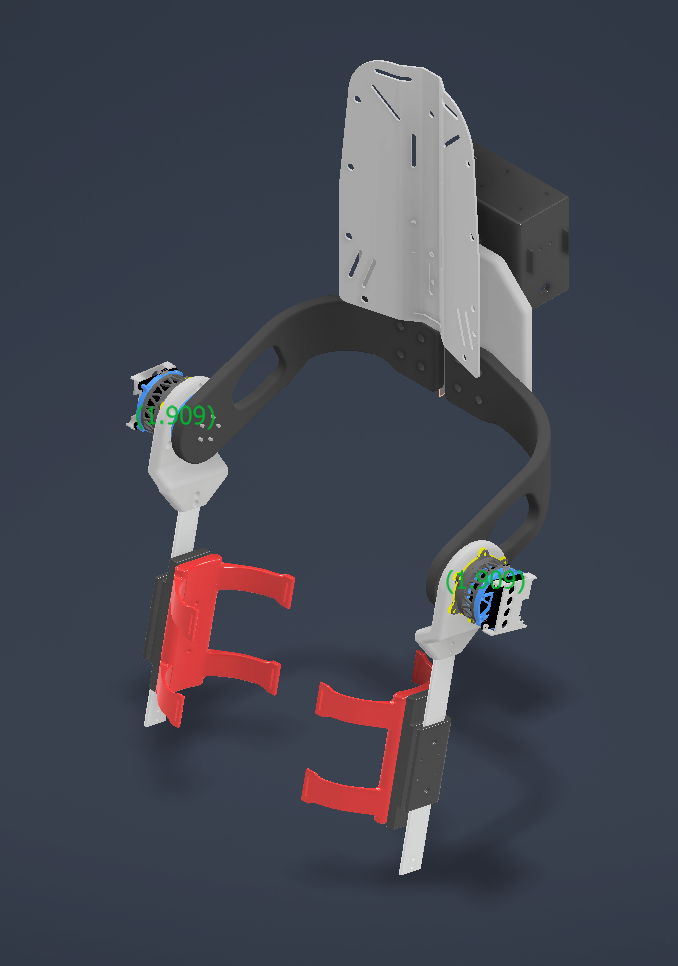
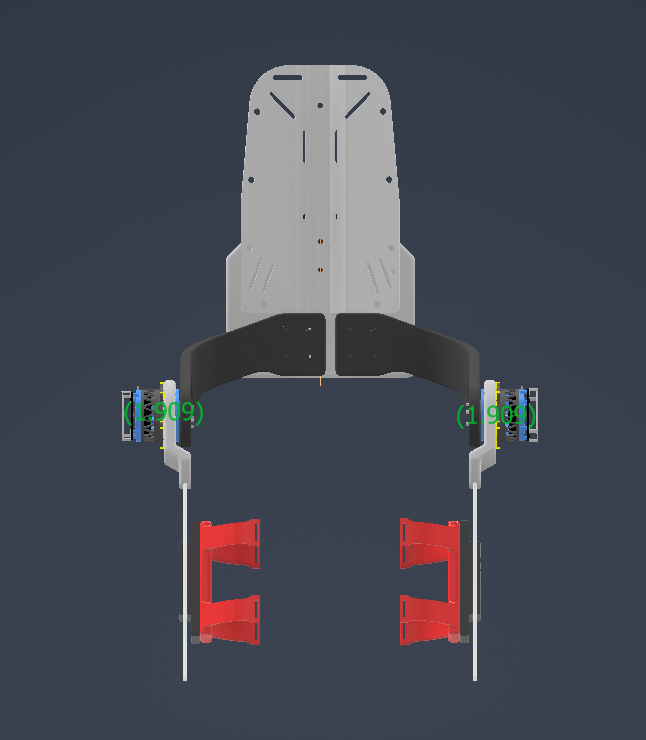
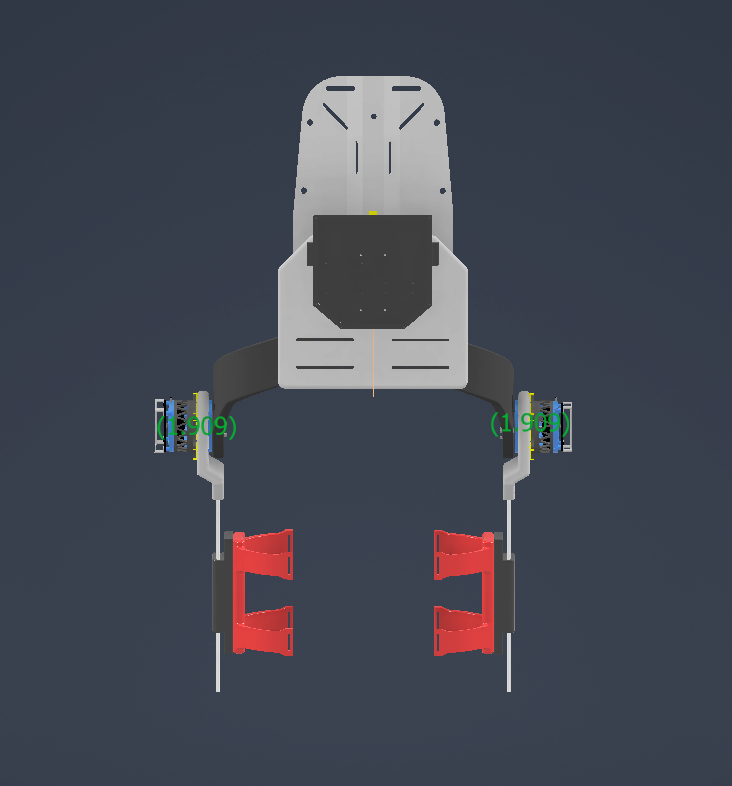
  • Redesigned the mechanical framework with FEA validation, added hip-width adjustability, produced the URDF model, and designed the entirety of the electrical architecture including a dedicated PCB.
  • 4 DOF
  • FEA
  • URDF
  • PCB Design
  • 3D Printing
More detailHide detail

Why it exists

The hip exoskeleton started as a middle ground for the Robotics Intelligent Learning Lab between in-house controls research and in-house mechanical design. Two of the lab's main projects sit on either side of that gap. LECTER focuses on mechanical design but lags behind in controls because of its added mechanical complexity. A second hip exoskeleton project, led by a PhD student, focuses on reinforcement learning and not on in-house mechanical design.

I was given the task of bridging the two: a new hip exoskeleton that uses what we learned mechanically from LECTER and begins testing with reinforcement learning.

Team

I am the primary contributor, with Dr. Shuzhen Luo as faculty advisor. Members of the LECTER team have recently helped prepare for the reinforcement learning work.

Key design decision

The biggest choice was removing the two hip degrees of freedom in the coronal plane that LECTER has. This exoskeleton focuses on gait, which does not need significant motion in the coronal plane, and removing those actuators allowed hip width adjustability, a more condensed back plate section, and an overall decrease in weight. Hip width adjustability lets the exoskeleton fit a wider range of wearers, which gives us more versatility in gait patterns. At each hip, flexion/extension is actuated and abduction/adduction is passive.

Hardware

The actuators are the same custom 3D printed cycloidal actuators used on LECTER, evaluated on the actuator testbed up to 26 Nm. The exoskeleton uses a wide variety of 3D printed parts depending on function, in PETG, PLA, polycarbonate, and resin.

FEA was used heavily on both LECTER and the hip exoskeleton. Exoskeleton materials need to be lightweight and unrestrictive while keeping a significant safety factor so a human user is never at risk. Since much of both exoskeletons is 3D printed, parts that take multi-axial torques, like the hip chassis, need in-depth analysis to make sure they can handle the full actuation load before a human ever wears the exoskeleton.

Hardest problem

This was the first project where I had expectations to meet but could work at my own discretion. That made design decisions hard, like what to keep or simplify mechanically and how it would benefit the project overall. The issue seems small, but it held back my work until I learned to take my design ideas, back them with reasoning under design constraints, and then carry them out with confidence that my decisions rested on sound logic.

Status and what's next

The exoskeleton is in the late stages of assembly and has not been fully tested. The new PCB design is complete but has not been manufactured, so it currently uses a less compact wired setup. The controller is being built from simulations of a high-fidelity human model interacting with the exoskeleton's URDF, to produce a sim-to-real controller that will run on the exoskeleton's Raspberry Pi 4.

Next is refining the hardware implementation and starting to train the reinforcement learning controller for gait testing. Metabolic cost will be assessed in human experiments. It is one of the primary metrics of the other hip exoskeleton at the lab, so it allows a direct comparison of the mechanical designs and the controllers.

Rocketry · Embler Control Systems

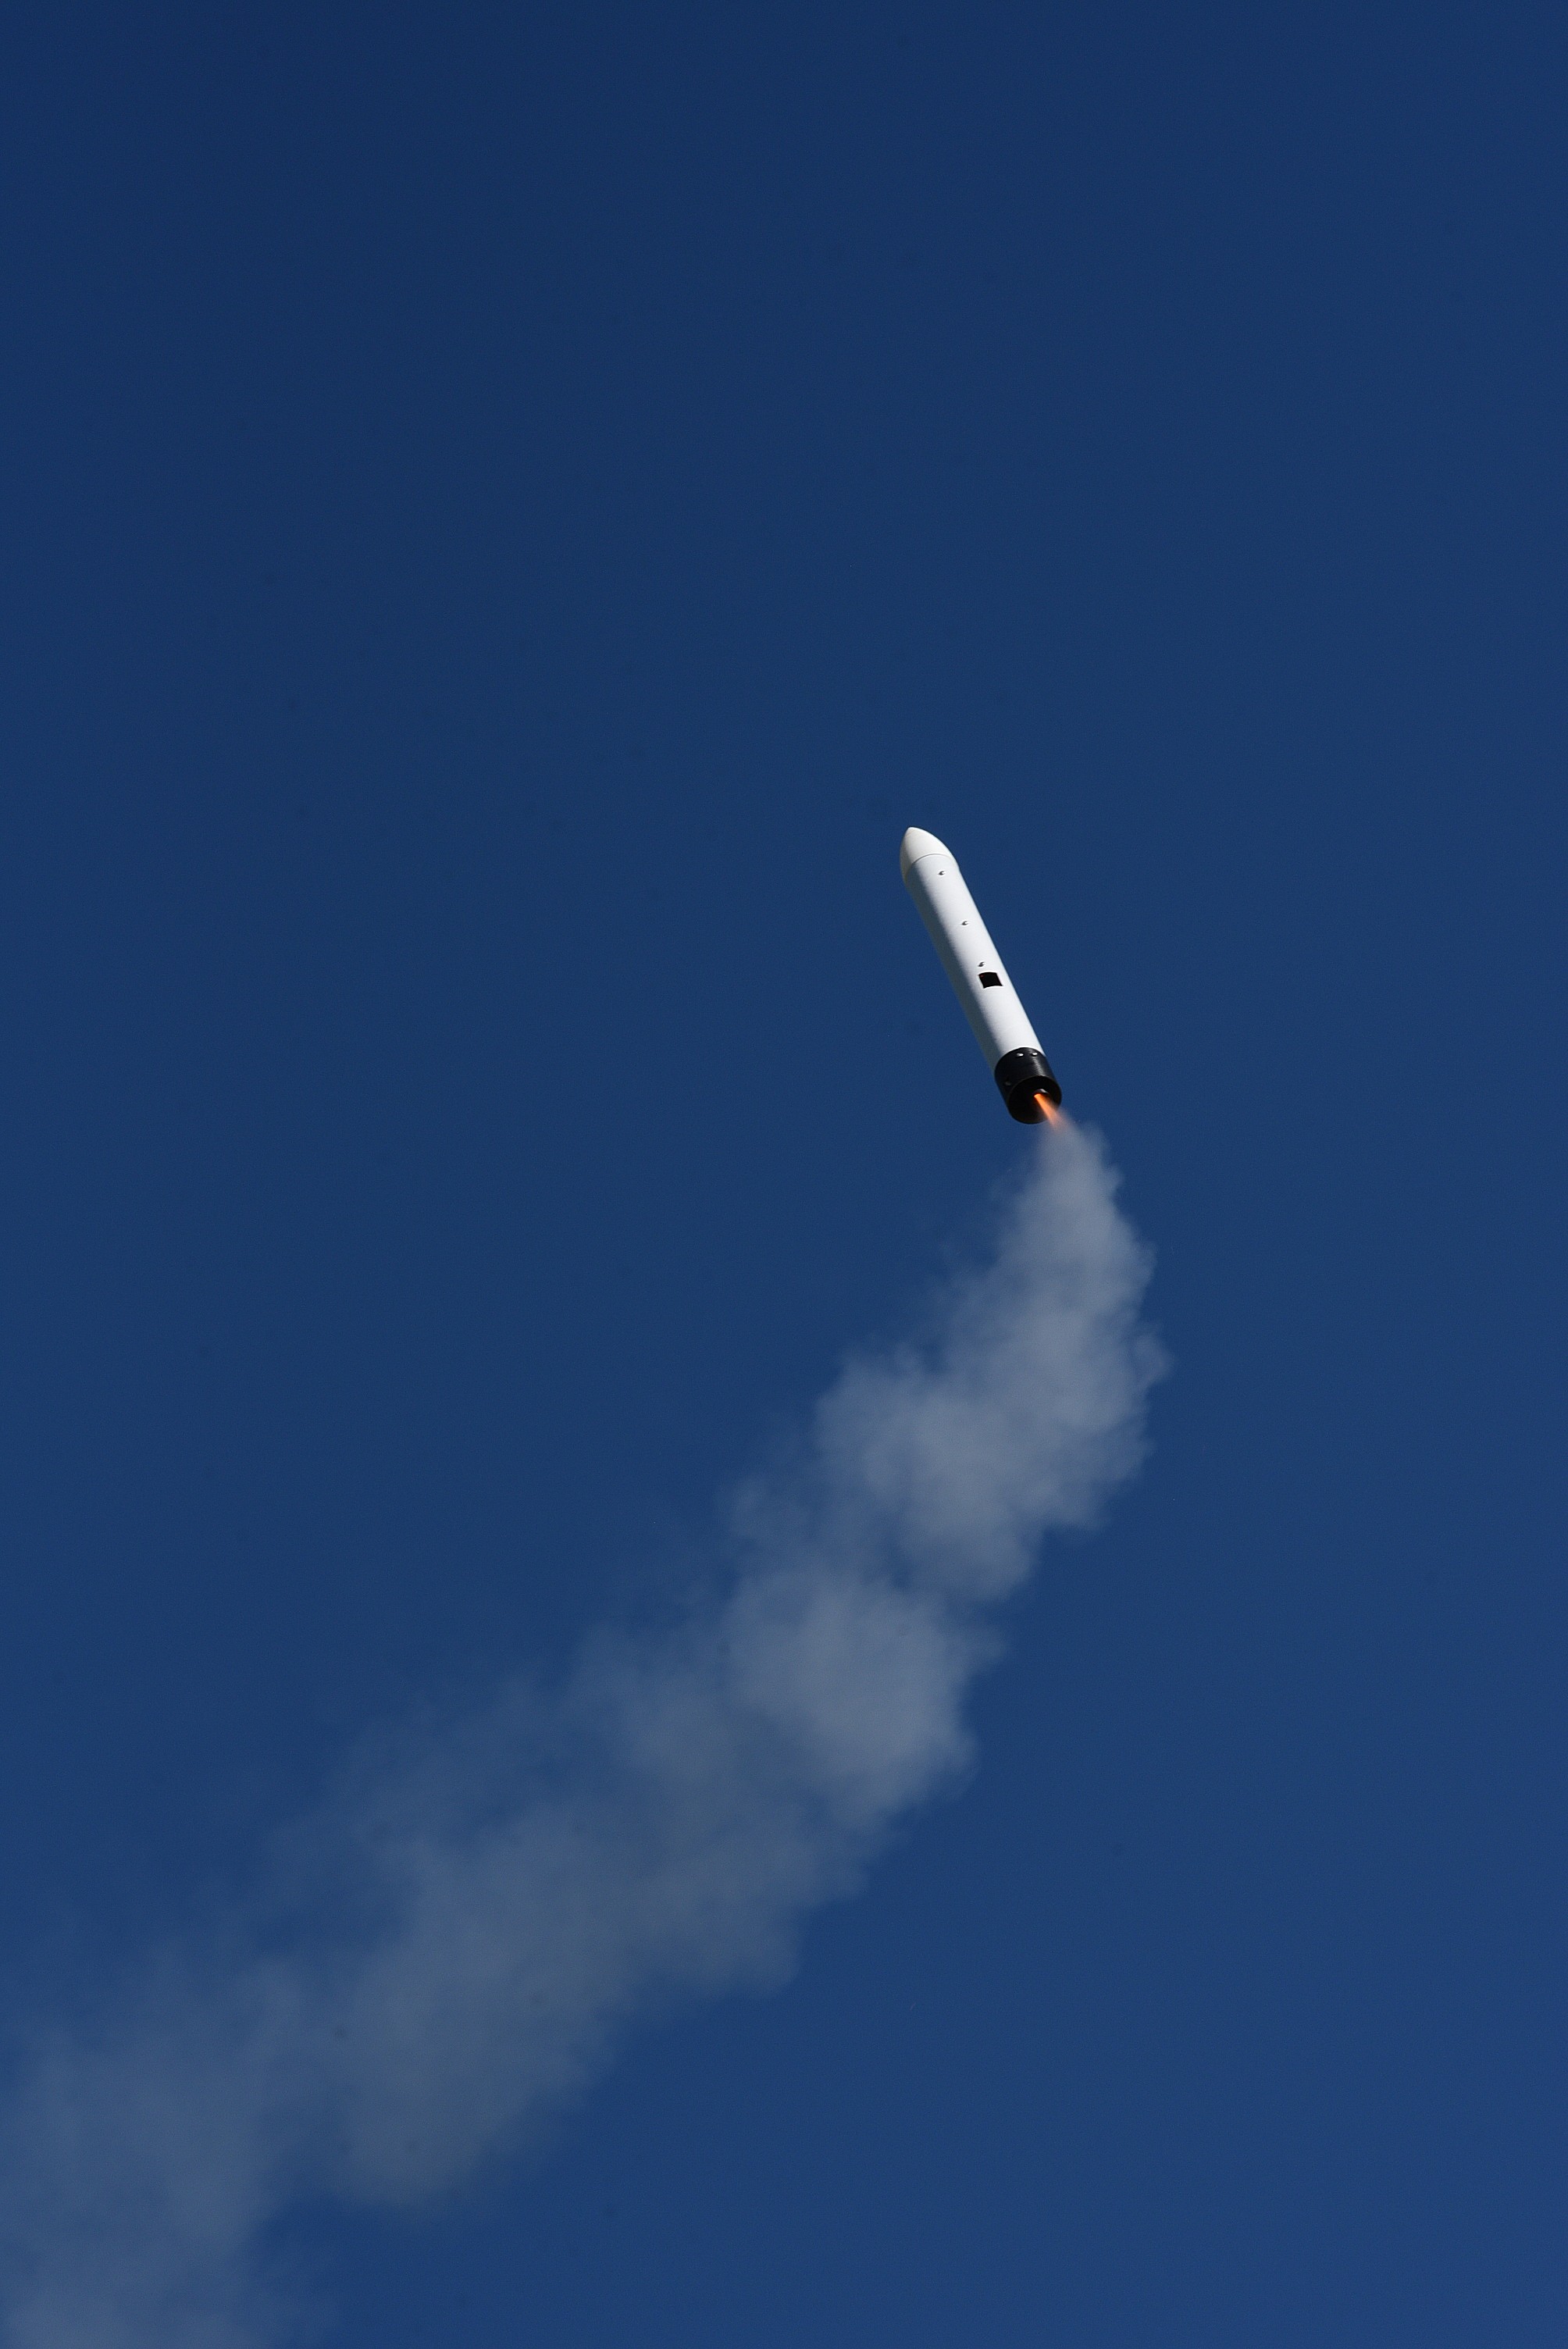
ALTAI - TVC Rocket

Mechanical Design & Stabilization Software Lead

Thrust-vector-controlled rocket developed as an advanced flight computer testbed for Embler Control Systems.

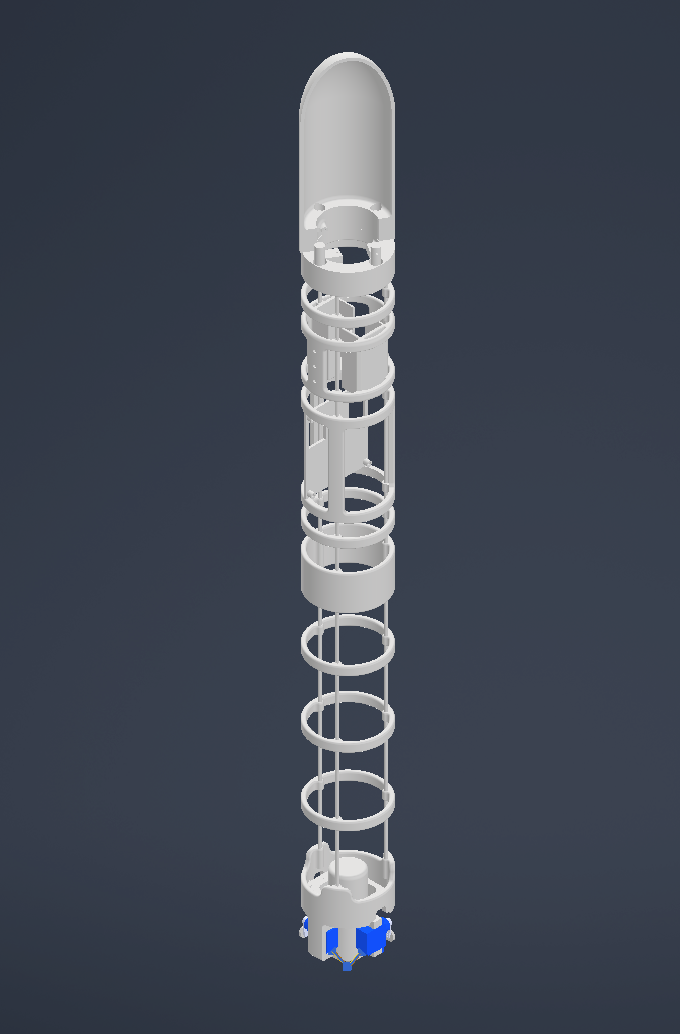
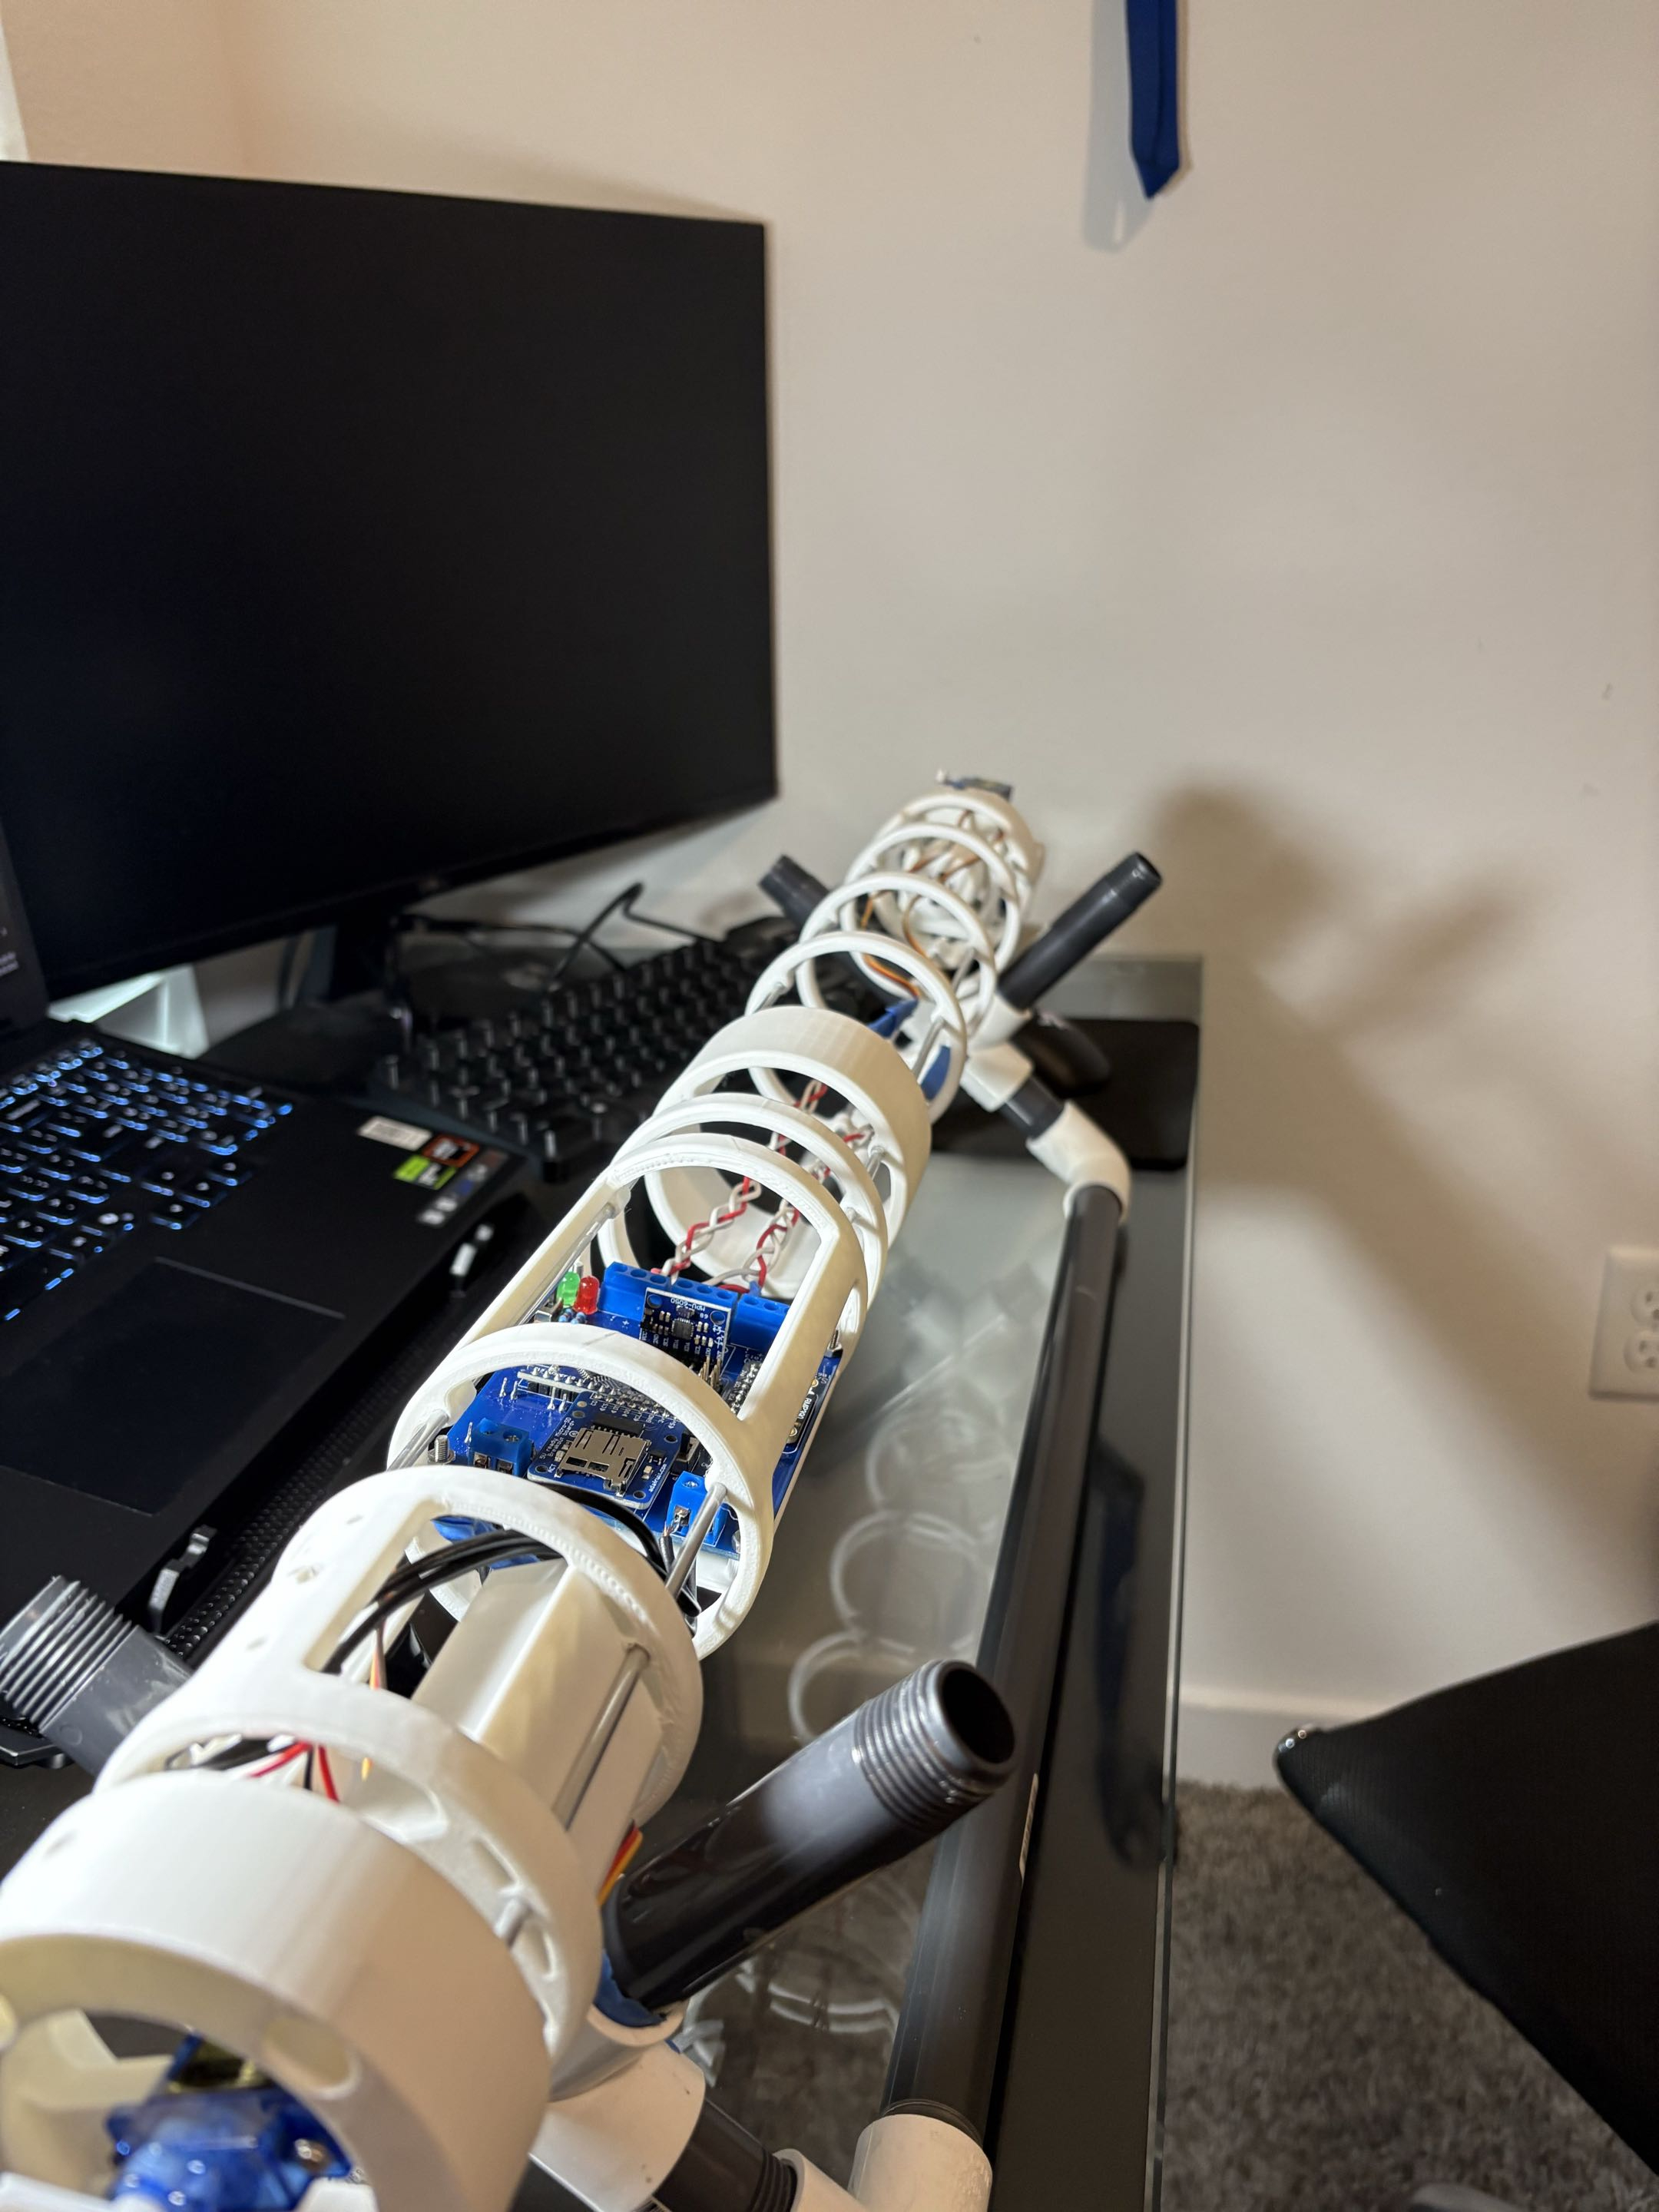
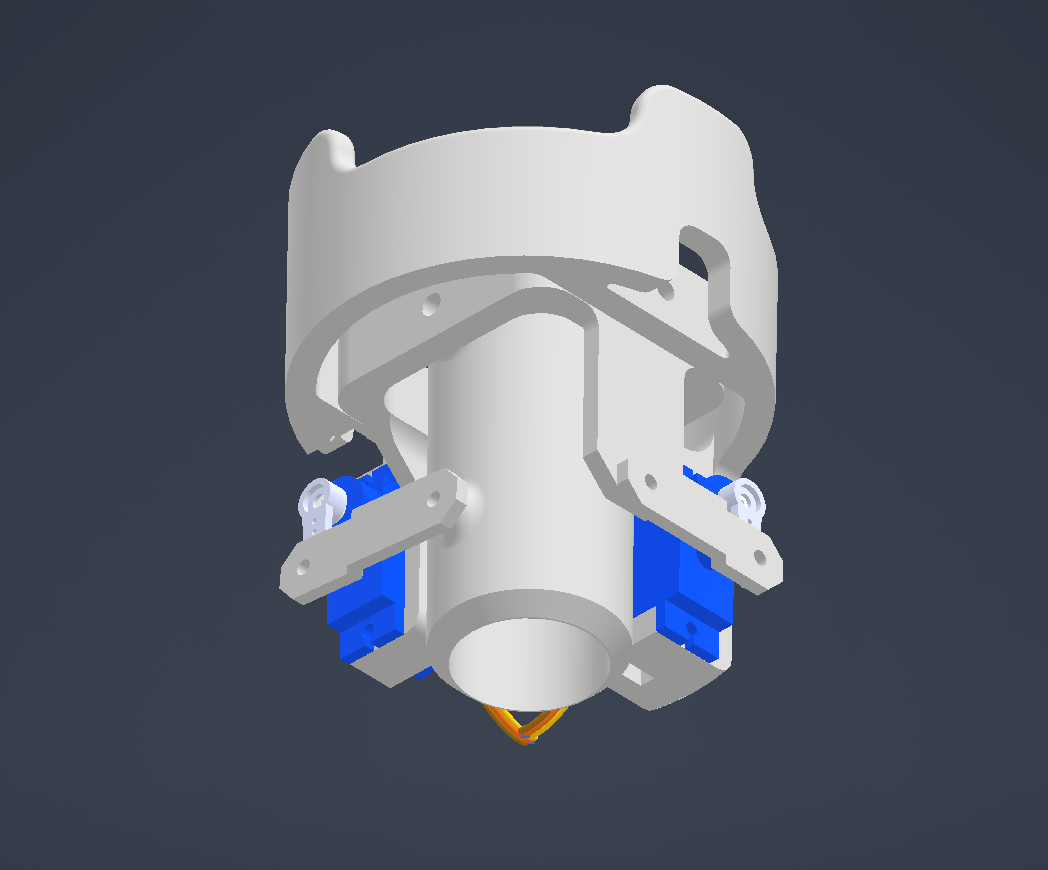
  • Designed and manufactured the internal rocket architecture to secure sensitive equipment during flight, deploy a recovery stage electronically without pyro lines or deployment charges, and stabilize the rocket without fins via a two-axis gimbal.
  • Led development of stabilization control software using quaternion analysis that saw success across multiple low-altitude launches.
  • TVC
  • Two-Axis Gimbal
  • Quaternion Control
  • Embedded Systems
  • Flight Testbed
More detailHide detail

Overview

ALTAI is a thrust vector controlled model rocketry system designed as a high-performance testbed for the Embler Control Systems flight computers. I see TVC stabilization of a finless rocket as an excellent demonstration of what a flight computer can do: rapidly process sensor inputs, run control algorithms, and give precise control outputs throughout a flight, even at a small scale.

The rocket is a simple external shell around a self-supporting internal architecture that holds all the avionics and output systems, like the gimbal.

Team and role

The team is the same as SAMSARA's. I completed most of the early design work, and Yusong Liang, an undergraduate, contributed extensively on the software side. For more on the teams and the company, see the Embler Control Systems website.

Hardest problem

The hardest technical problem was the software. Arduino Nanos are fantastic learning tools, but they hit a wall when parsing sensor inputs quickly and running controls out to servo motors. TVC is also a demanding area of model rocketry with very little documentation on proper implementation. Getting effective gimbal actuation took studying the basics of quaternion analysis, borrowing ideas from camera stabilization gimbal software, and a long iteration process within the limited computation and memory of an Arduino Nano.

Flights

ALTAI has flown more than 5 times, carrying SAMSARA V1 (and V0 once). Flights reach roughly 30-40 ft at low velocity, primarily on D class motors, chosen deliberately to produce low-velocity test hops that allow closer study of the stabilization.

During one of our most successful launches, the system recovered and held a vertical trajectory despite the low velocity and a gust of over 20 mph. Unfortunately, the data from that flight was lost. Power disconnected on impact and interrupted the SD card write. That has since been fixed: the computer now detects altitude and finalizes data recording before landing.

Recovery stage

We designed a recovery stage that needs no deployment charges. The parachute sits in the nose cone, which is made of two spring-loaded fairings held shut by pins. A servo pulls the pins when the computer's altimeter detects apogee.

Status

Use and development of the rocket have slowed while we focus on bench testing the new flight computer. The implementation team is reworking the architecture to be lighter, more precise, and to fit the new computer, which will soon begin test flights for full validation.

Testing & Analysis · Robotics Intelligent Learning Lab

Actuator Torque Testbed

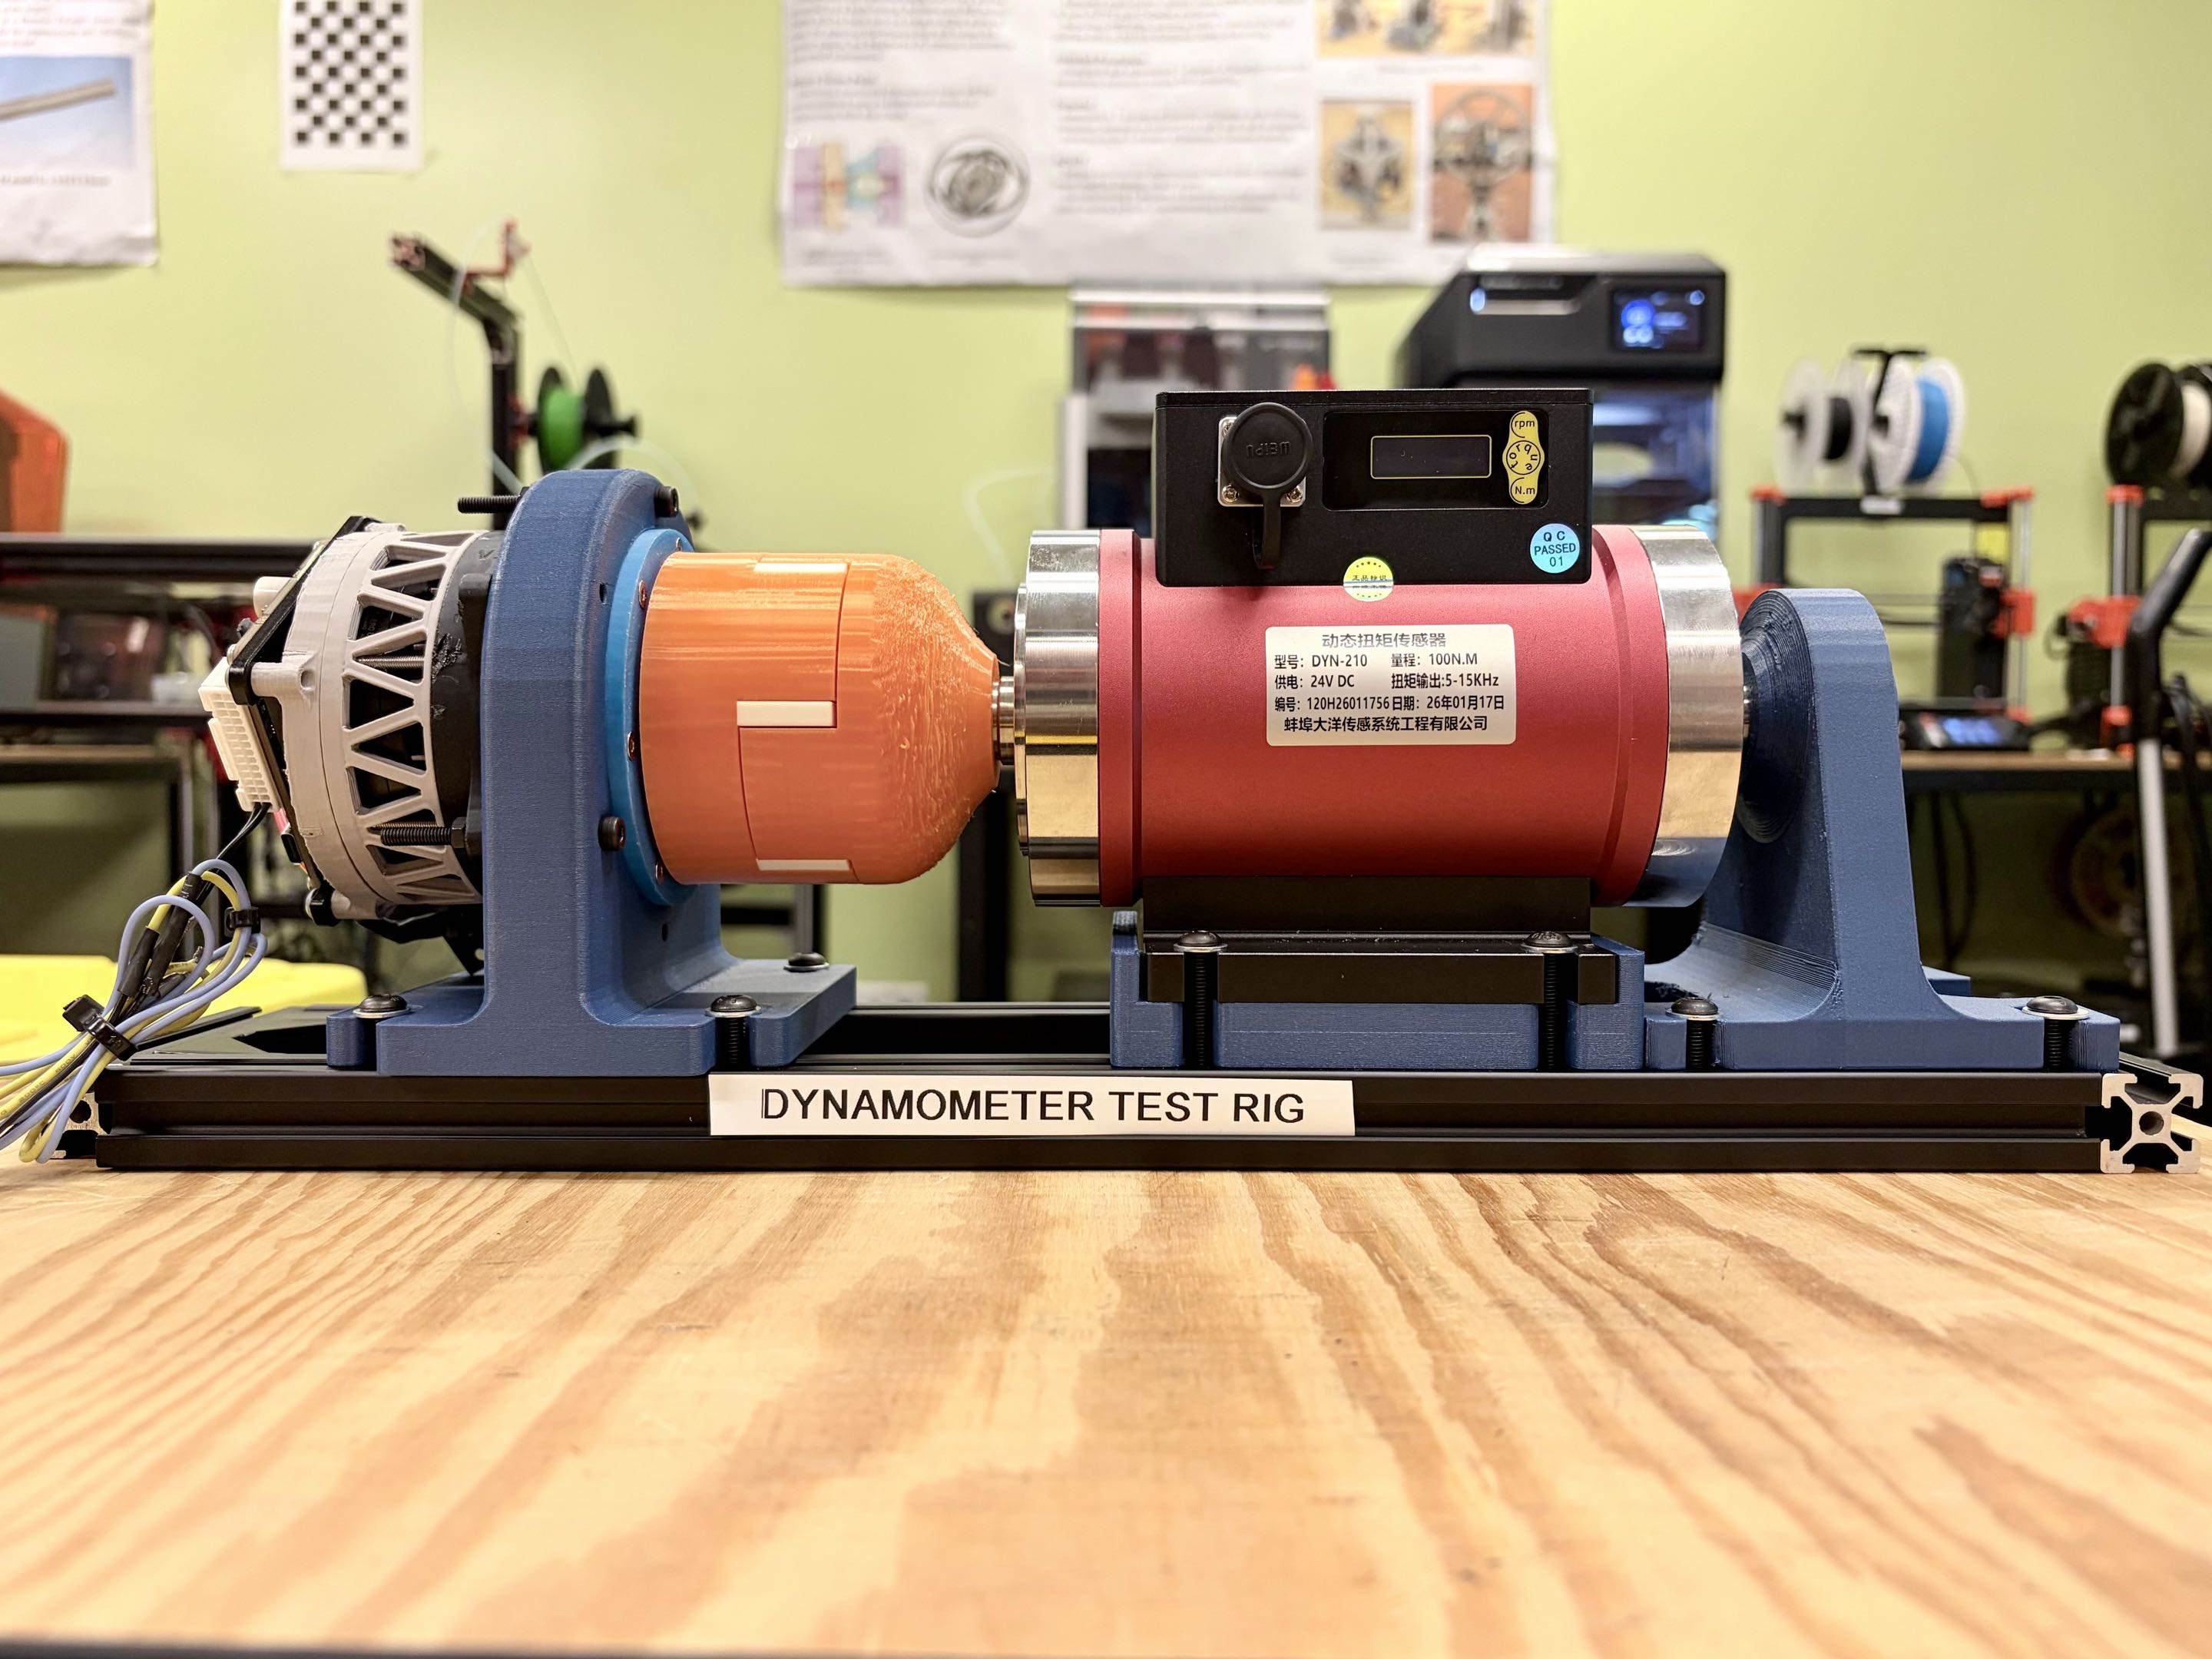
Custom testbed for analyzing torque transmission and mechanical efficiency of actuators under various loads up to 100 Nm.

  • Designed the experimental procedure for evaluating custom actuators, designed and manufactured an adjustable testing apparatus to accommodate multiple actuators, and configured a microcontroller with voltage dividers and pullup resistors to receive sensor signals.
  • Performed the experimental procedure on two unique actuators, with data analysis in Arduino IDE, Excel, and MATLAB.
  • Mechanical Design
  • Experimental Design
  • Data Analysis
  • Sensors
  • MATLAB
More detailHide detail

Overview

This project was built to do in-depth analysis of the custom 3D printed cycloidal actuators developed for LECTER. I developed the platform and studied the actuators alongside Manuel Buenrostro. I designed much of the testing rig and tried to make it as modular and adjustable as possible so other actuators can be tested later. Manuel designed the spider coupling that connects the motor to the dynamometer and helped with the overall rig.

I also took charge of the experimental design and the microcontroller communication with the DYN-210 dynamometer, which is the core sensing device of the apparatus. Each actuator was tested with a linearly increasing torque output against sliding friction until it stalled.

Hardest problem

The hardest technical problem was communication between the controller and the DYN-210. Its output is a frequency-modulated signal that needed low-interference pullups and voltage dividers to work with the 3.3V SparkFun Pro Micro collecting the data. Documentation was limited and often roughly translated from Chinese. Getting the communication parameters right in my Arduino code was difficult, and it required my own basic Chinese along with help from native speakers I know who do not have a technical background.

Results

The testbed was used for a full evaluation of the cycloidal actuators, producing several important figures, including the key metrics of 26 Nm peak torque output and 94% torque transmission efficiency. The rig and dynamometer have a capacity of 100 Nm.

Status

The project is on hold while the feedback from the testbed is used to iterate on and improve the cycloidal actuators.

Quadruped · Engineering Physics Propulsion Lab

OpenMutt

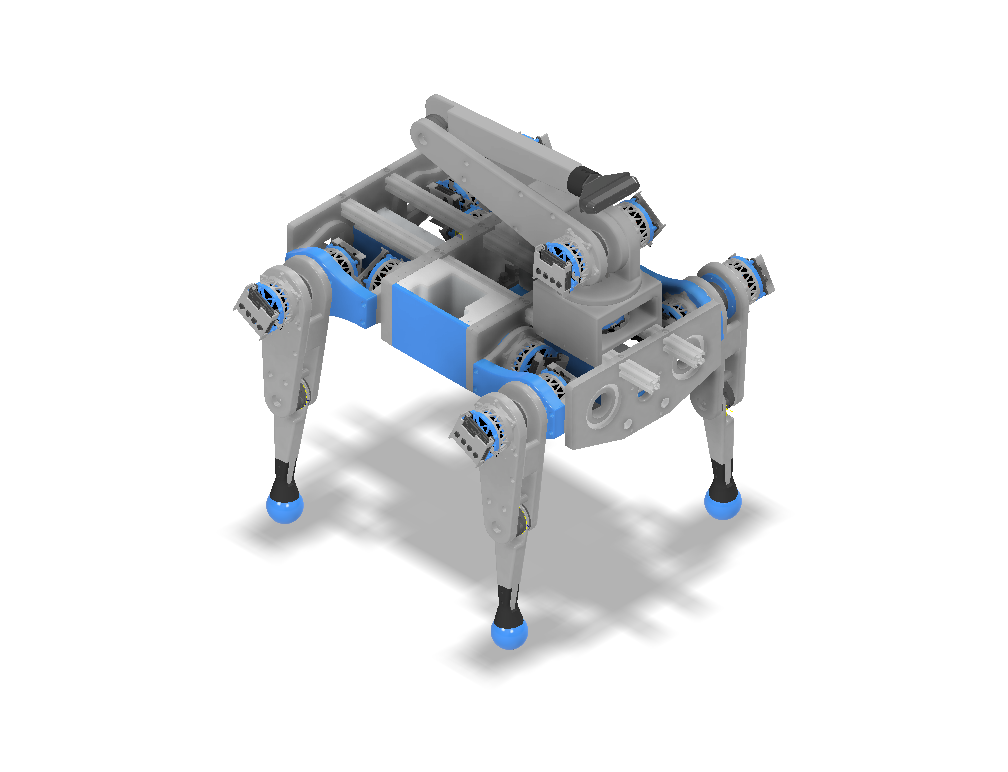
Open-source quadruped manufactured primarily through 3D printing.

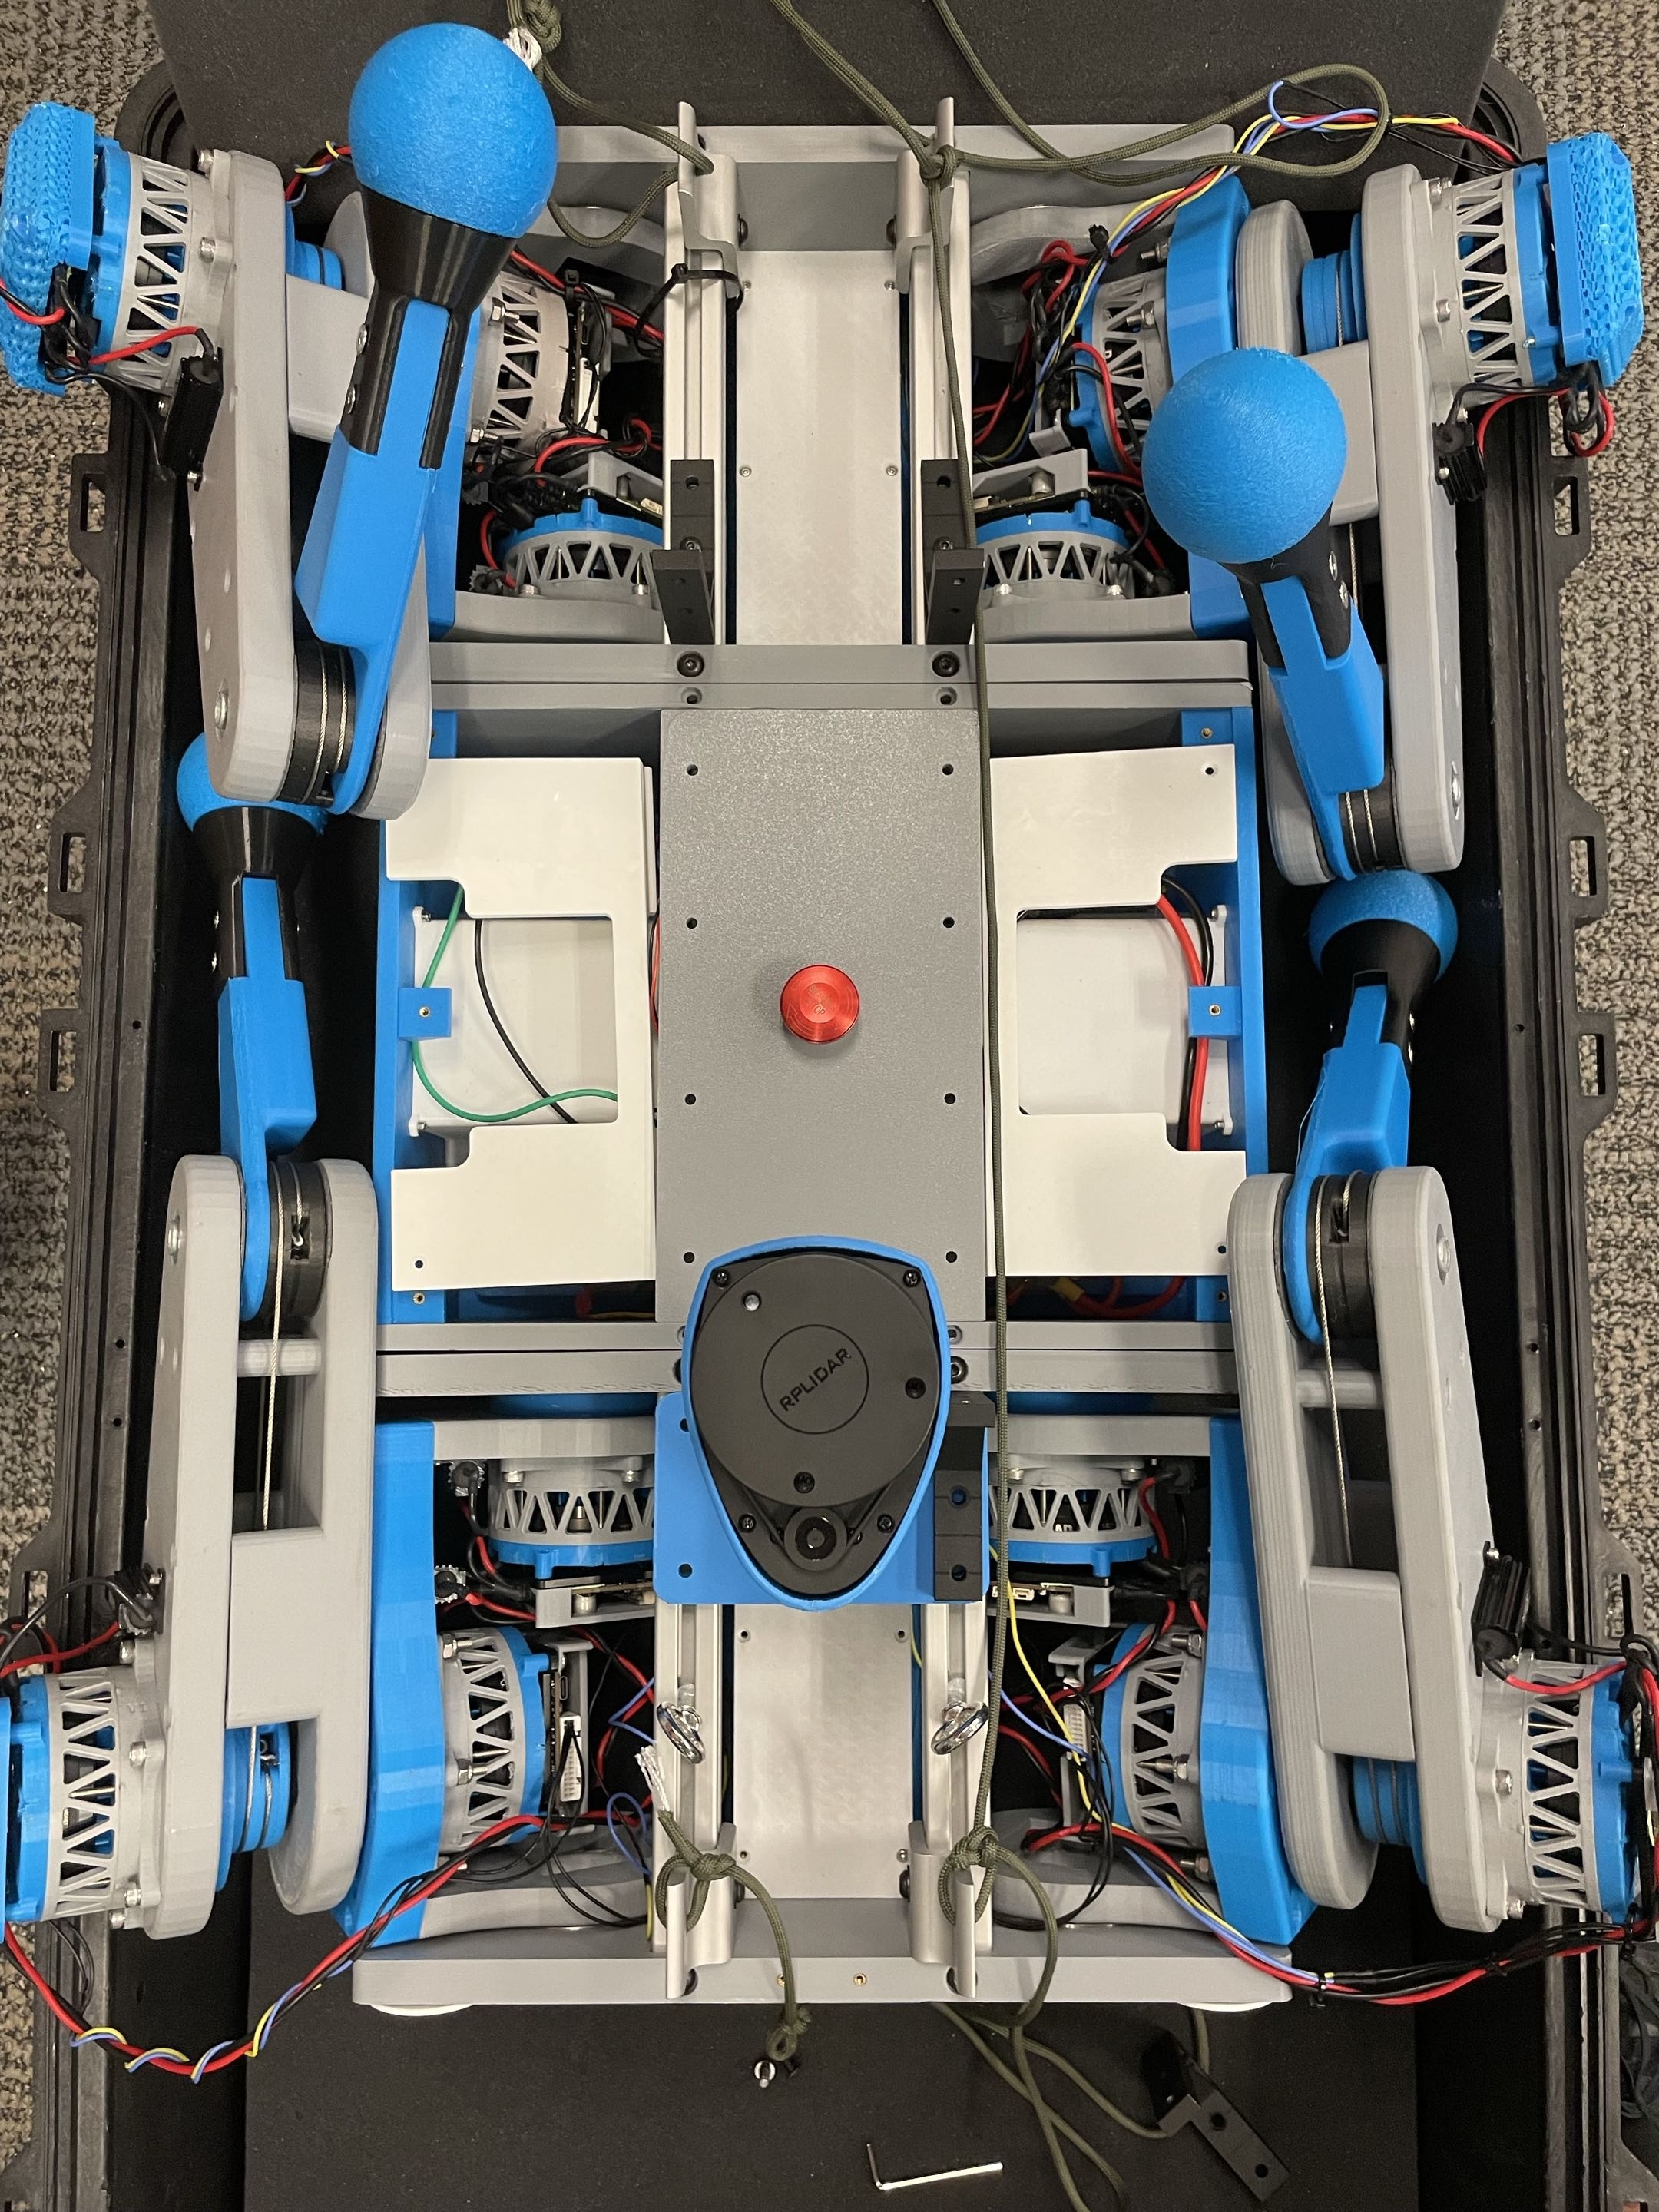
  • Redesigned the electrical enclosure for compactness, designed precision joint jigs in CAD, fabricated a LiDAR mount and auxiliary components, and produced the URDF model for implementation in ROS2.
  • Open Source
  • 3D Printing
  • CAD
  • URDF
  • ROS2
  • LiDAR
More detailHide detail

Overview

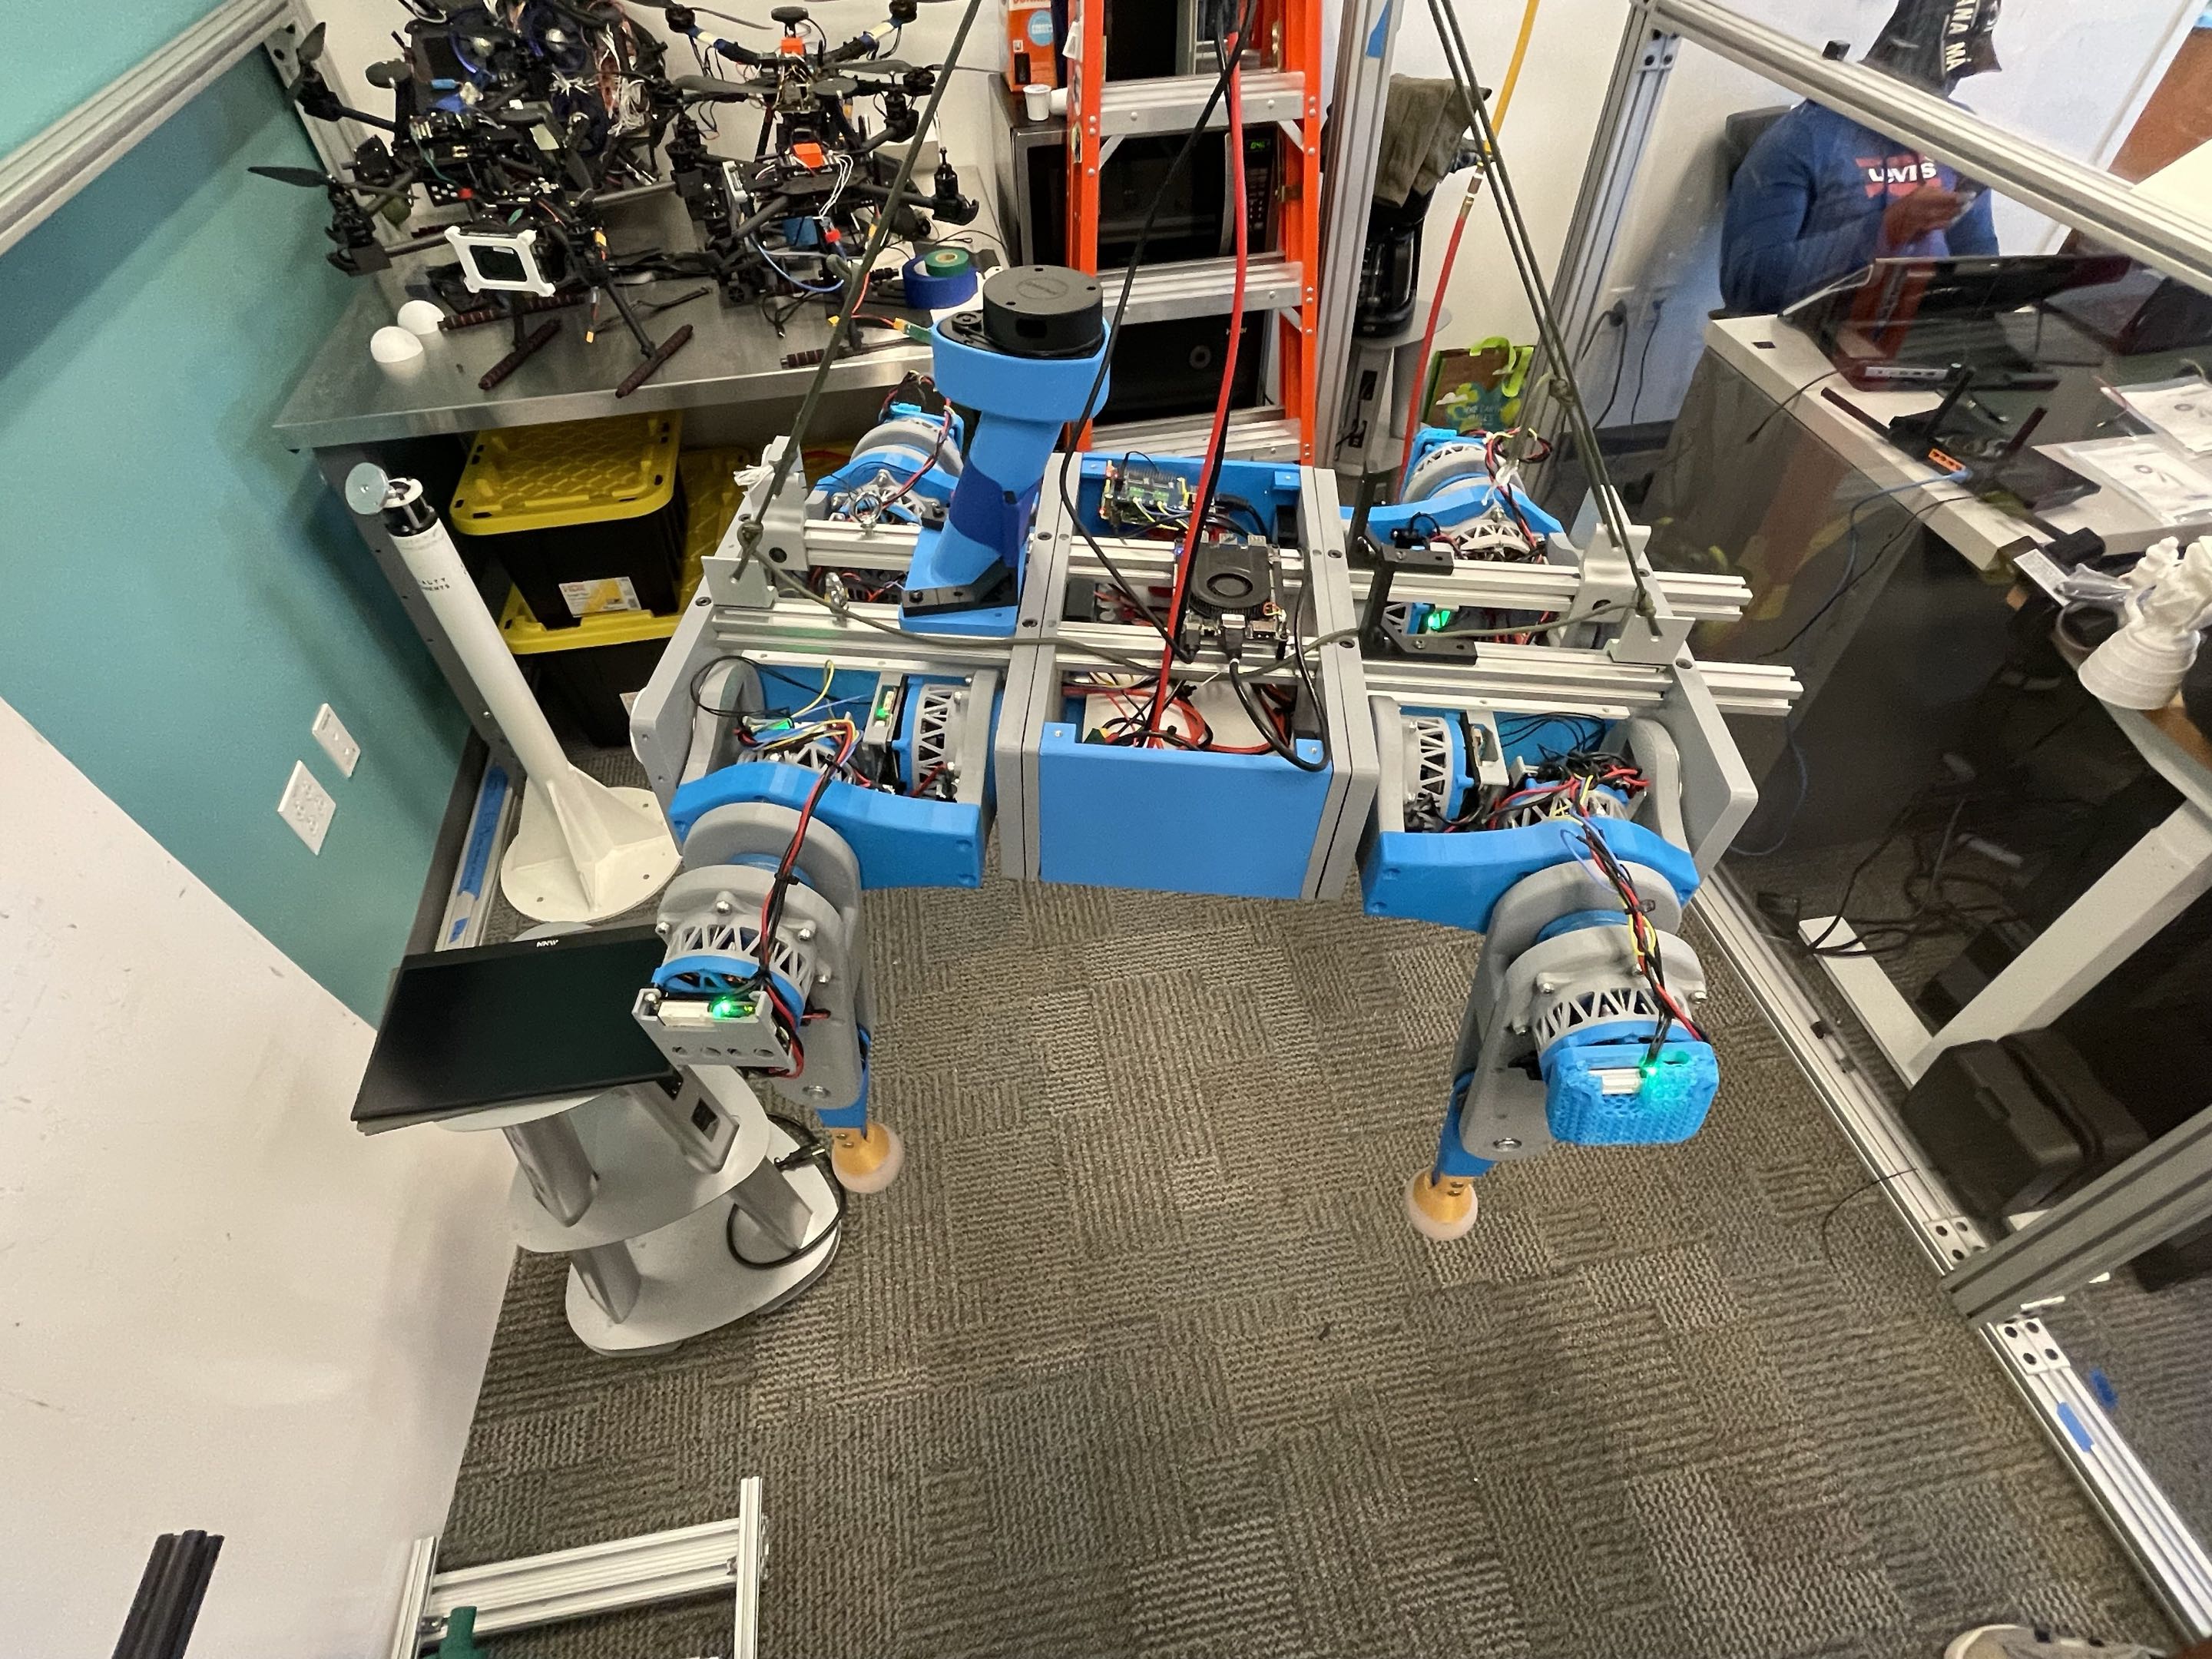
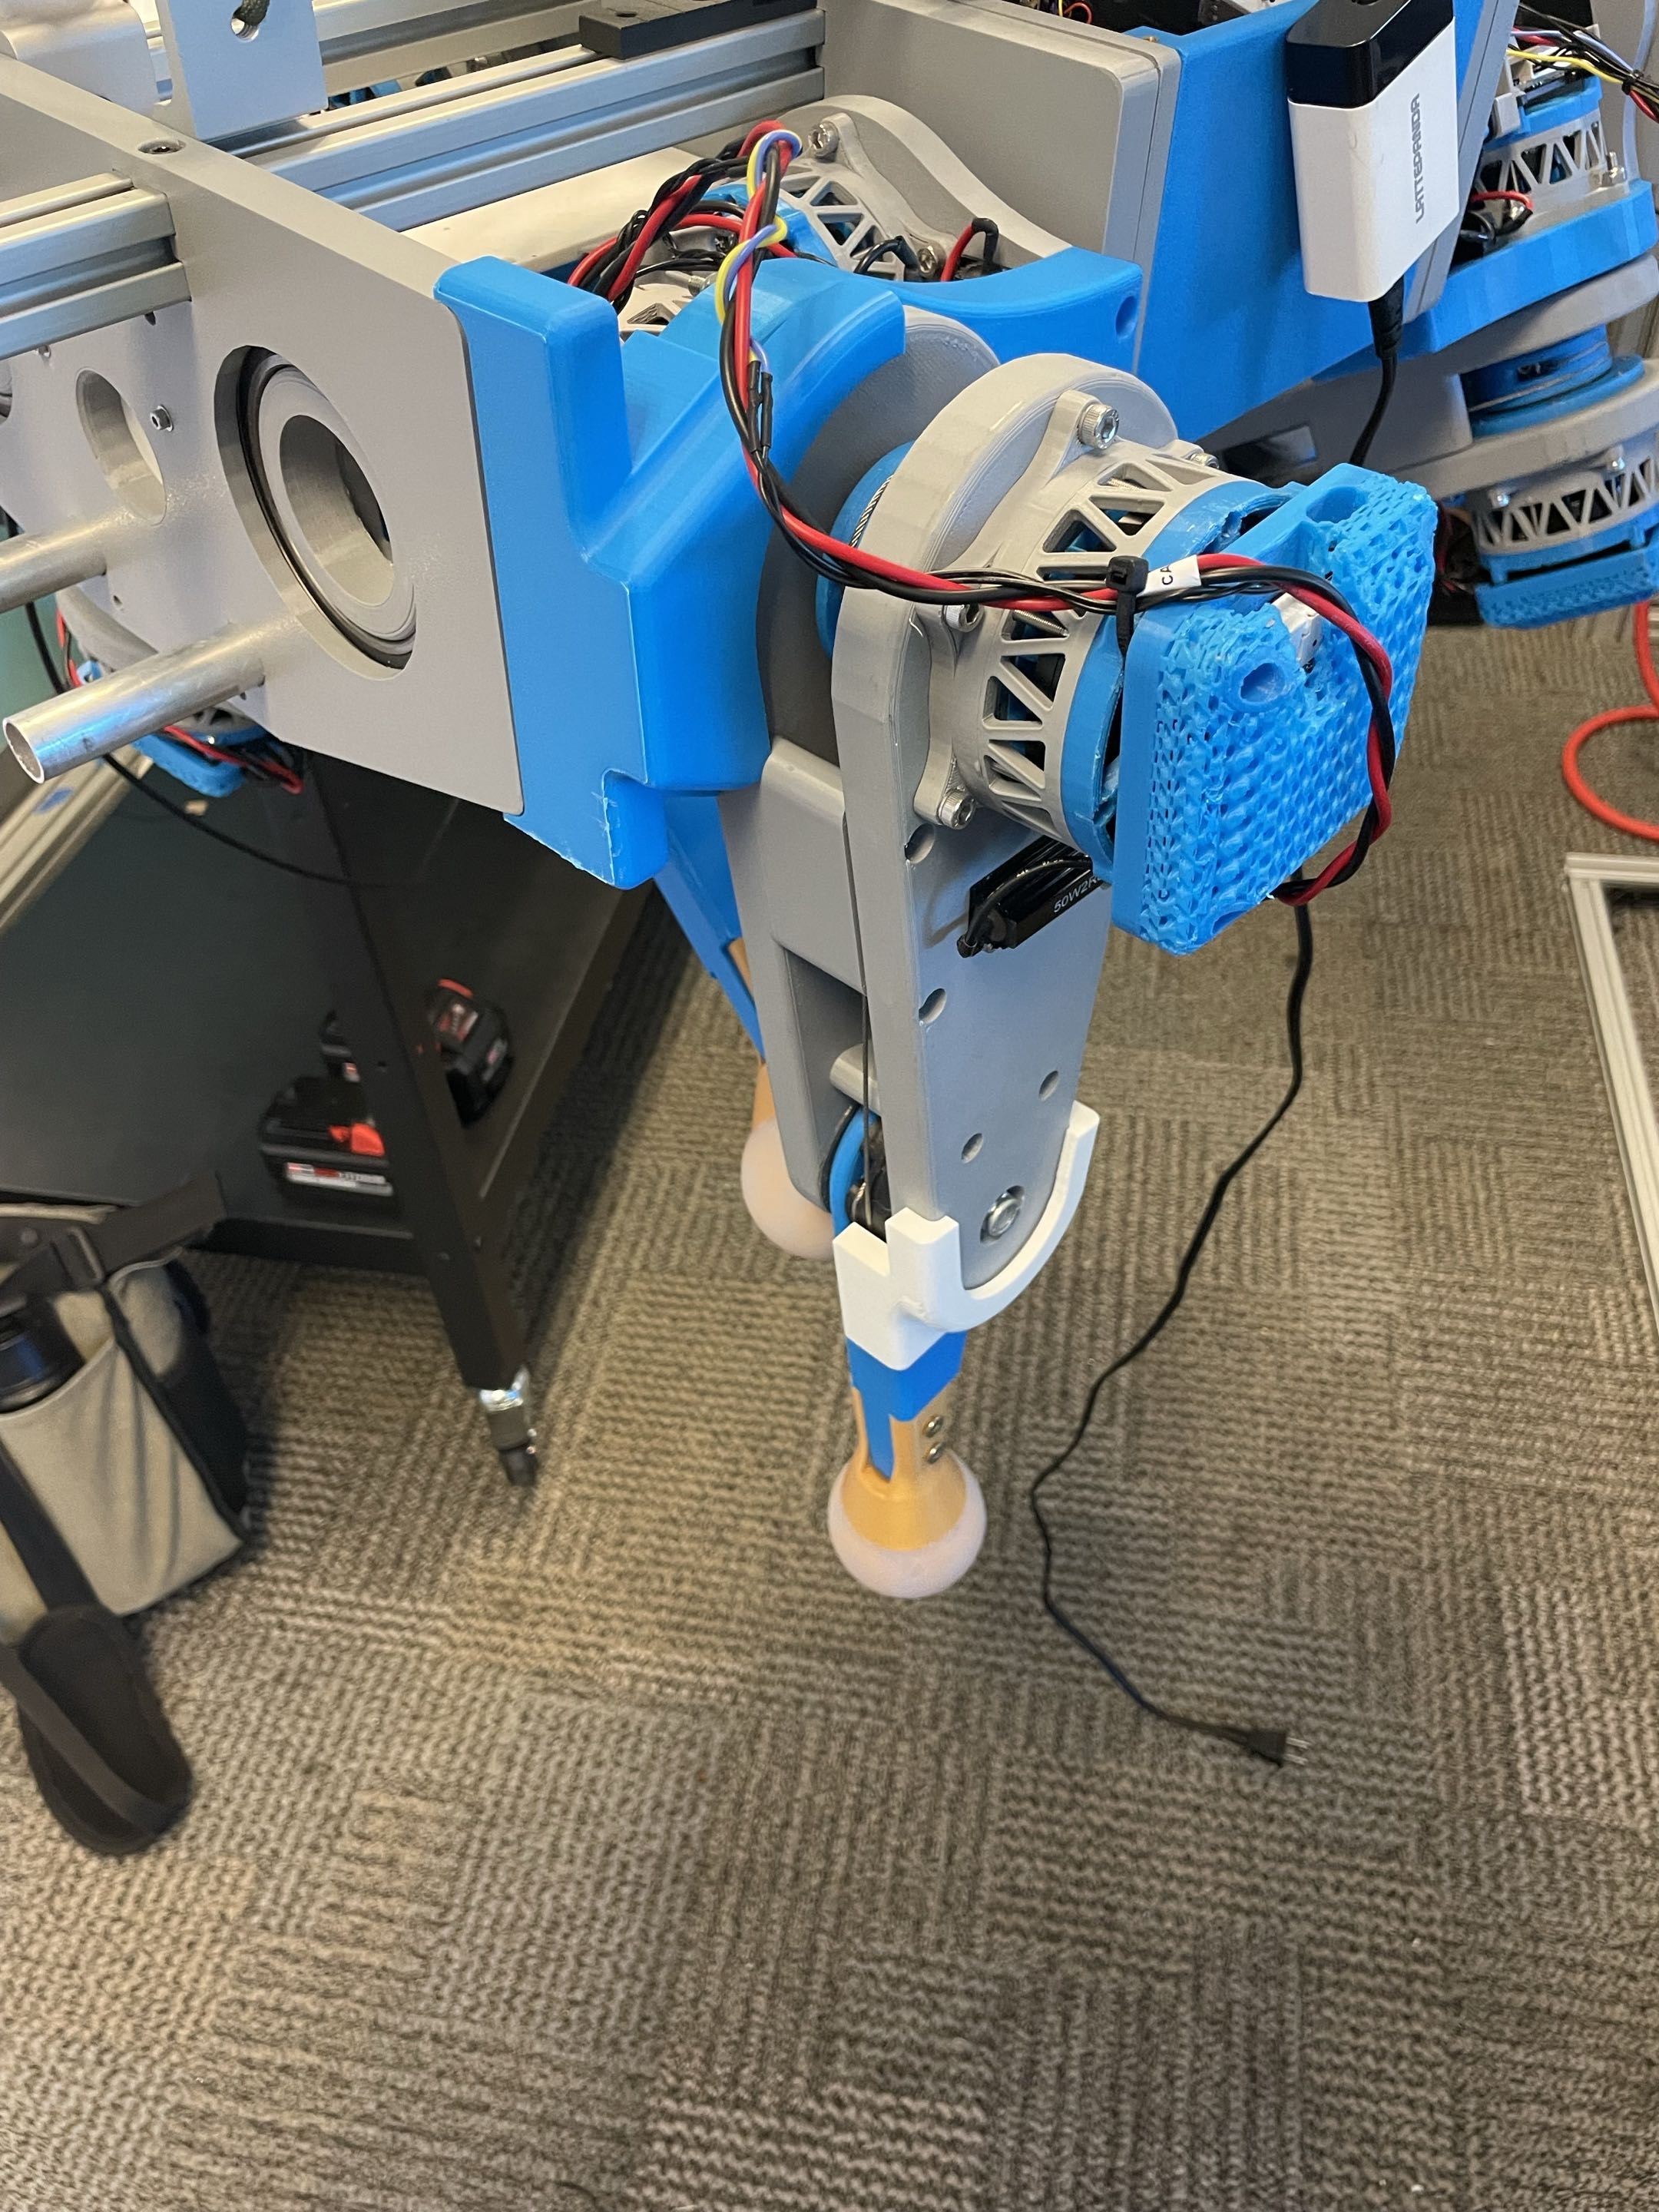
OpenMutt is a low-cost quadruped test platform that is easy to manufacture. It is an externally funded lab project of the Engineering Physics Propulsion Lab, with 12 actuators controlled by a Jetson. I joined the team as a freshman at EPPL and have been a contributing member since, working on the electrical, mechanical, and URDF parts of the project.

Joint jigs

The jigs allow the joints to be zeroed in an exact position when the controller initializes, and they keep results repeatable between testing sessions.

Hardest problem

The largest ongoing problem has been getting the gait working and overcoming the mechanical problems that interfere with the controls. In the current gait the robot holds its legs in the wrong positions, sitting too low to the ground, and its motion is not smooth enough, which often stalls motors and causes the controller to fail. At its core this is a control issue, but reducing backlash in the limbs and increasing motor torque capacity will make the control problem easier to solve in the long run. We have also worked to cut weight as much as possible through compact redesigns and 3D printed manufacturing.

Status

The quadruped has performed several walking demos in the lab (internal to the lab), primarily on a tether to take some of the weight off the robot and keep the environment controlled. Work is underway to update the cycloidal actuators for higher torque output and to improve the controller toward a consistent gait off the tether.

Robotic Arm · Engineering Physics Propulsion Lab

OpenArm

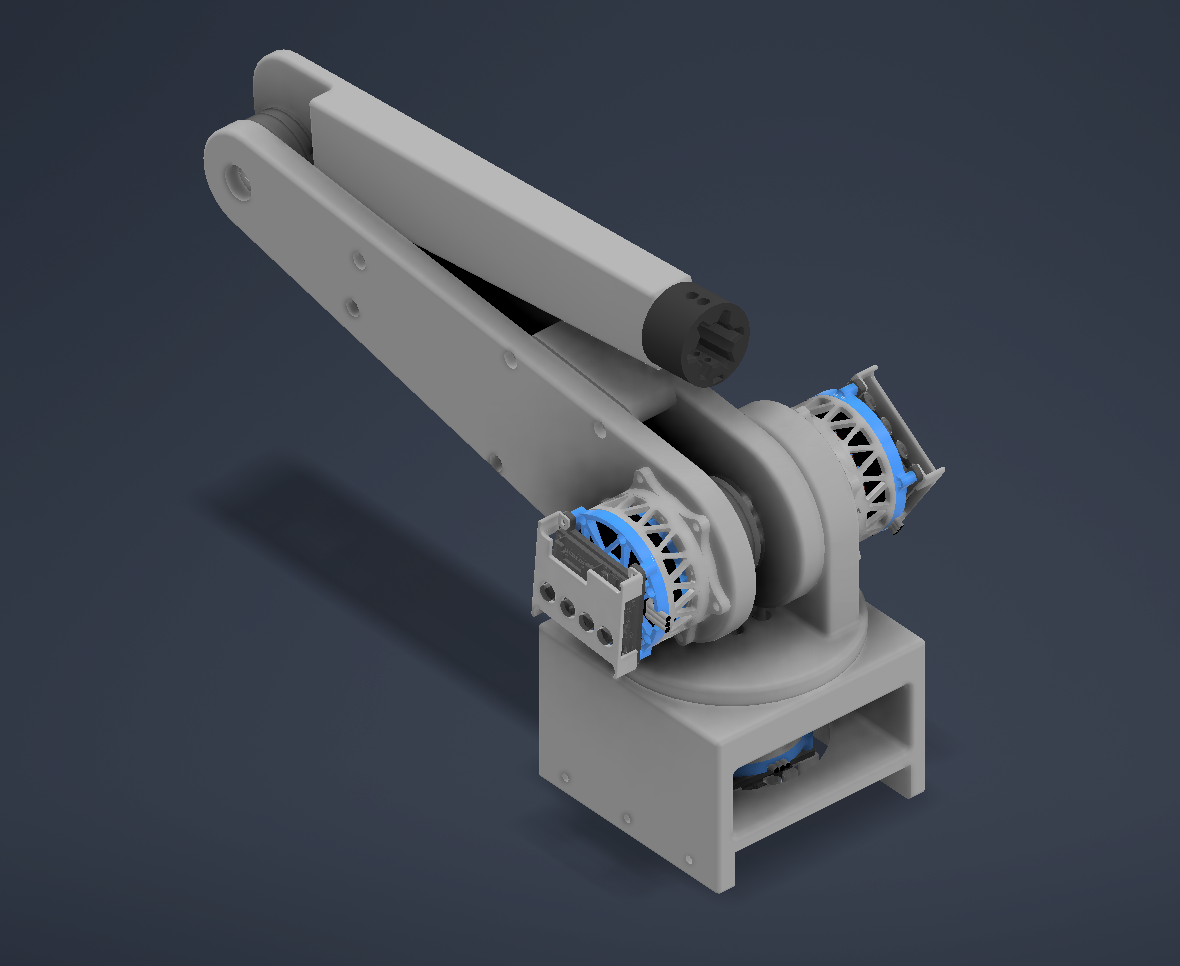
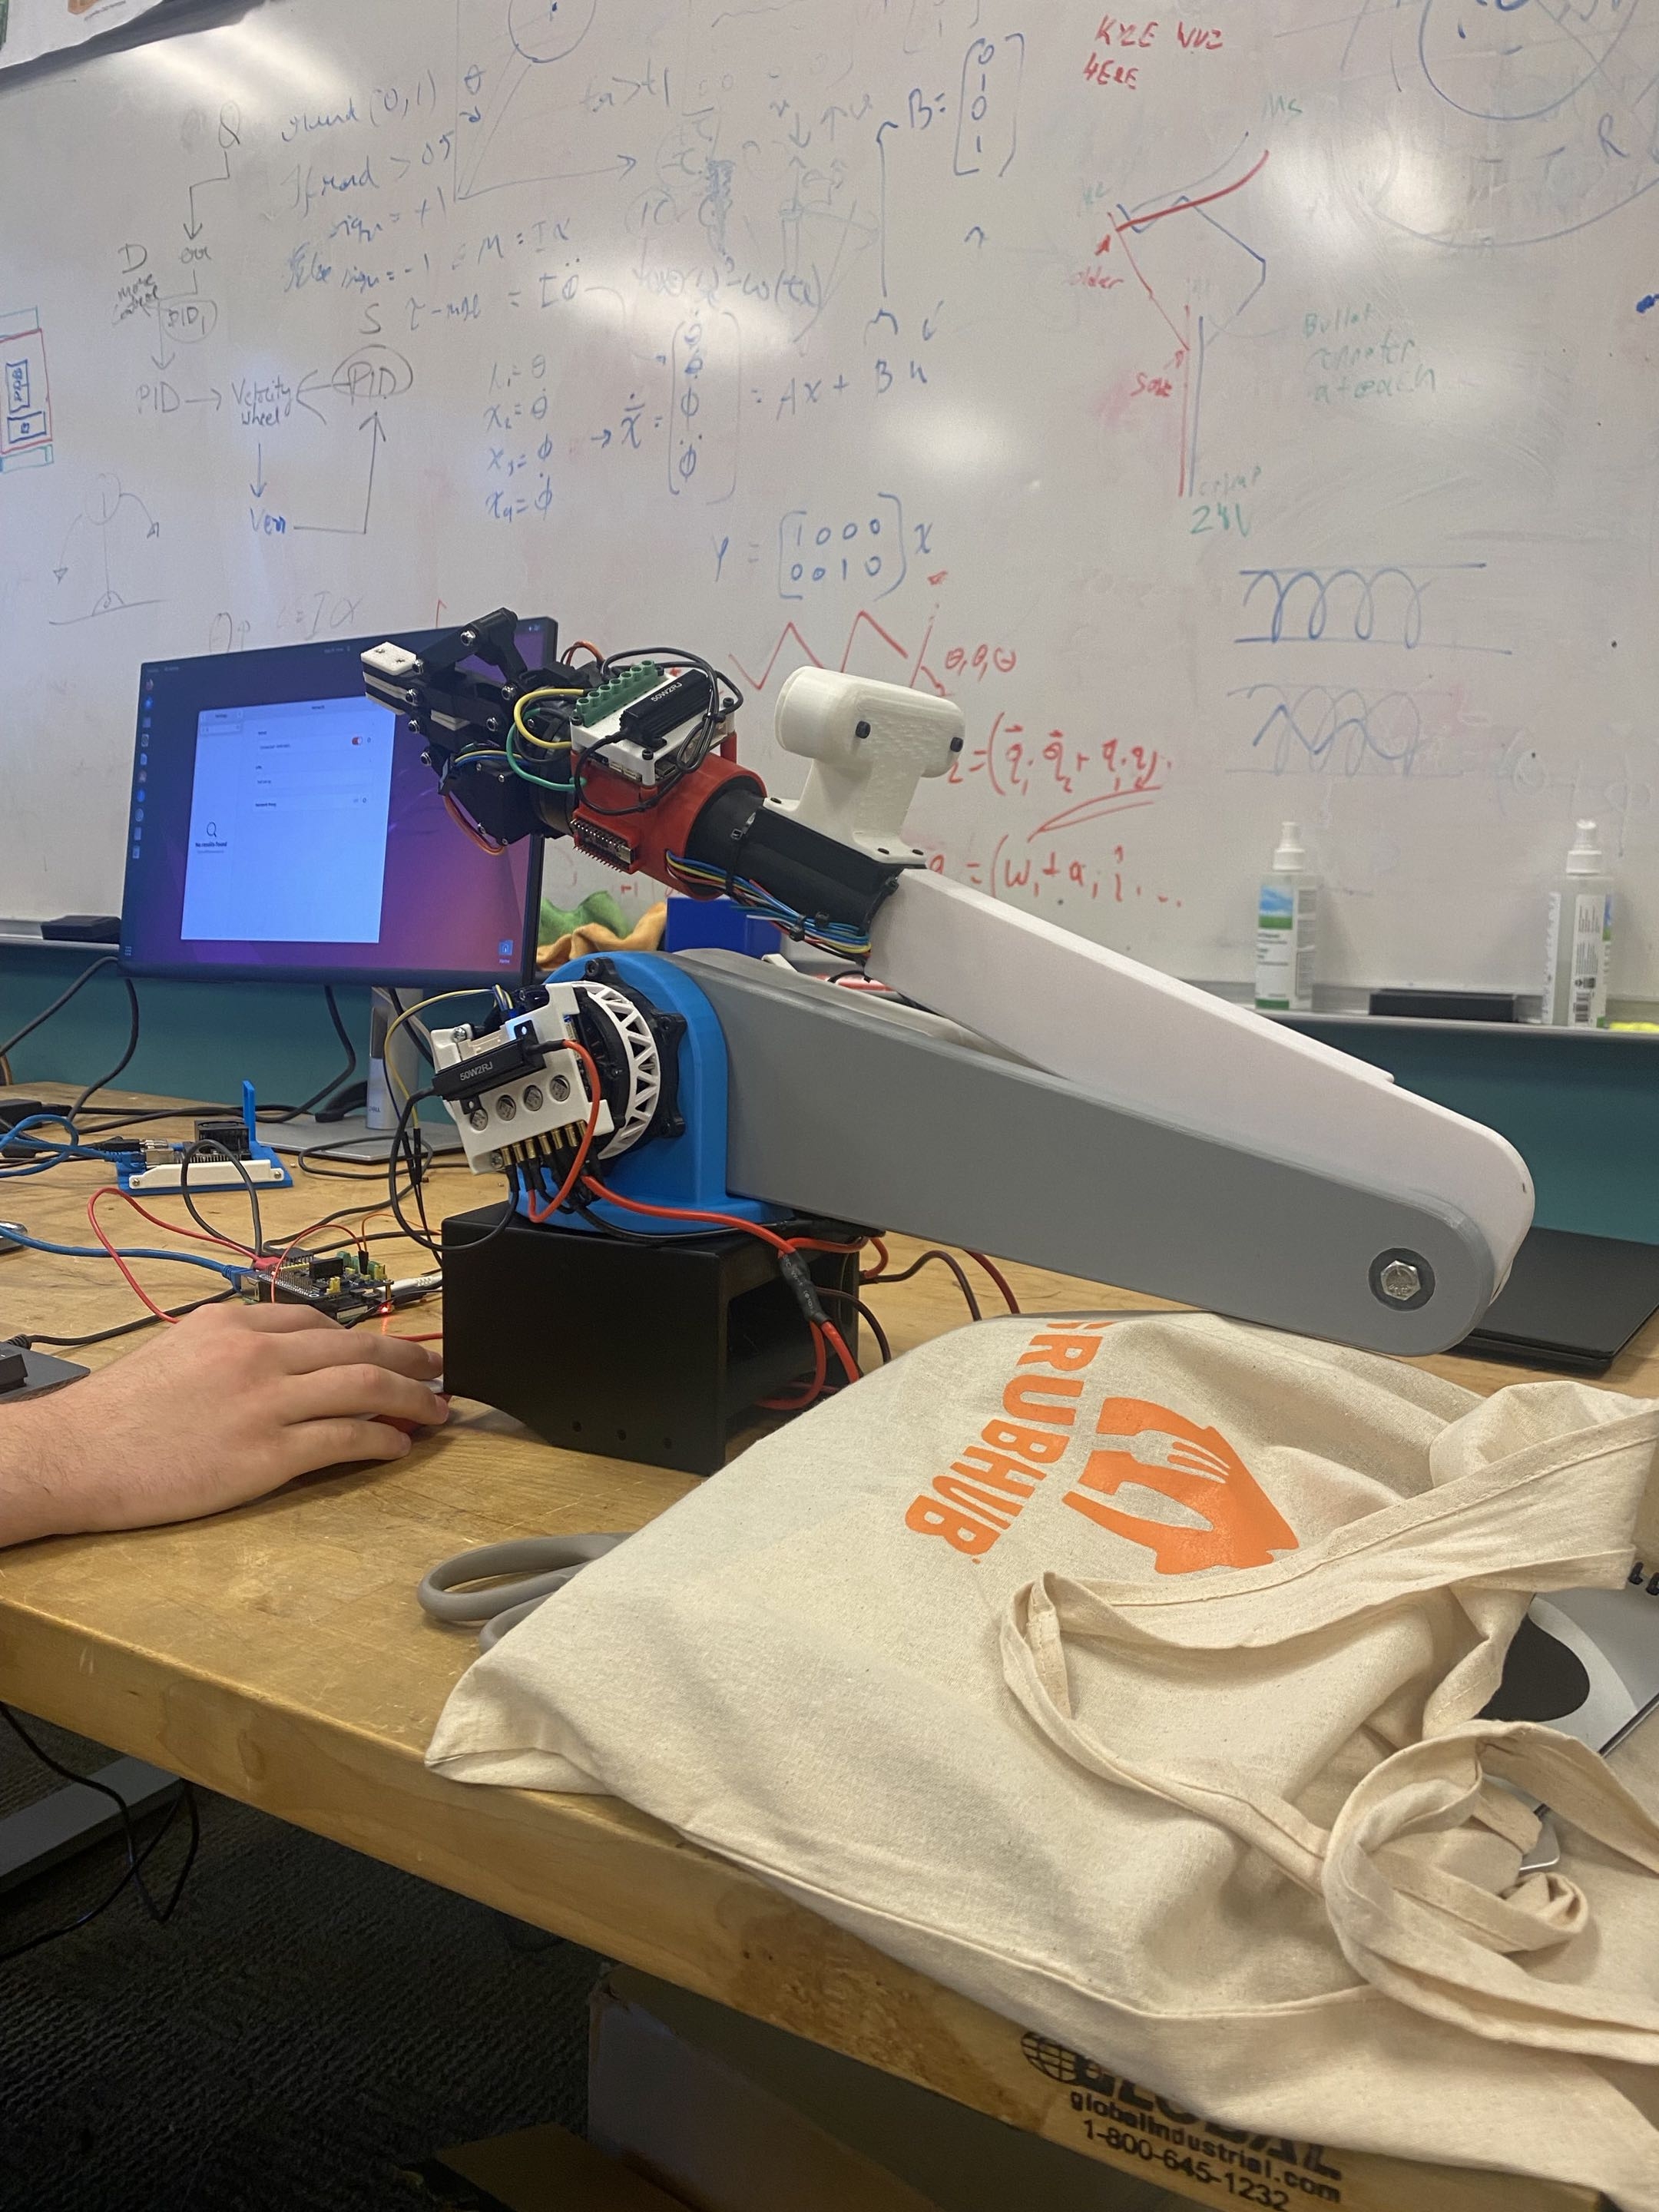
Open-source 5-DOF robotic arm designed to mount on the back of OpenMutt.

  • Led mechanical design and URDF creation, and worked on cycloidal gearbox assembly.
  • Redesigned the arm at reduced scale (4 DOF) on investor request, to be implemented as a payload for a Unitree Go2 quadruped. Under strict time constraints and investor requirements, performed static analysis of the rescaled arm, specified new actuators, designed and manufactured the new arm, and implemented a ROS2 demo of the payload for a showcase.
  • 5 DOF
  • URDF
  • Cycloidal Gearbox
  • Static Analysis
  • ROS2
  • Unitree Go2
More detailHide detail

Overview

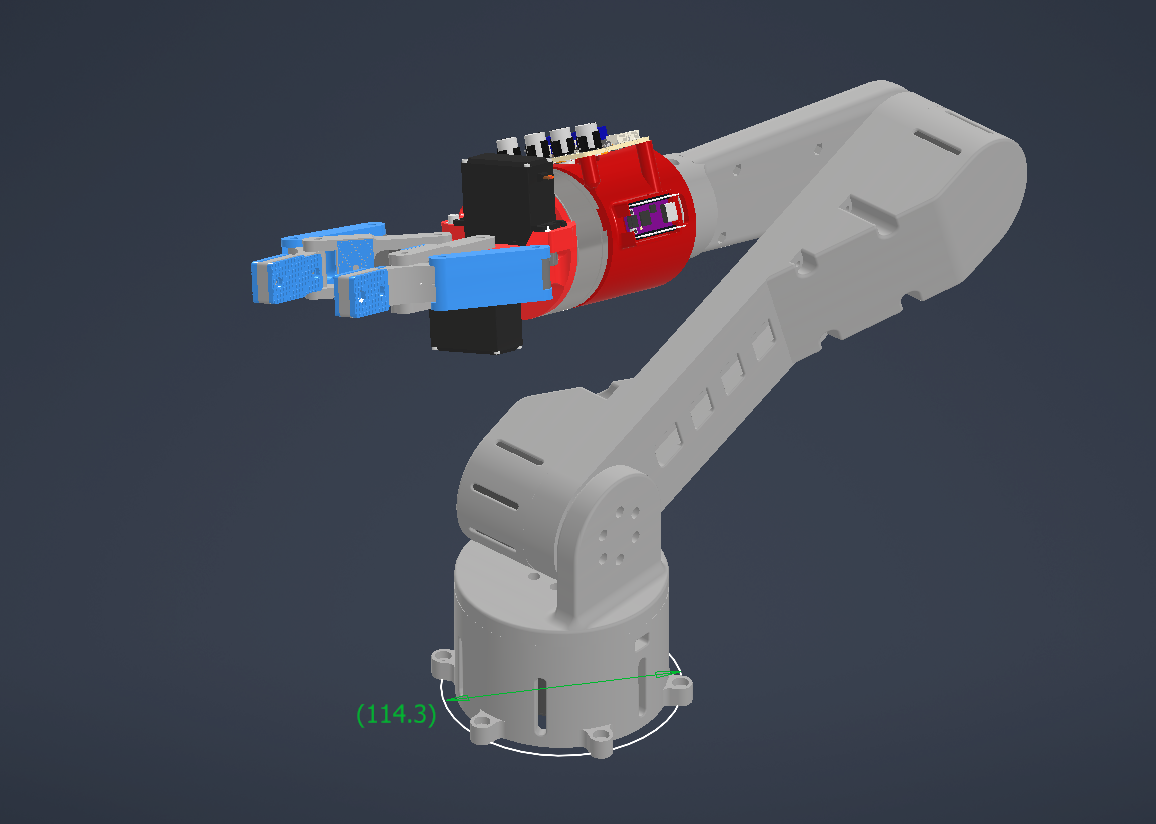
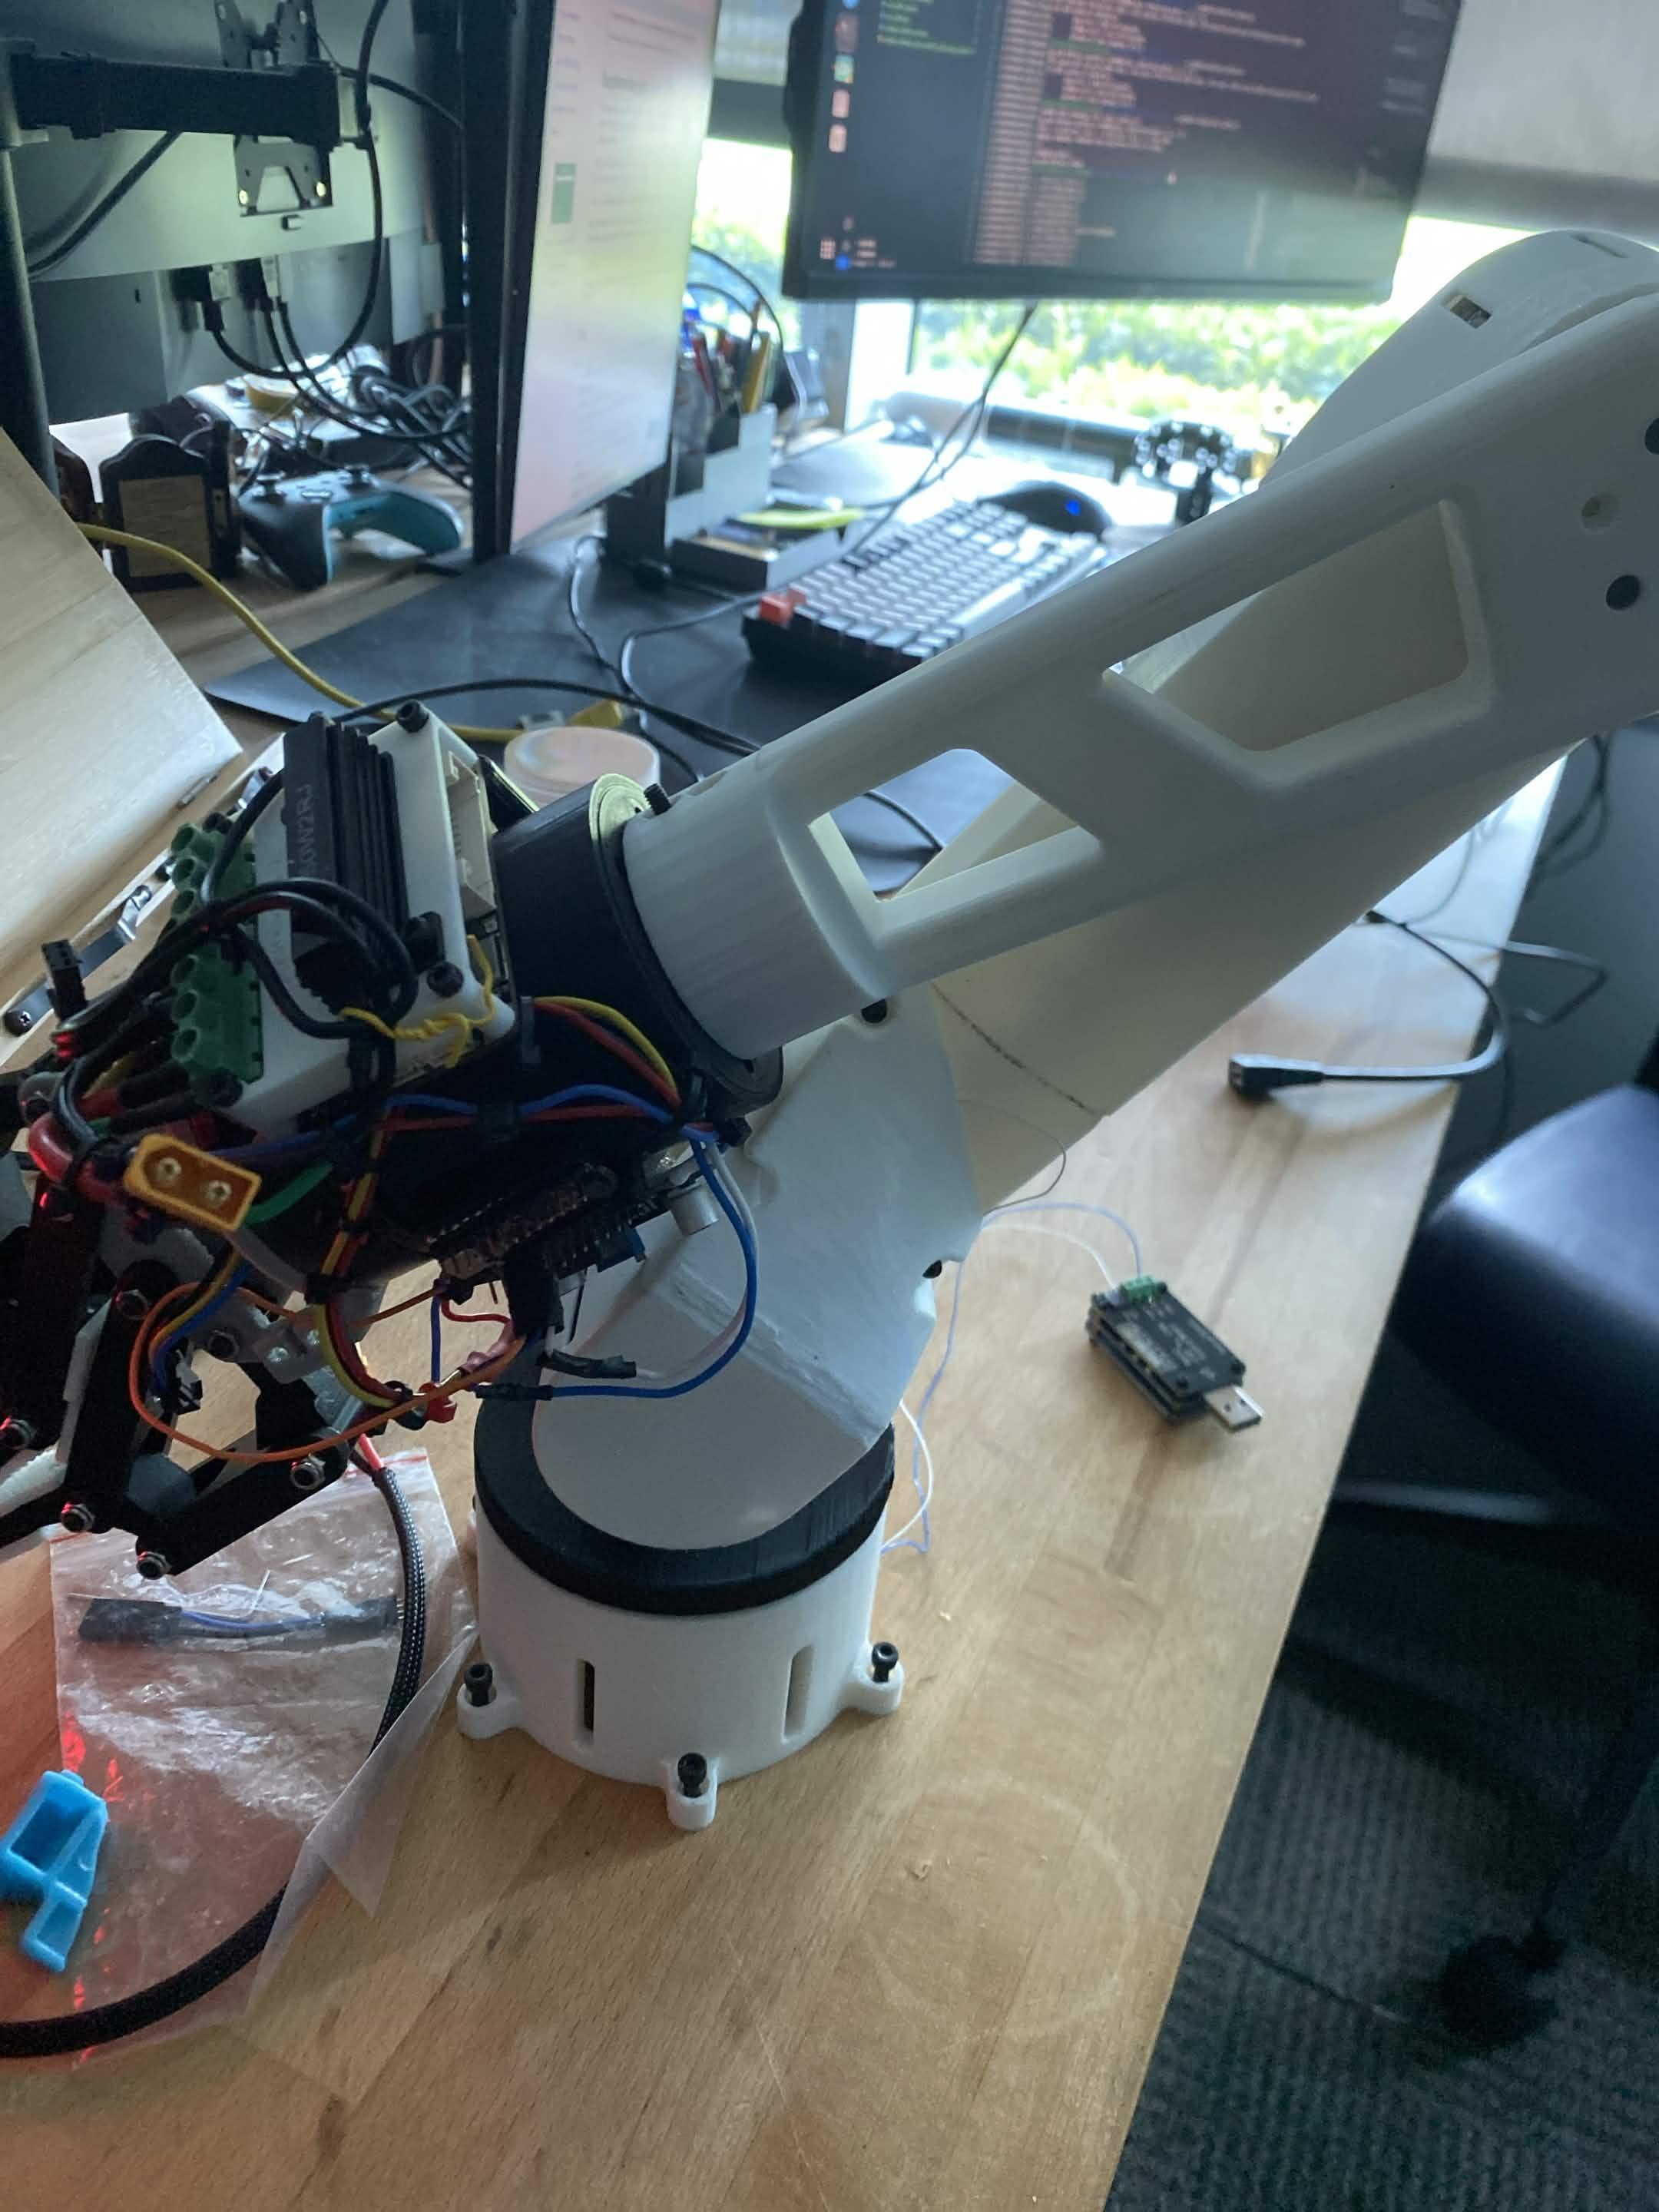
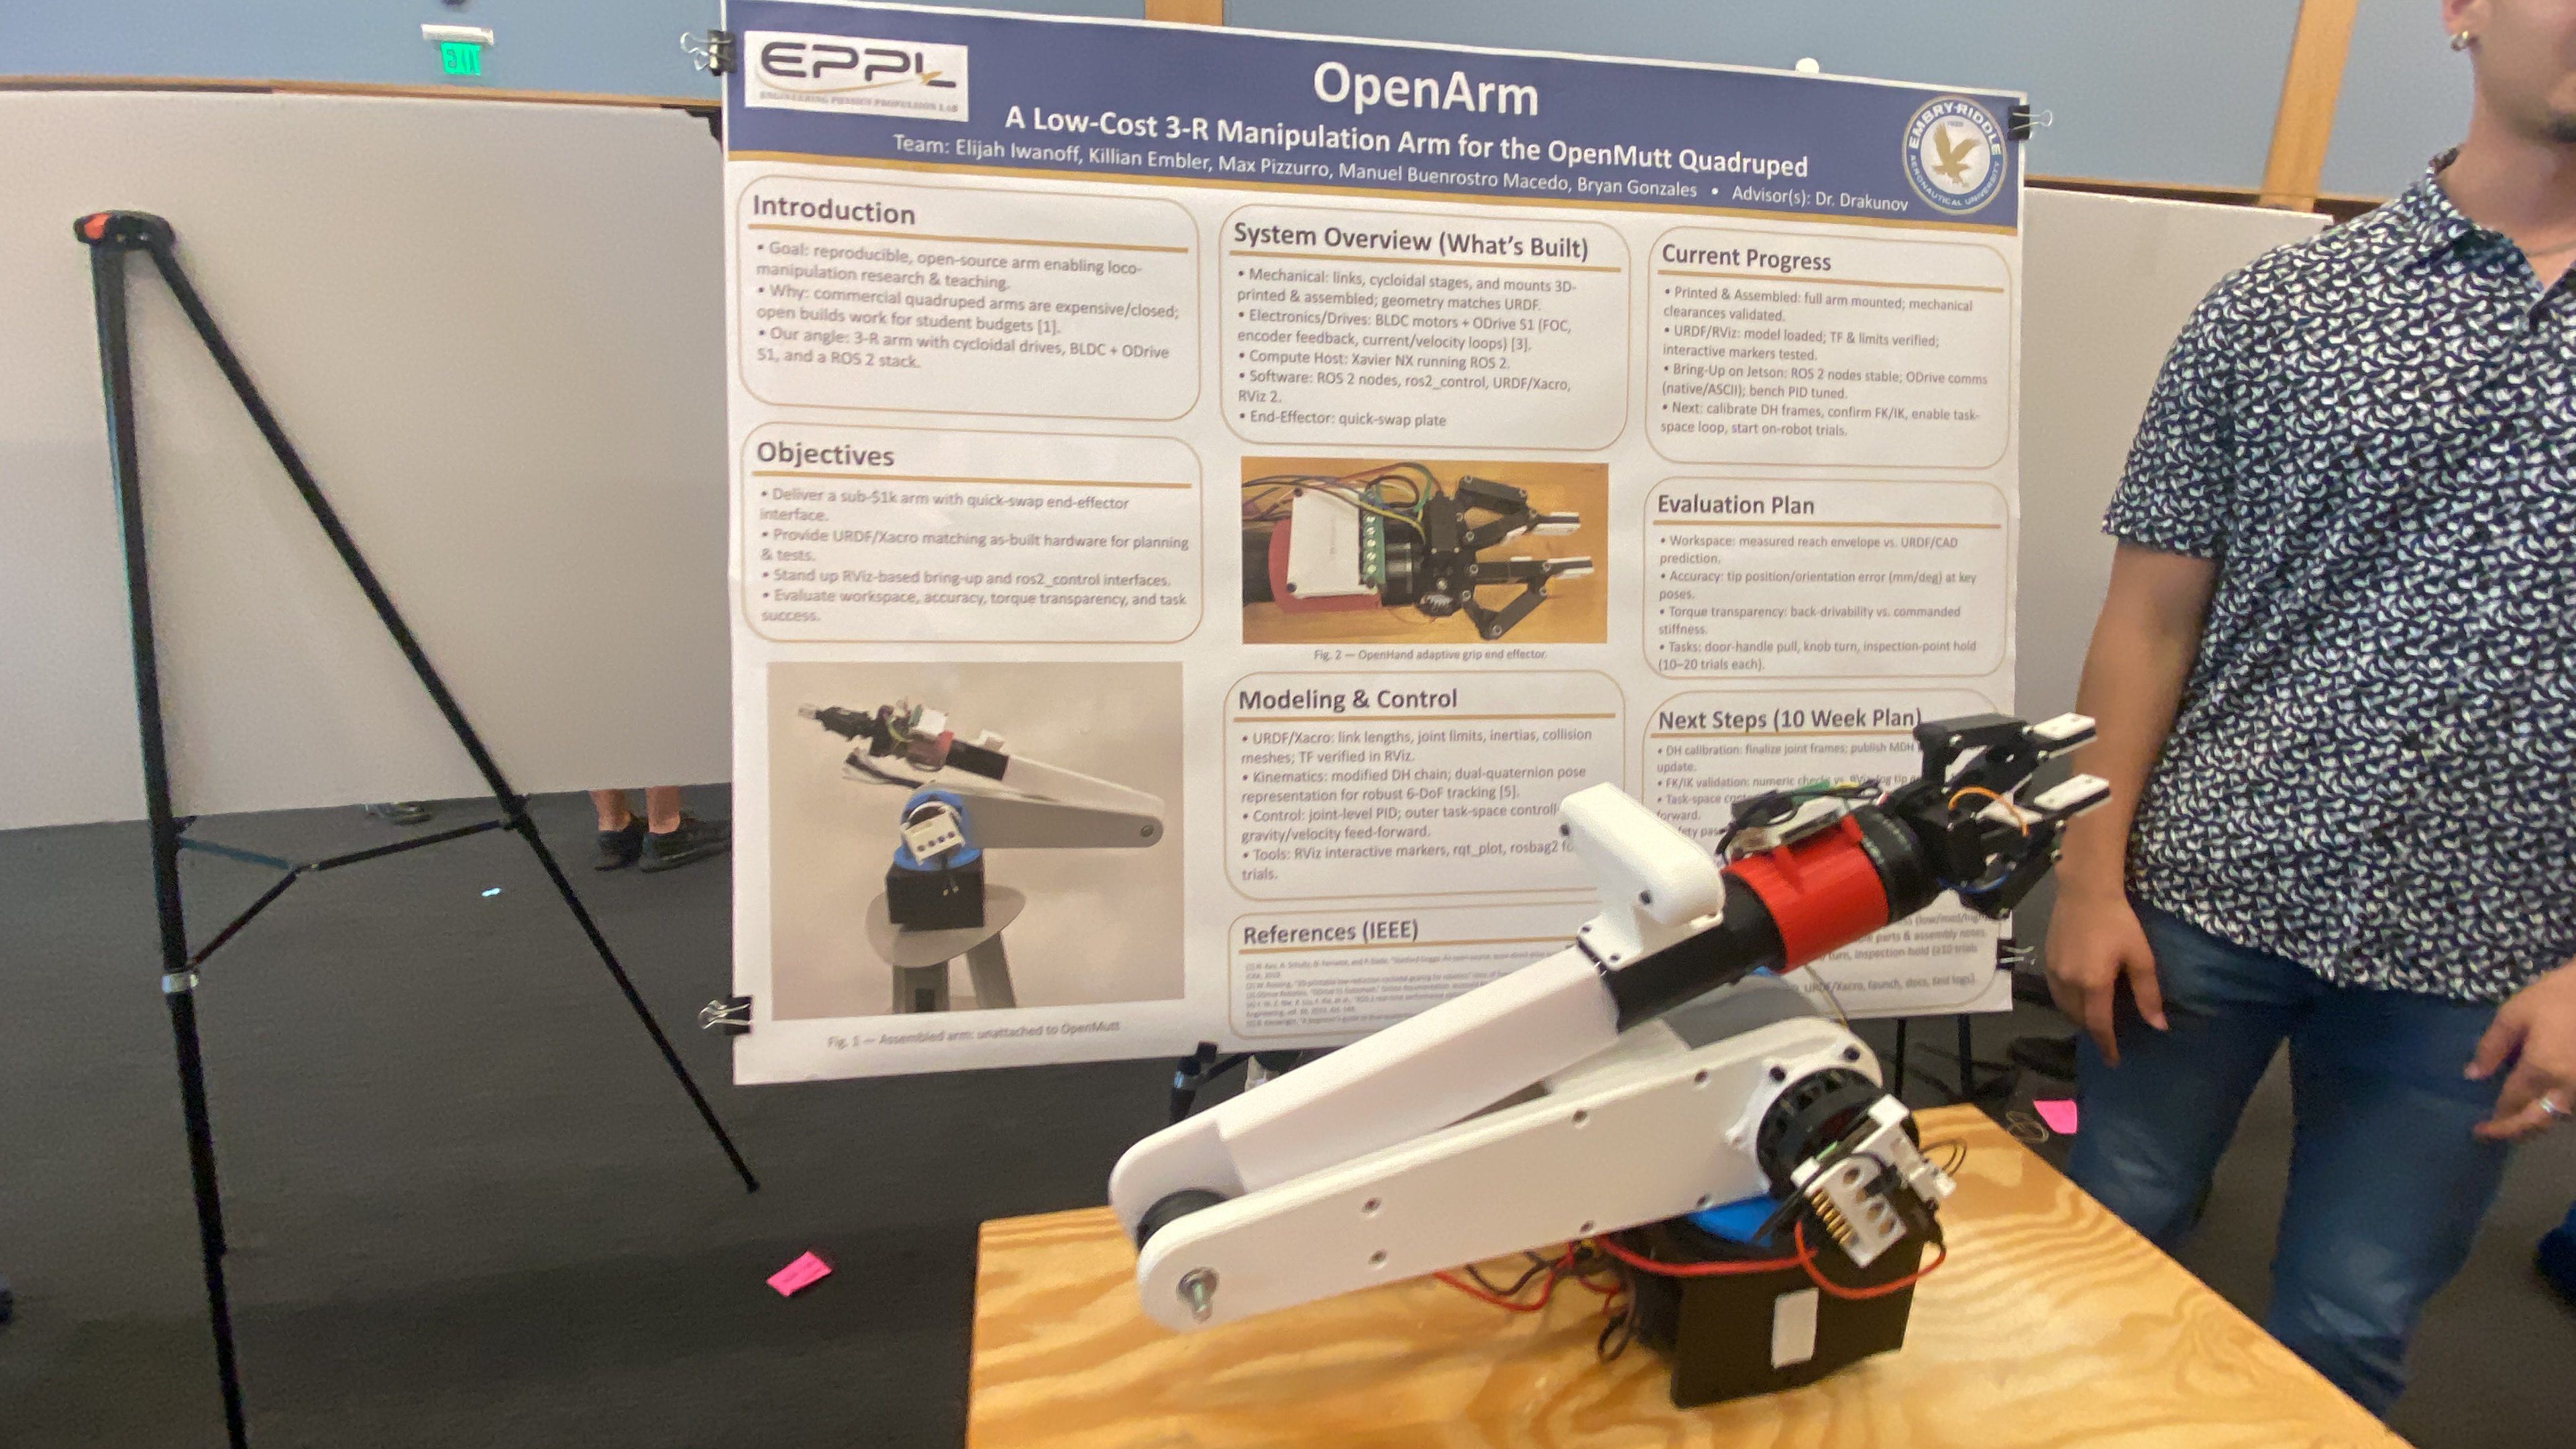
OpenArm is a 5-DOF 3D printed robot arm designed to complement OpenMutt. It mounts on the quadruped's back to increase its functionality and interaction with its environment. I was one of the founding members of the project in Spring 2025, and I contributed a significant part of the mechanical design, the URDF modeling, and the manufacturing and assembly of a physical prototype.

The arm is cable driven, with 3D printed cycloidal gearboxes at the base joints. Keeping actuators off the outer part of the arm removes weight from it, but introduced backlash problems. It took several iterations to get the right tension in the system and reliable operation for precise tasks.

Funding and presentation

The work received support from an ERAU Spark Grant and was presented at the 2025 Student Research Symposium, with both demos and a poster.

The redesign

In spring 2026, another EPPL project, Amigo, which designs payloads for the Unitree Go2 quadruped, asked us to adapt the arm into a more refined and compact version. The new design drops cable-driven actuation in favor of high torque density CubeMars actuators, and gives up one degree of freedom (wrist rotation), so the mini arm is 4 DOF. The new arm and dog combination was to be presented to ERAU executives and the project's industry supporter.

Hardest problem

The hardest part by far was the timeline. Significant redesigns had to be made, implemented, evaluated, and revised in time to prepare for the demonstration.

Results

The mini arm works effectively with high torque capacity and little backlash, and it is within the constraints to mount on the Go2 payload. The demonstration was successful.

My role and team

I was part of the EPPL team and contributed significantly to the initial design and testing of the base arm, and Manuel Buenrostro developed the end effector.

Status

Work is in progress to further reduce backlash on the large version, reduce overall weight, and fully integrate its controls and electronics with those of the OpenMutt quadruped.

Software · Object-Oriented Programming Coursework

Marine Ecosystem Simulation

Individual software development project completed as part of object-oriented programming coursework (CS 225, Spring 2026), written in Java.

  • Implemented a genetic algorithm modeling up to 100,000 unique organisms from 49 base species (with more added in-program) and their interactions across 3 simulated ecosystems.
  • Tracked predation, reproduction, and genetic drift over monthly turns to study how primary producer health, invasive species, and the removal of key species affect the long-term stability of marine ecosystems.
  • Java
  • Genetic Algorithm
  • Object-Oriented Design
  • Simulation
  • Data Tracking
More detailHide detail

Overview

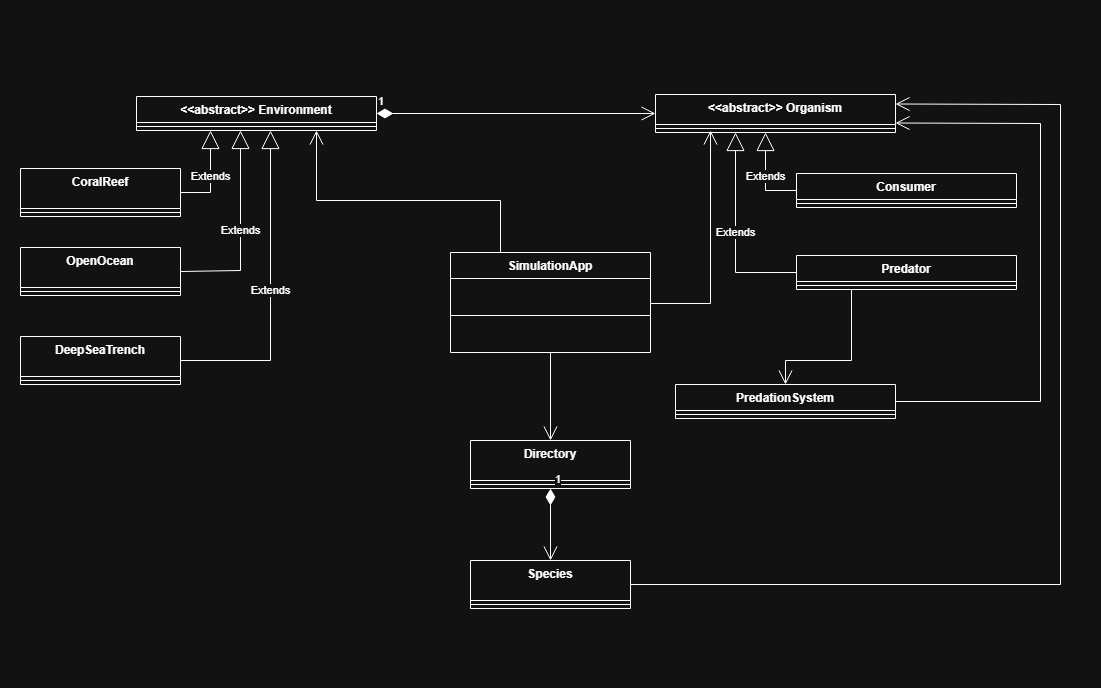
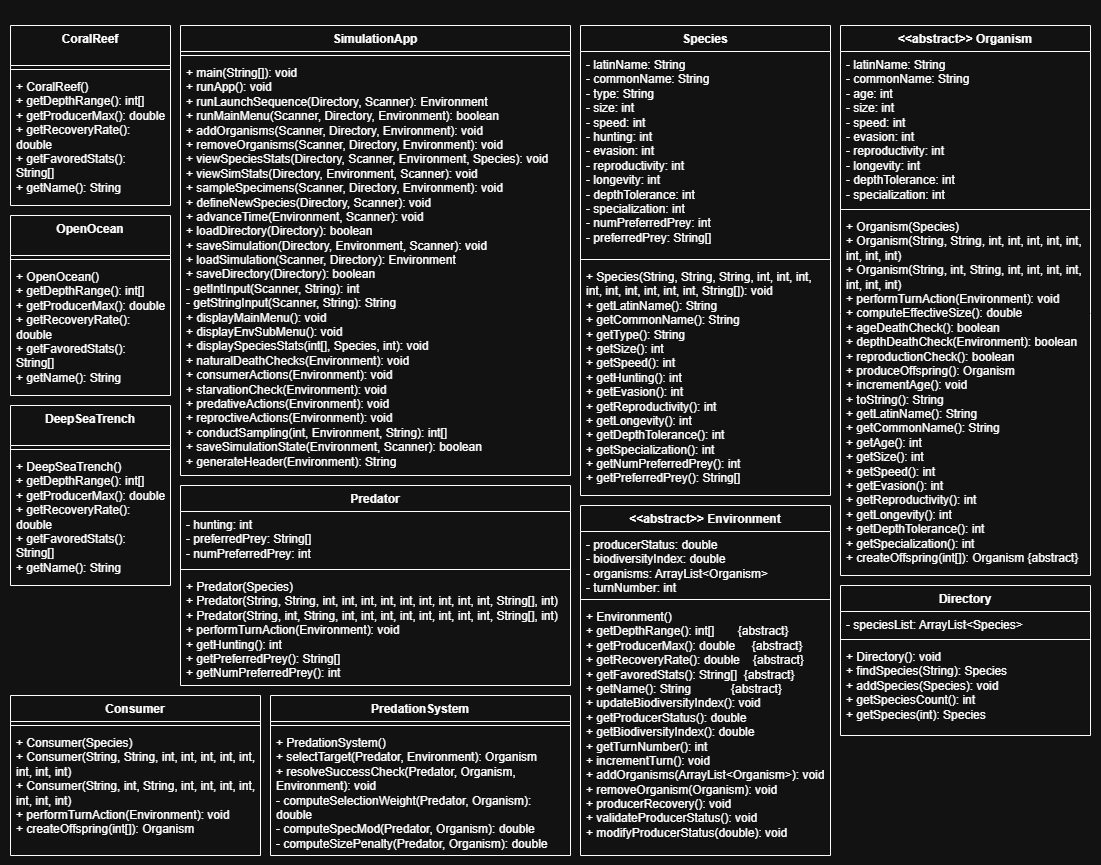
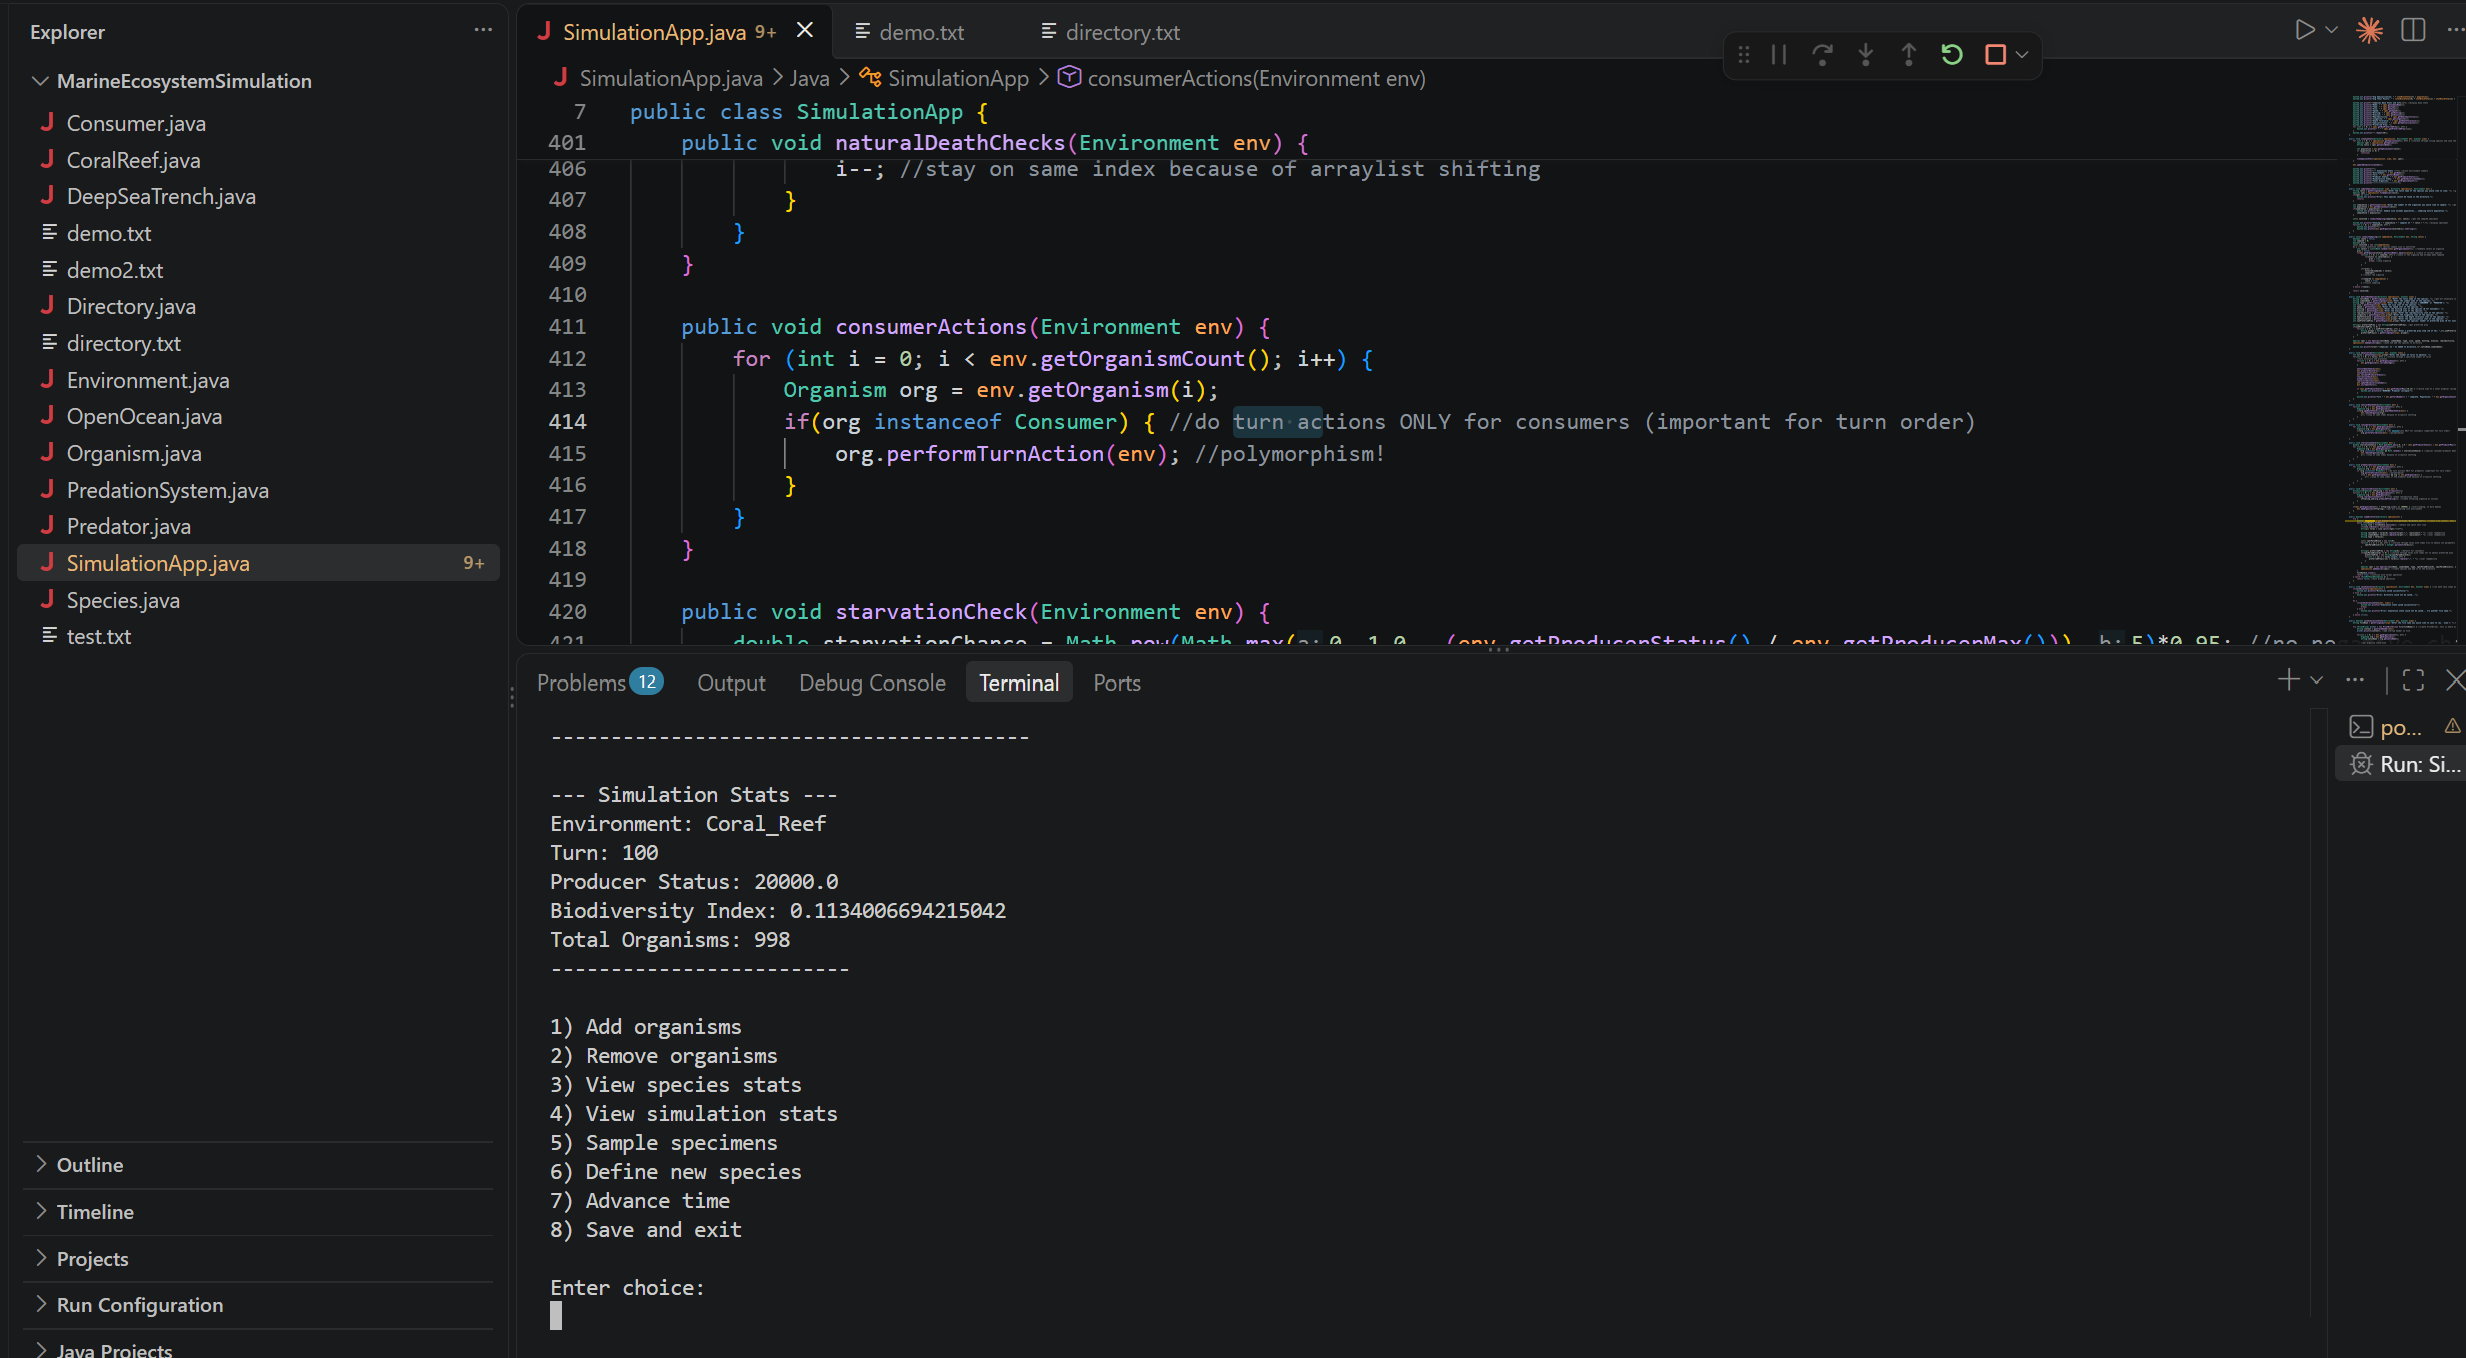
A marine ecosystem simulator built around a genetic algorithm. The user picks a coral reef, open ocean, or deep sea trench, then adds or removes species from a directory of 49 base species (and can define new ones in the program). Time advances in monthly turns, and the user watches whether the ecosystem holds its balance or collapses. Each organism carries eight genetic stats that drift over generations through reproduction. Every turn includes aging and death checks, grazing on producers, predation, reproduction, and an update of a Shannon biodiversity index.

The full design, including the equations behind each mechanic, is in the Software Design Document linked below.

Design

The program is built from eleven classes in two inheritance hierarchies (environments and organisms), plus supporting classes for species data, the species directory, and predation. A single driver class runs a text menu and handles all file input and output, so save files and the species directory are never edited by hand.

Hardest problem

In terms of actual development, the hardest problem was approaching the complexity of a real ecosystem in software and deciding what to simplify and what to keep high fidelity, so the model would give meaningful results. I handled that in a few ways, such as simplifying the predation system and using asexual reproduction while keeping the processes behind them. Tuning the system for greater fidelity and long-term stability would take more time and biological background than I had at the time, so getting even partial success through experimentation was very satisfying.

Results

Full environmental studies were not performed, but testing showed that introducing an invasive predator species to a coral reef often more than halved the time before the ecosystem collapsed. Removing important species had a similar effect.

What's next

The next major steps are increasing the accuracy of the simulation and getting more ecological backing for its parameters.

05

Leadership

Chief Technical Officer & Technical Co-Founder

Aerospace startup · Daytona Beach, FL

  • Co-founded a 12-person aerospace startup developing advanced flight computers for small to medium scale rocketry.
  • Coordinated daily with the PCB design, software, and implementation teams, advised on design decisions, and provided specialized training to build members' confidence and effectiveness.
  • Spearheaded research and development of the flight computer PCB, hardware implementation of testbeds, organization of launches for experimental validation and product iteration, and firmware for field operation (see Projects).
  • Represented the company in meetings with elected local officials and potential business partners, and presented at the Volusia County Pitch Competition, where Embler Control Systems won Best Technical Startup.
  • Navigated product development under FCC unintentional radiator constraints, ITAR standards for controlled model rocketry, and FAA safety regulations for test flights.
  • Worked around severe global supply shortages in components such as flash memory by consigning critical parts from multiple suppliers to a single point of assembly, and minimized production cost through advance component selection against budget and performance requirements.
06

Skills

Computer Aided Design

  • Inventor
  • Fusion
  • CATIA
  • Siemens NX
  • FEA
  • EasyEDA
  • KiCad
  • URDF Modeling

Manufacturing

  • Drafting
  • Tolerances
  • CNC Lathes
  • Mills
  • Welding
  • 3D Printing (FDM)
  • Laser Cutting
  • Hand and Power Tools

Electrical & Embedded

  • Wiring
  • Soldering
  • PCB Design
  • Arduino
  • STM32
  • Raspberry Pi
  • Teensy
  • FPGA
  • Oscilloscope

Programming

  • C/C++
  • Java
  • ROS
  • ARM Assembly
  • Python
  • MATLAB
  • Verilog

Organizational

  • Word
  • LaTeX
  • Excel
  • Agile Scrum
  • Experimental Design
  • Experimentation with Human Participants
07

Awards

Awards & Funding

  • Best Technical StartupVolusia County Pitch Competition
  • NIH Grant of $523,000Awarded to the Robotics Intelligent Learning Lab for exoskeleton research, including the LECTER project
  • NASA Florida Space GrantRecipient, for exoskeleton research under the Robotics Intelligent Learning Lab
  • Spark GrantERAU, for OpenArm robotic arm research
  • Diamond Eagle ScholarshipERAU
  • Paul B. Hunter Memorial Endowed ScholarshipERAU
  • Dean's ListERAU, Fall 2024 - Present

Involvement

  • ERAUEngineering Physics Propulsion Lab
  • ERAURobotics Intelligent Learning Lab
  • ERAUSociety of Physics Students
  • ERAUAstrophysics Research Club
  • ExternalSigma Pi Sigma, the National Honors Society for Physics and Astronomy
  • ExternalDaytona Regional Chamber of Commerce
08

Contact

I'm currently seeking internship opportunities for Summer 2027 in mechatronics, robotics, mechanical design, and spacecraft systems, along with research collaborations.

Feel free to reach out. I'm always happy to discuss projects or potential collaborations.